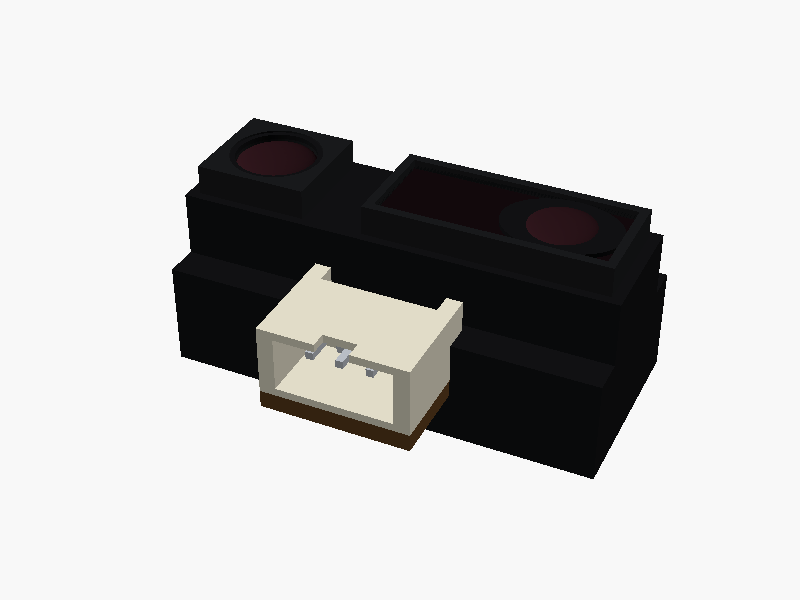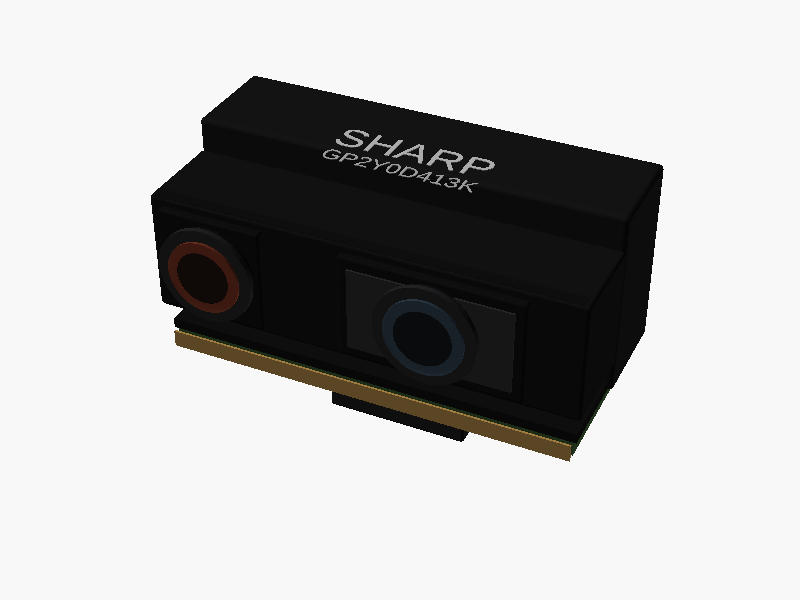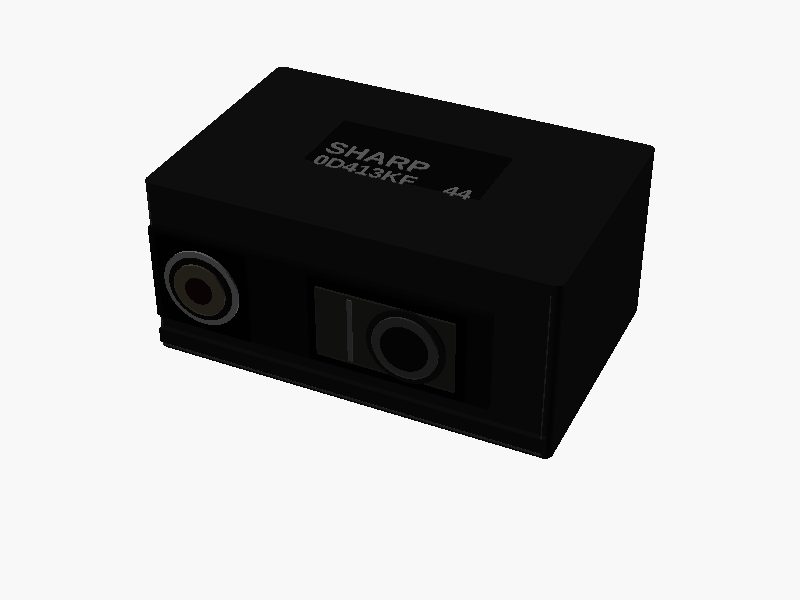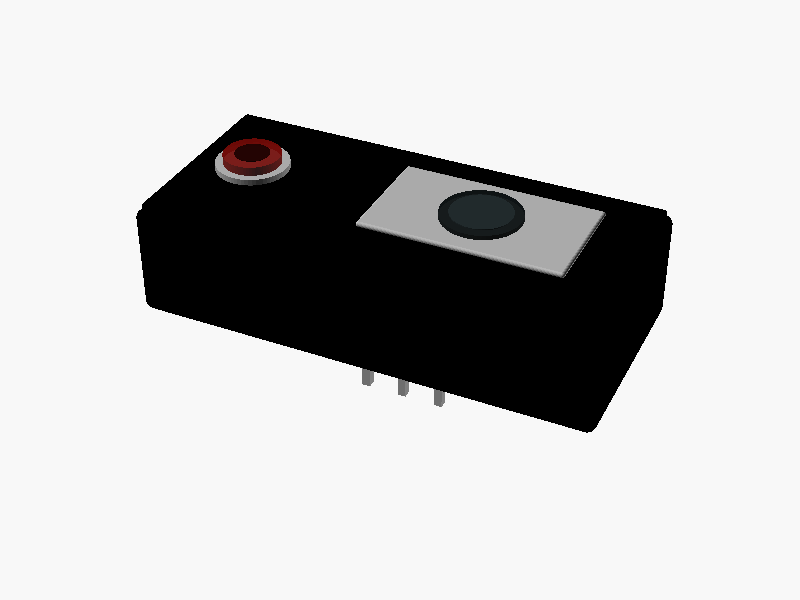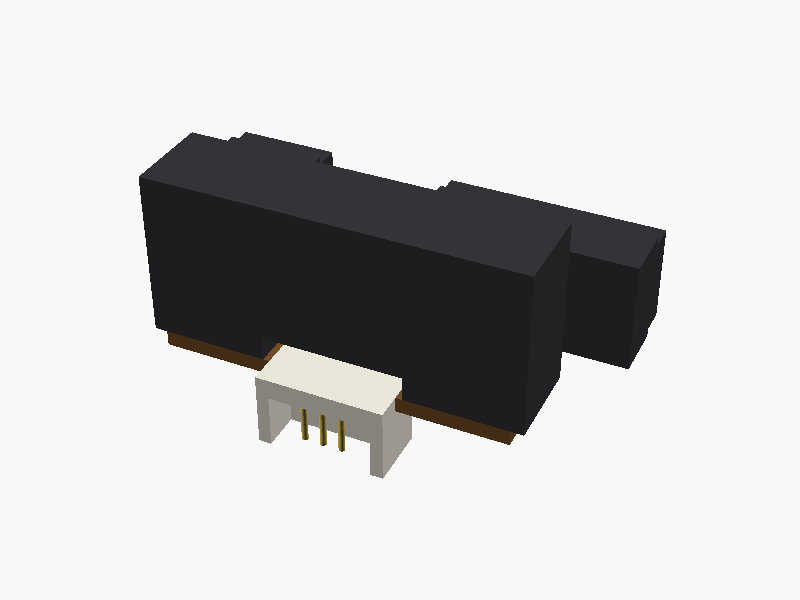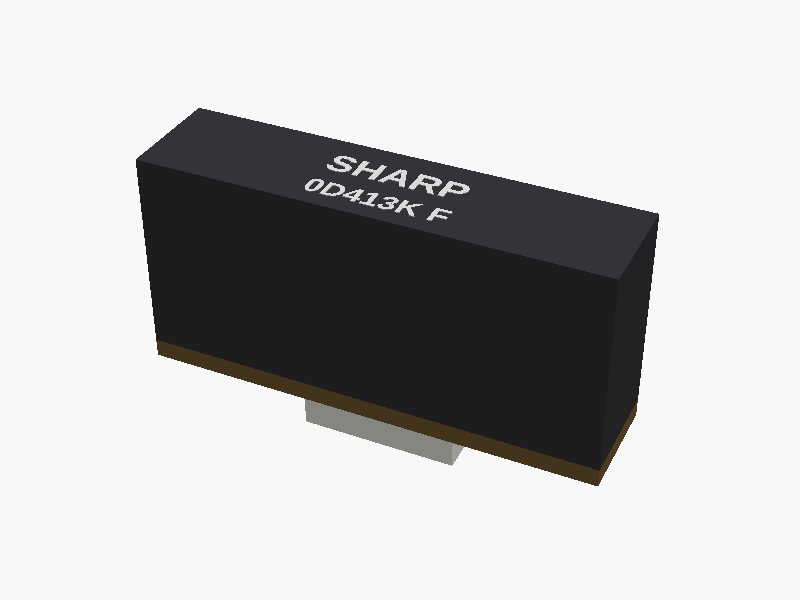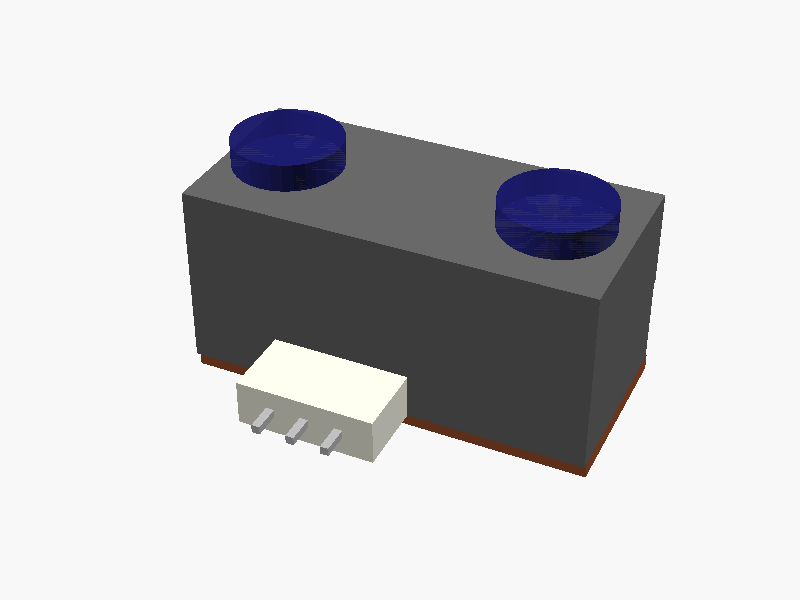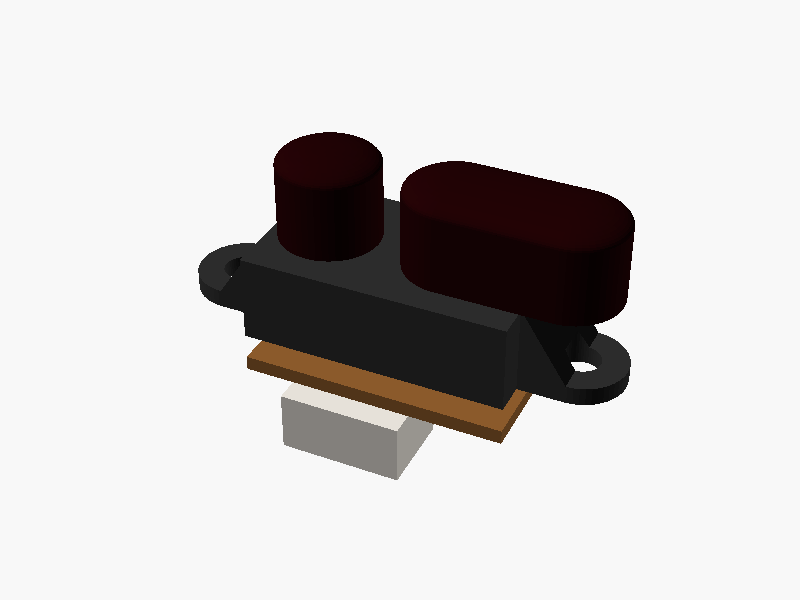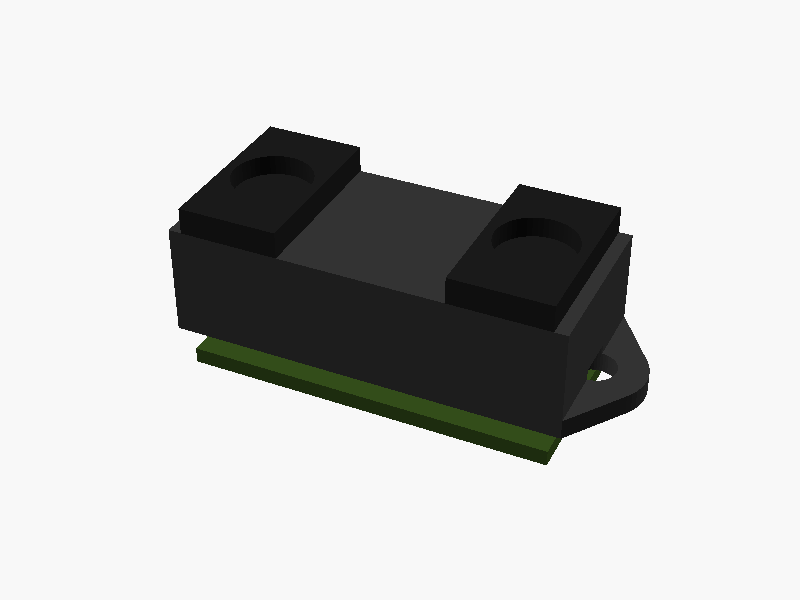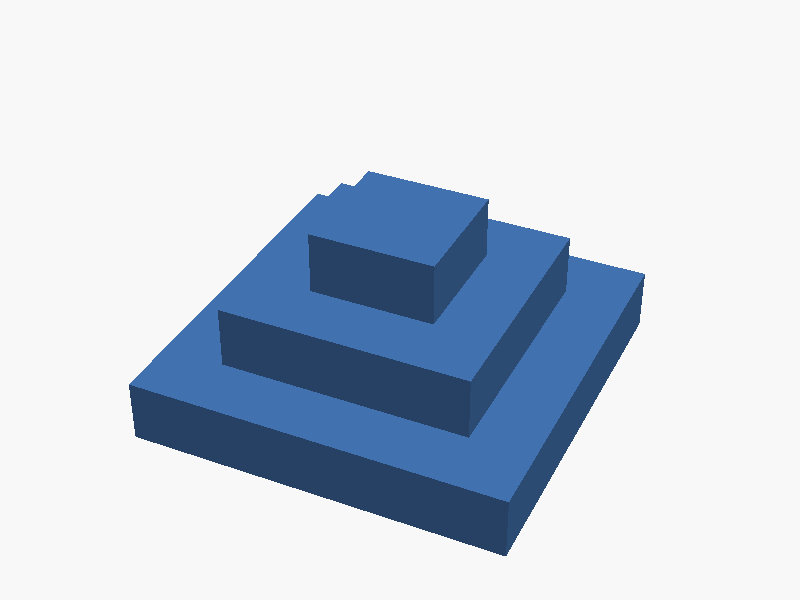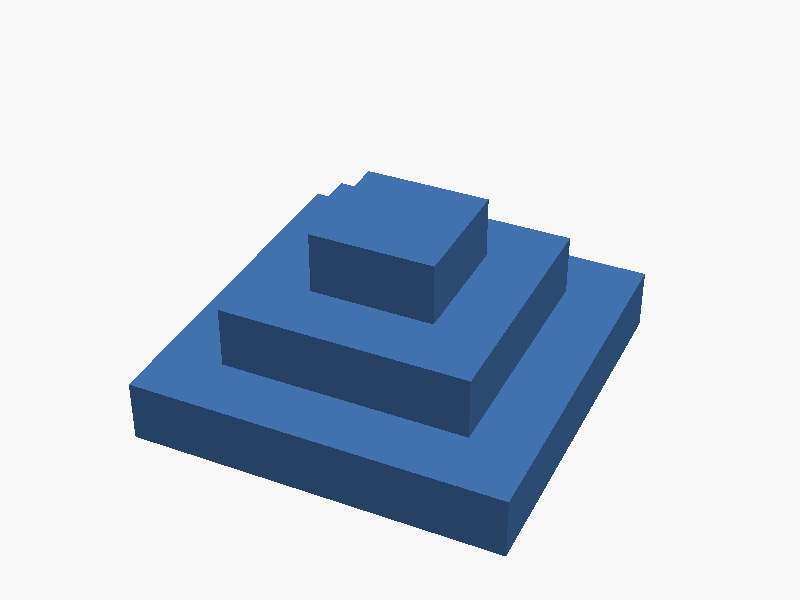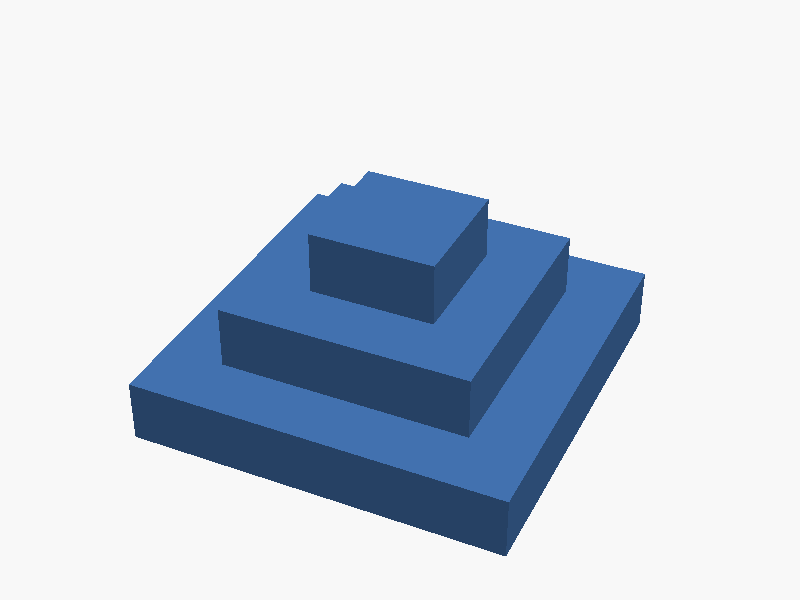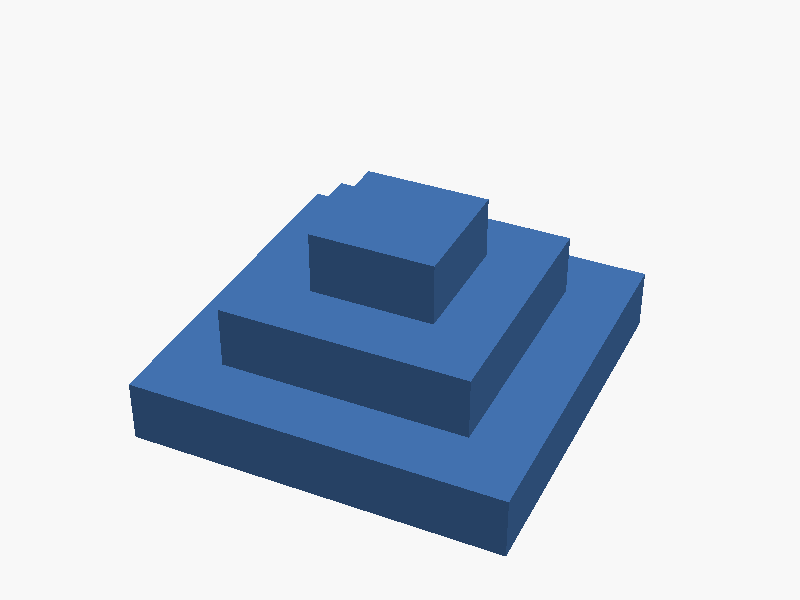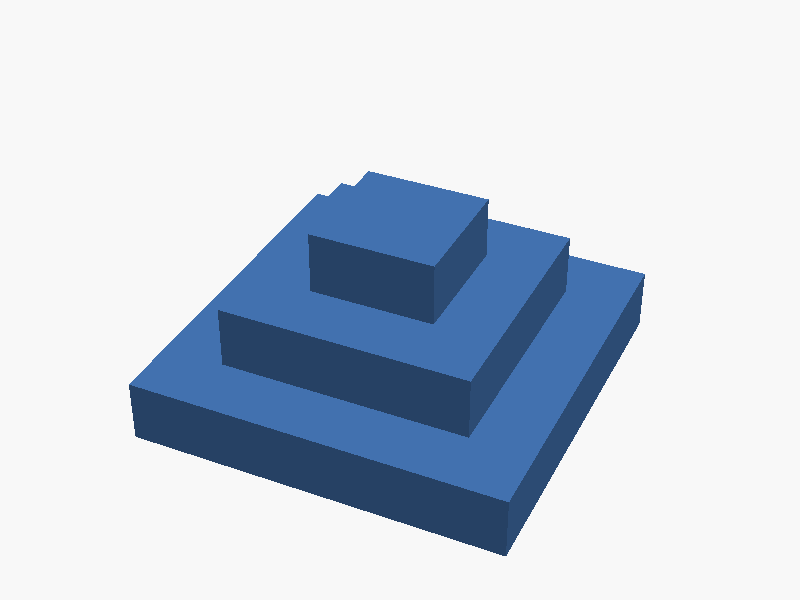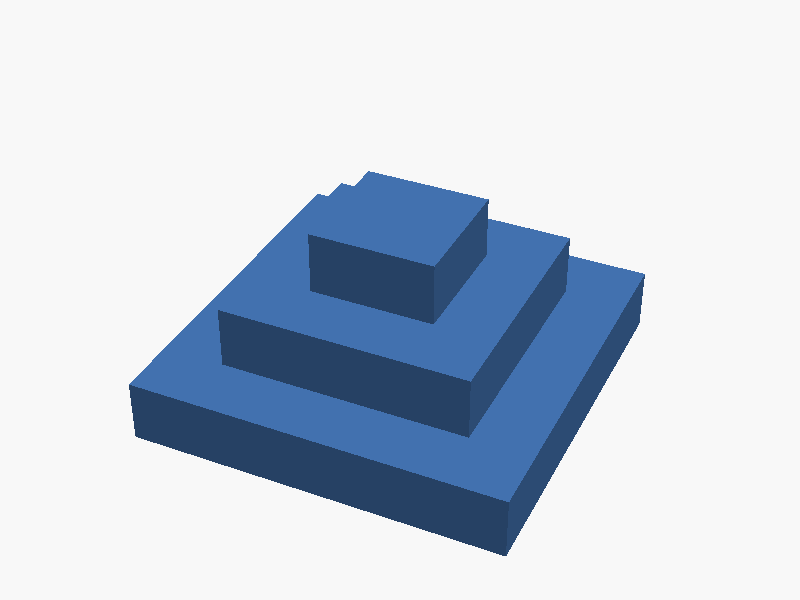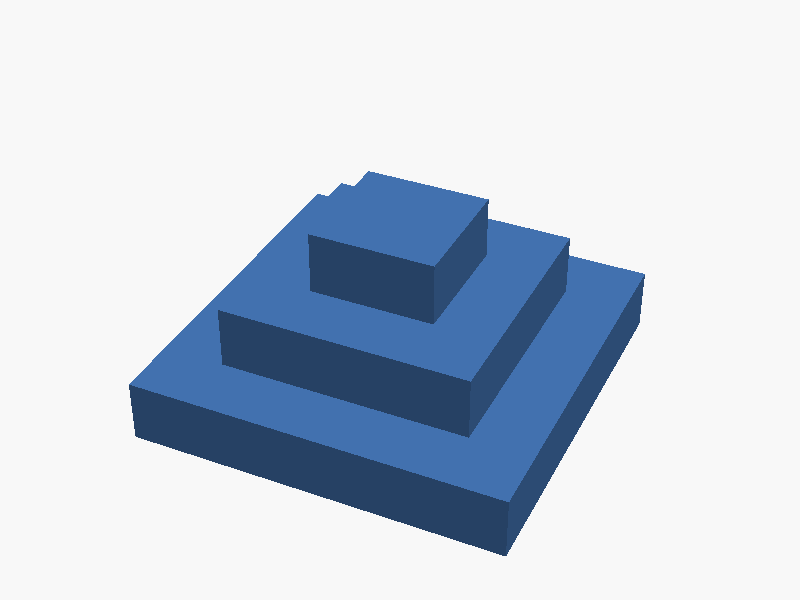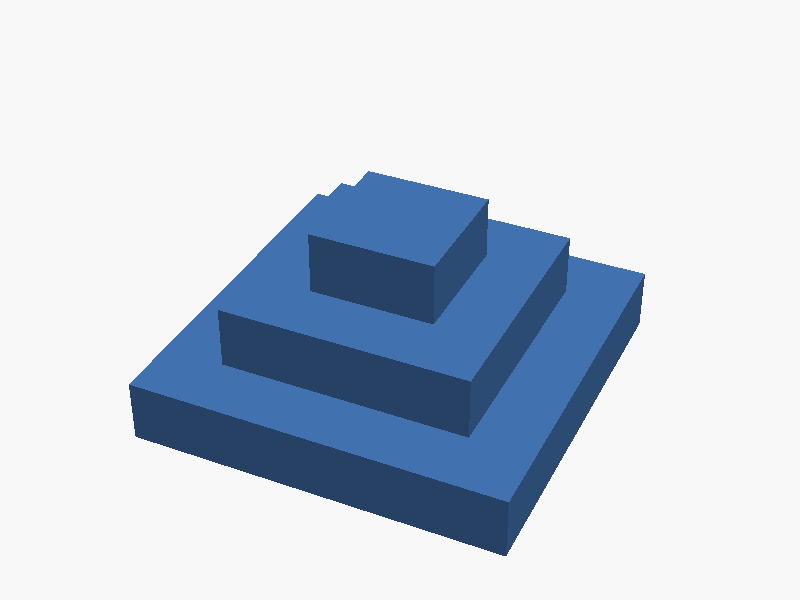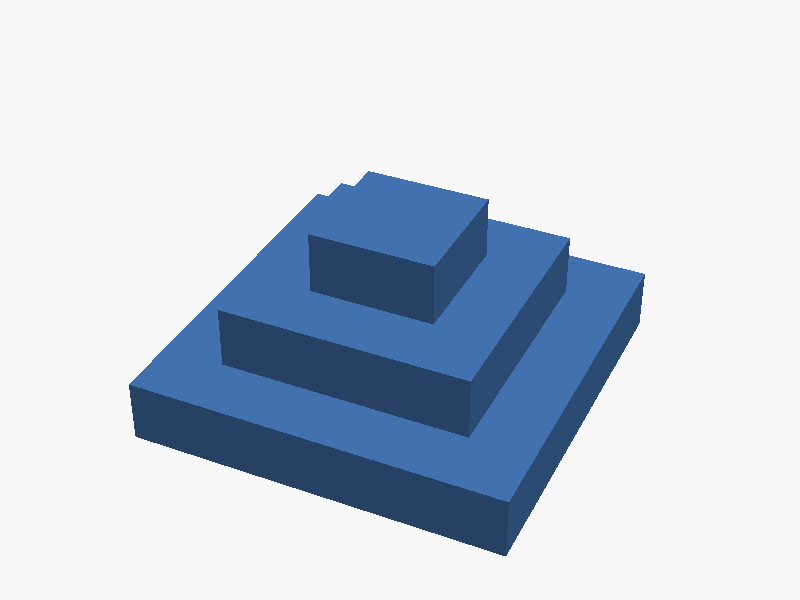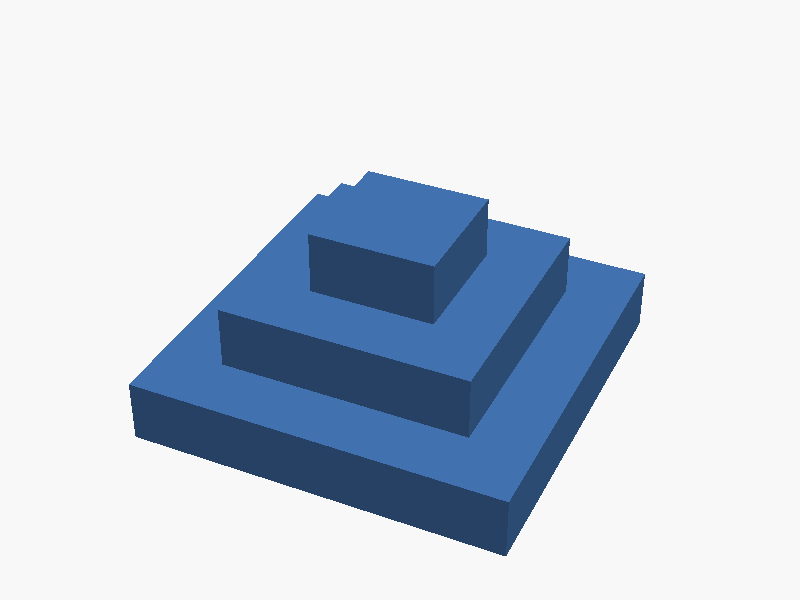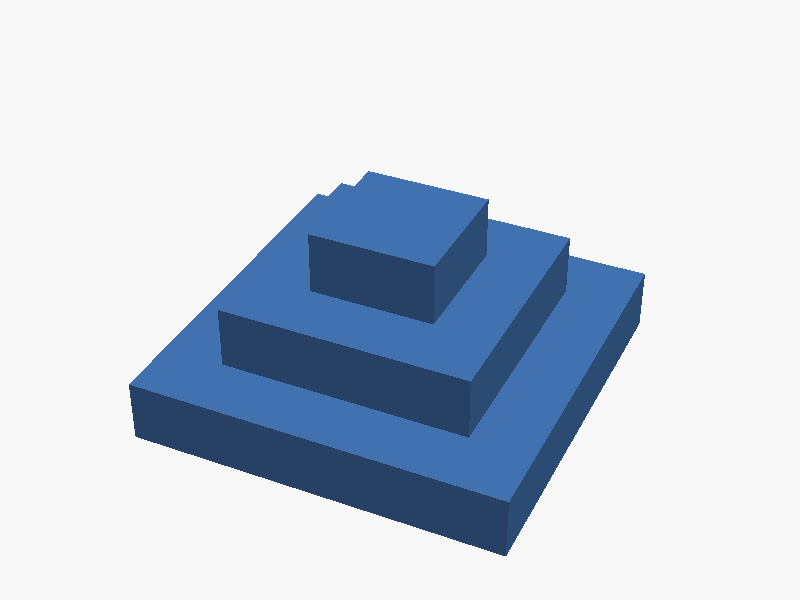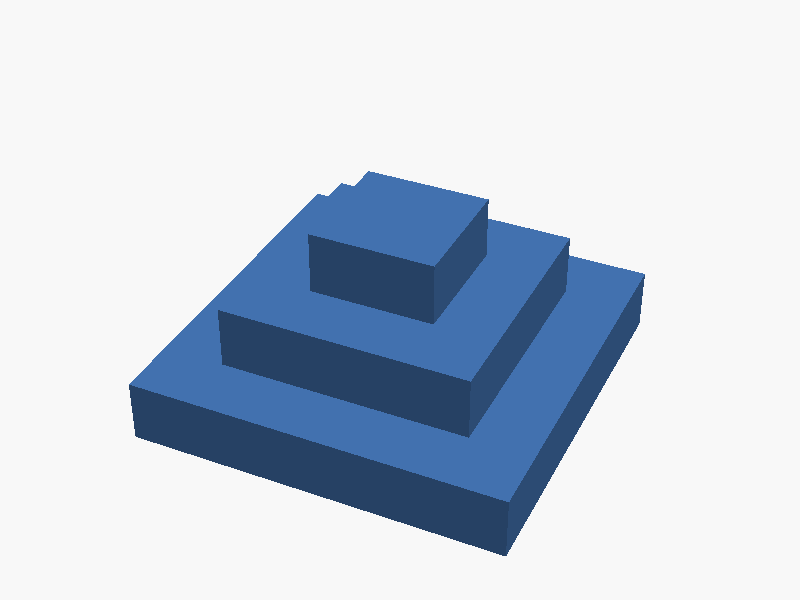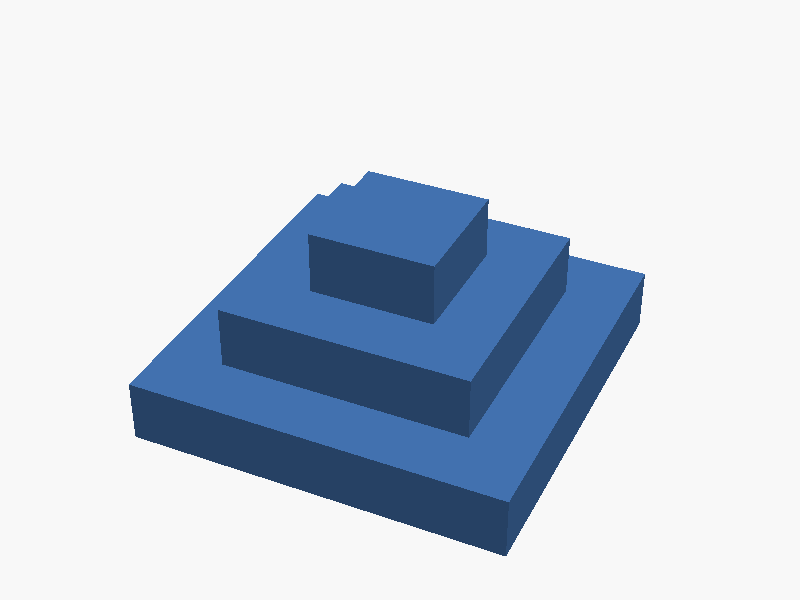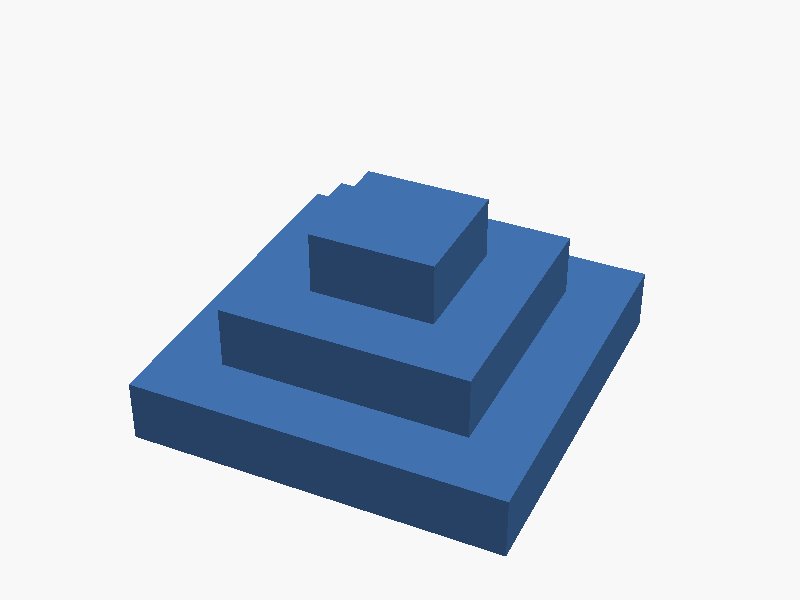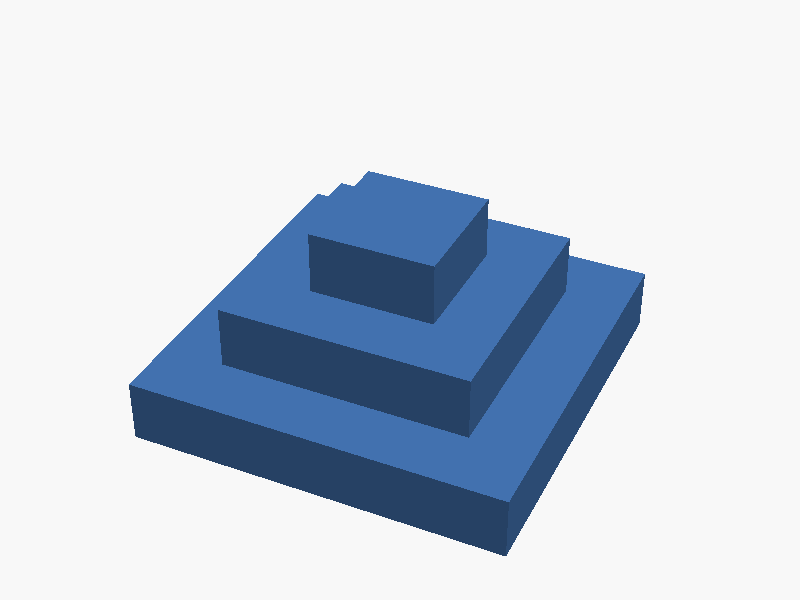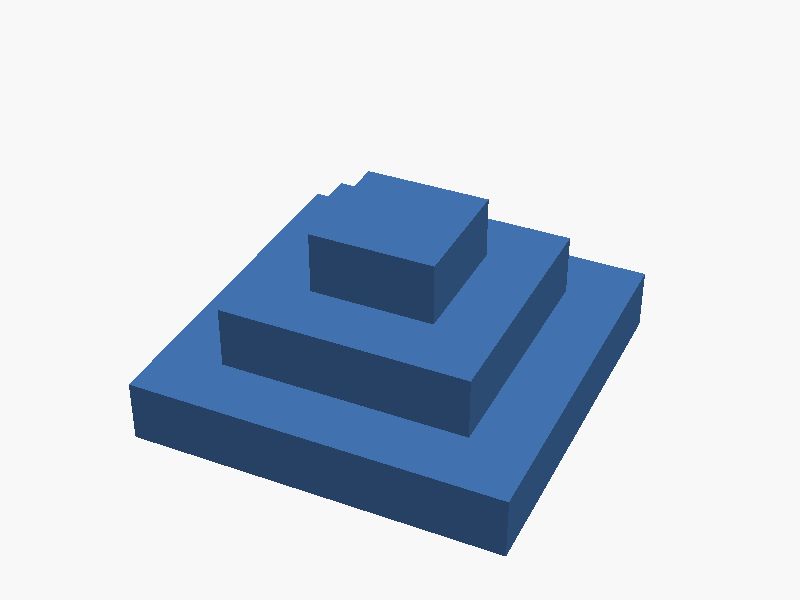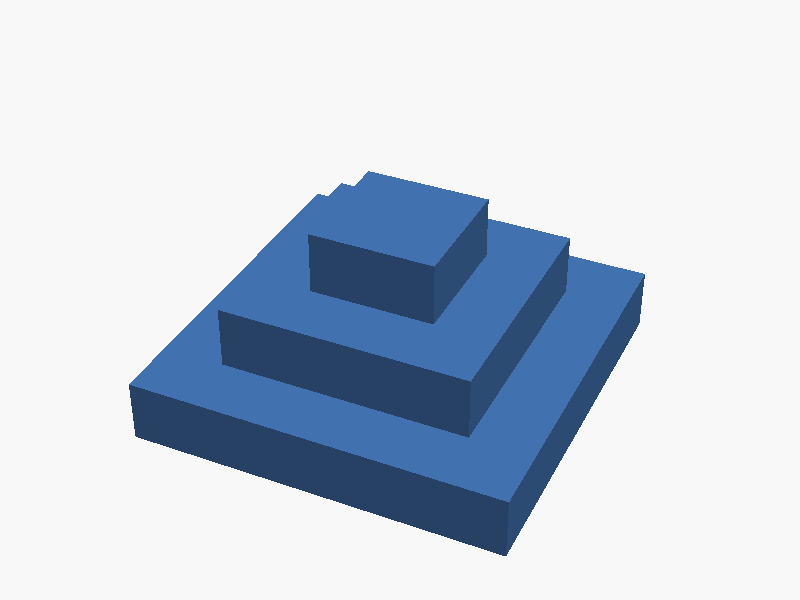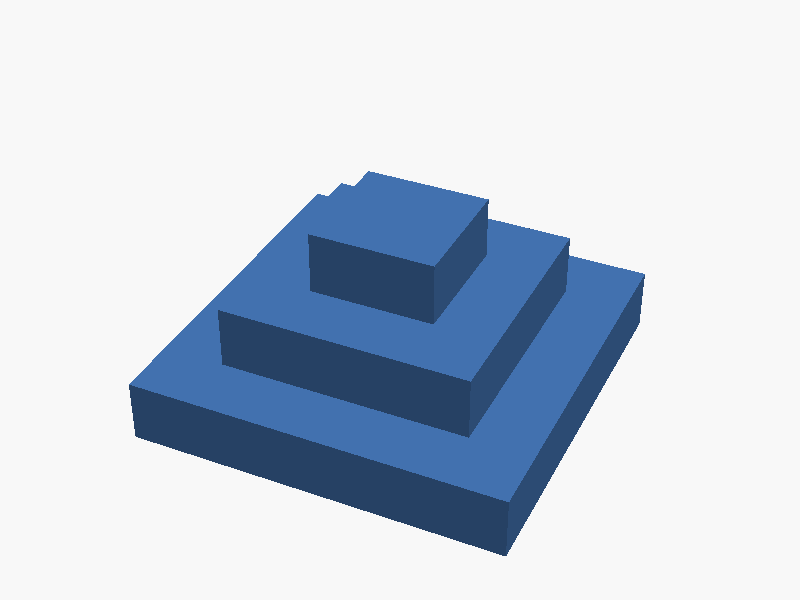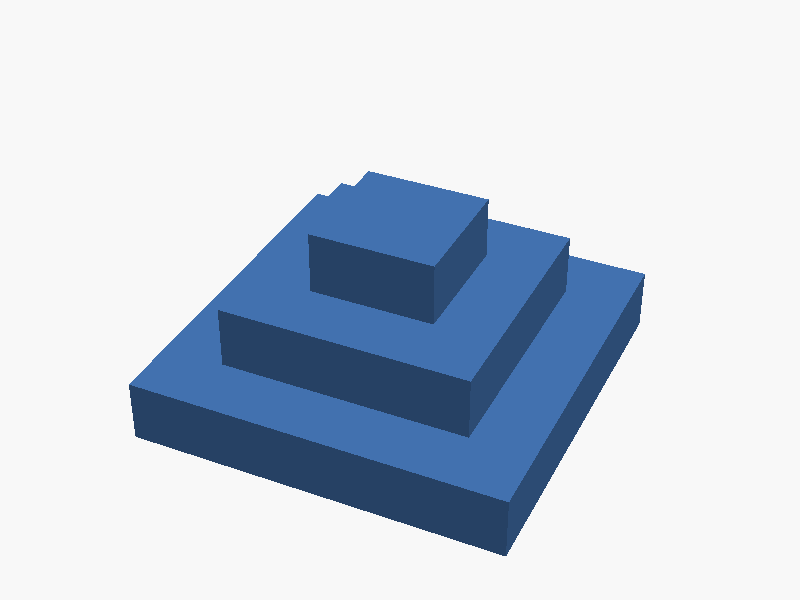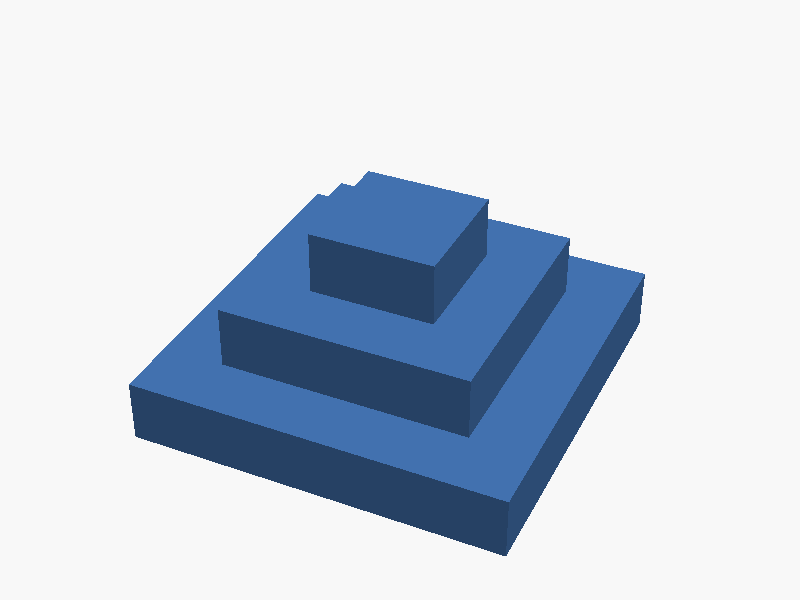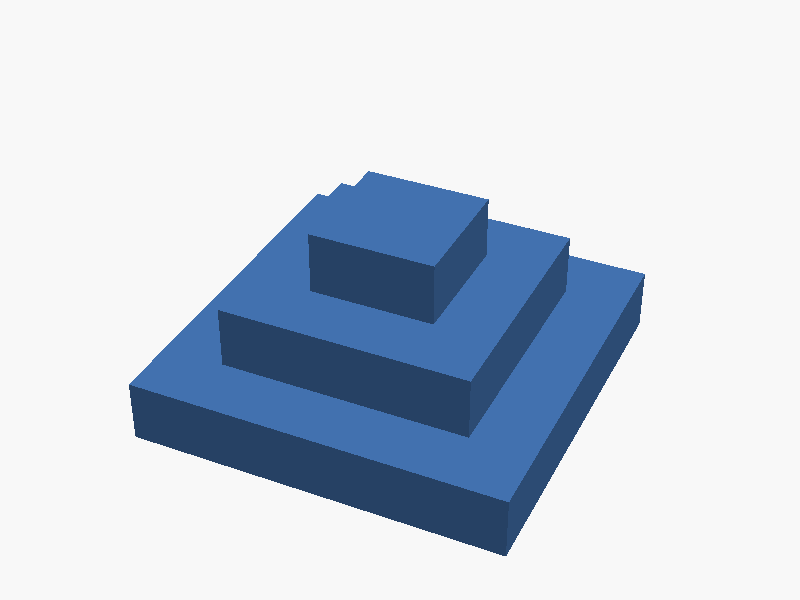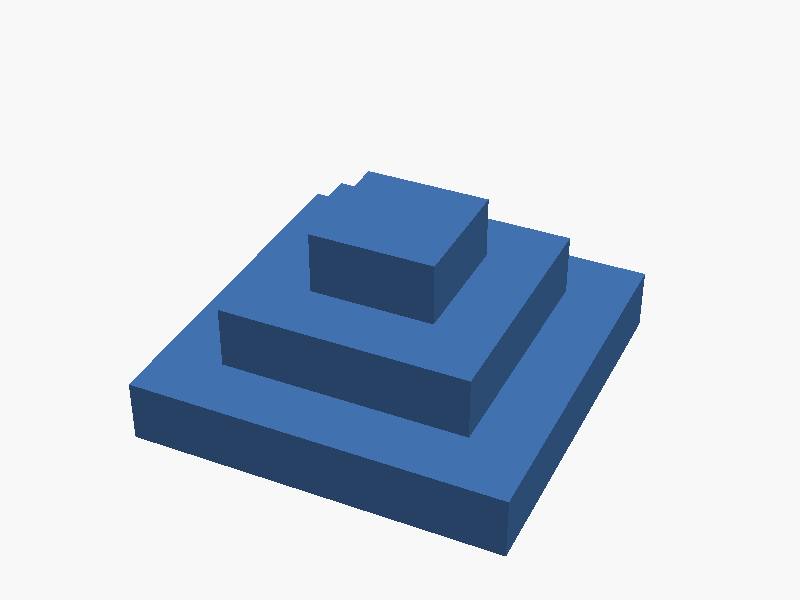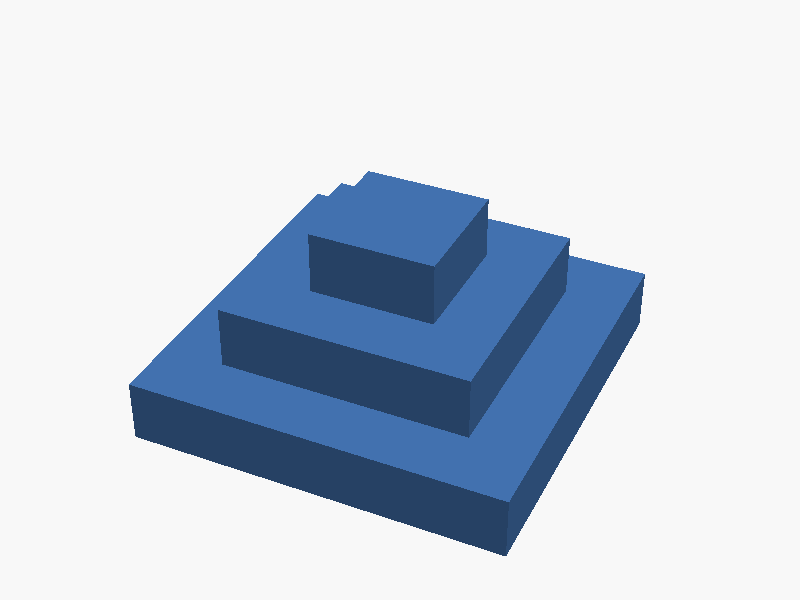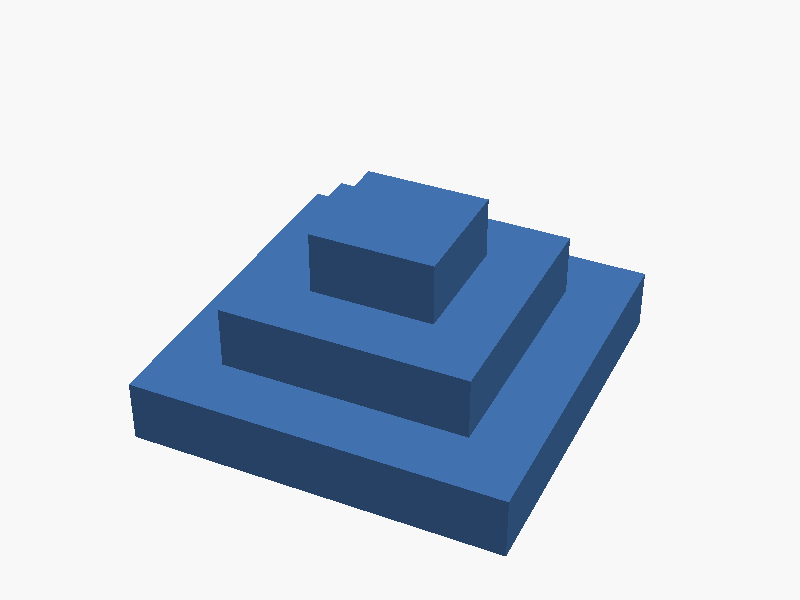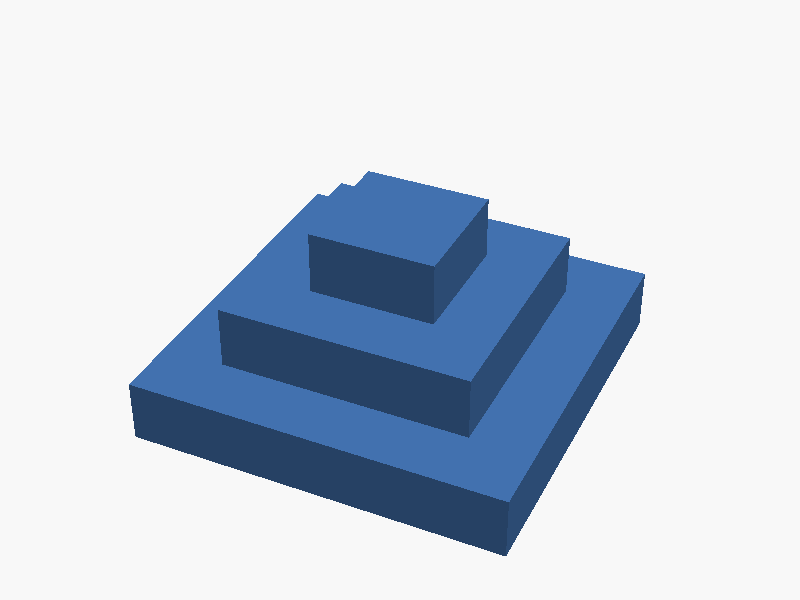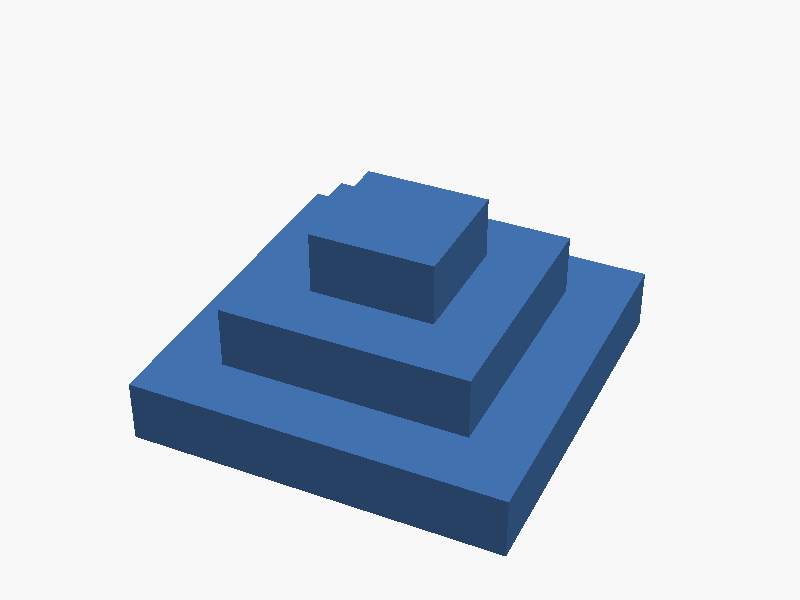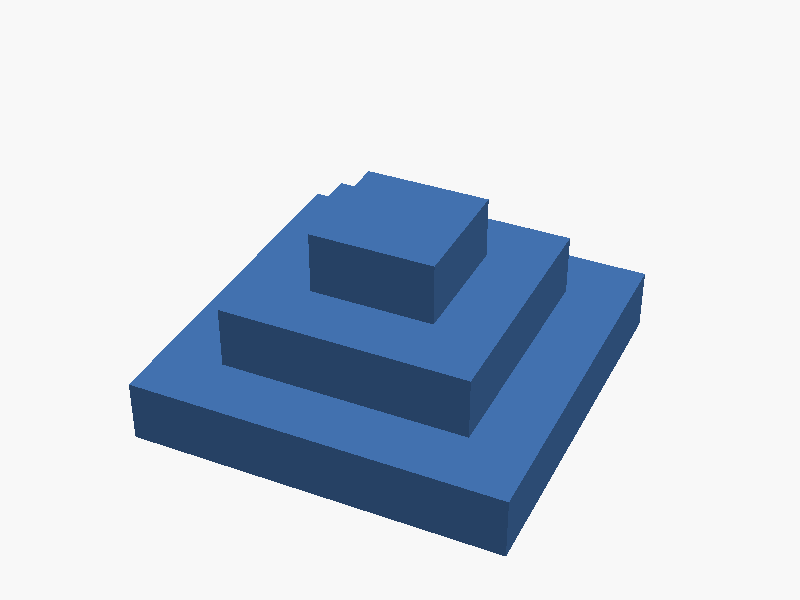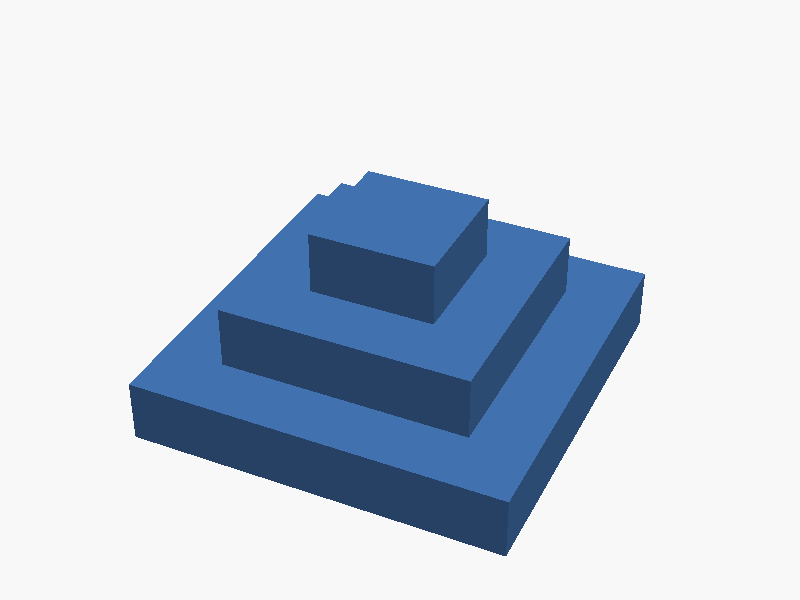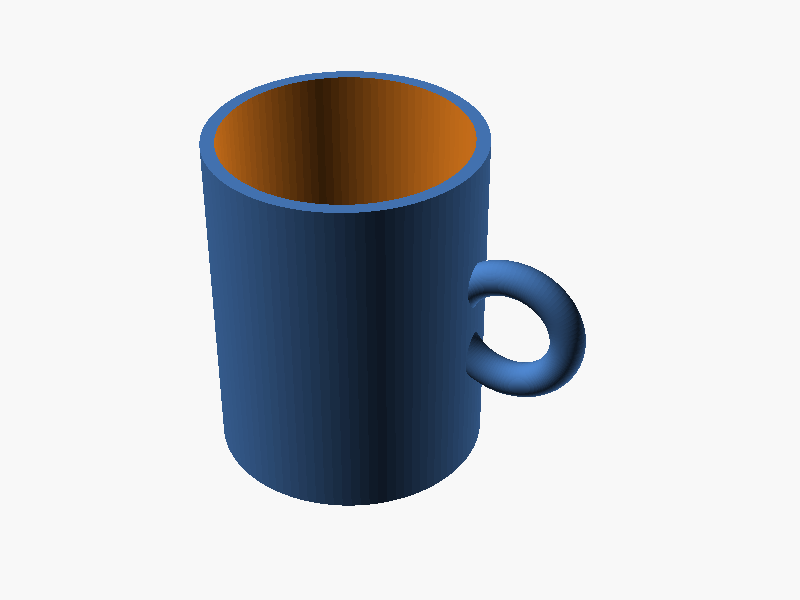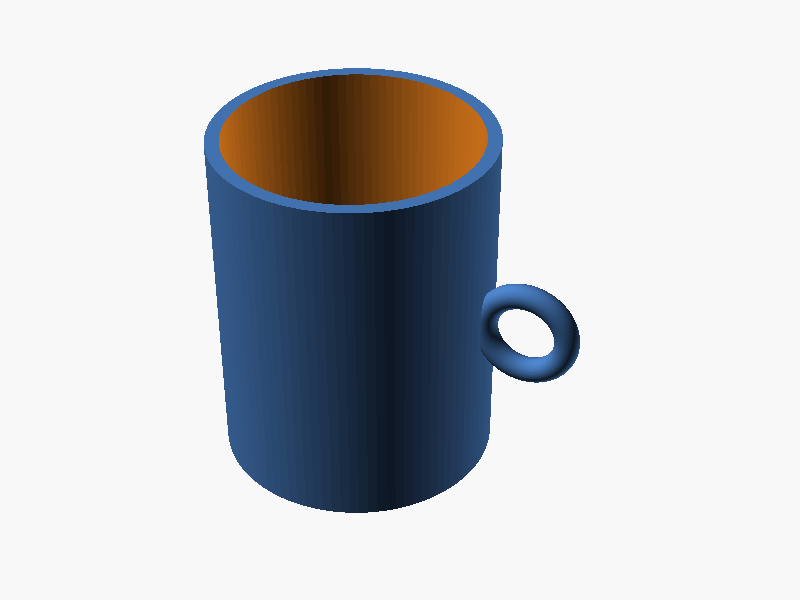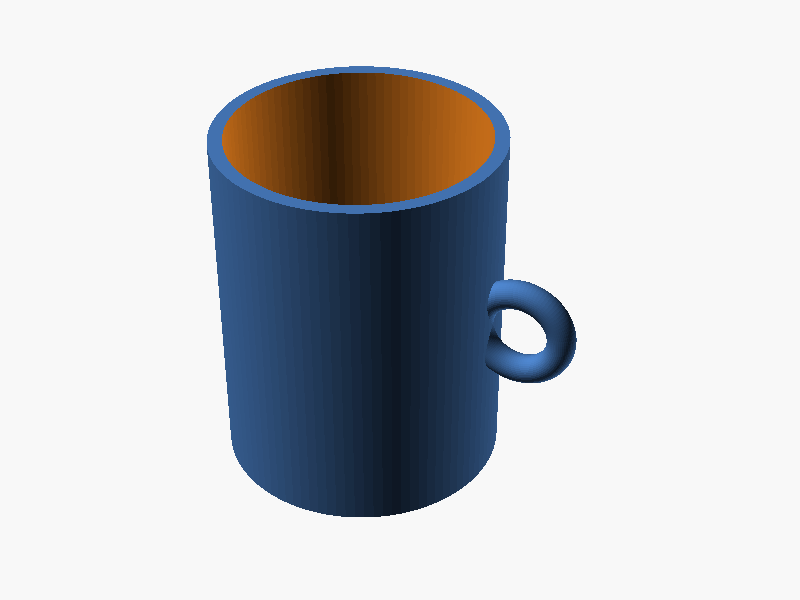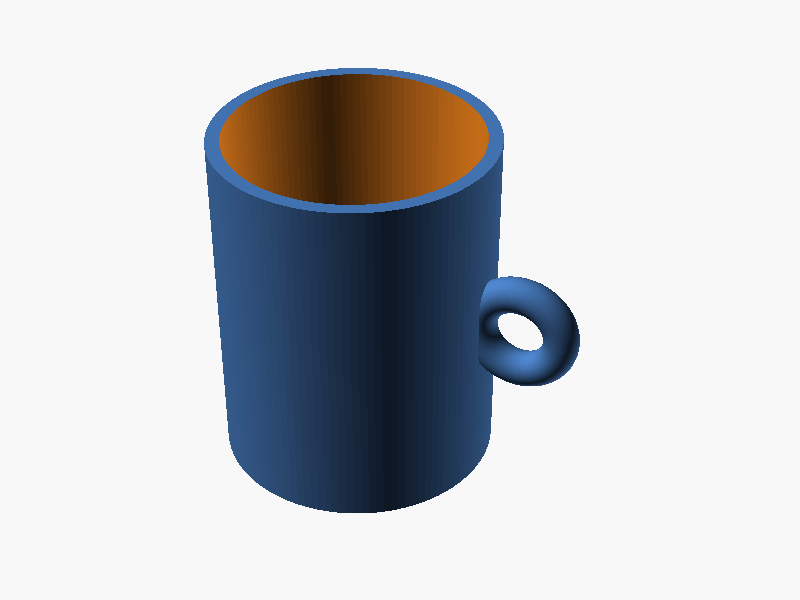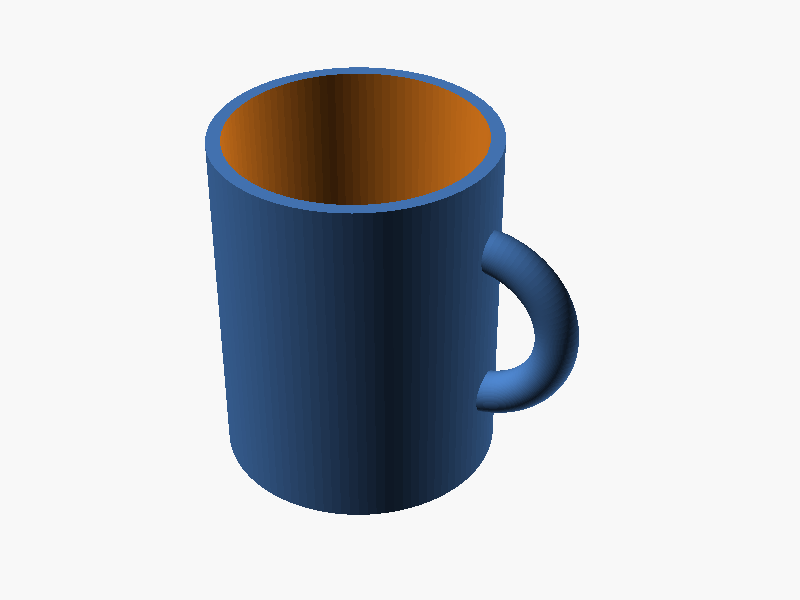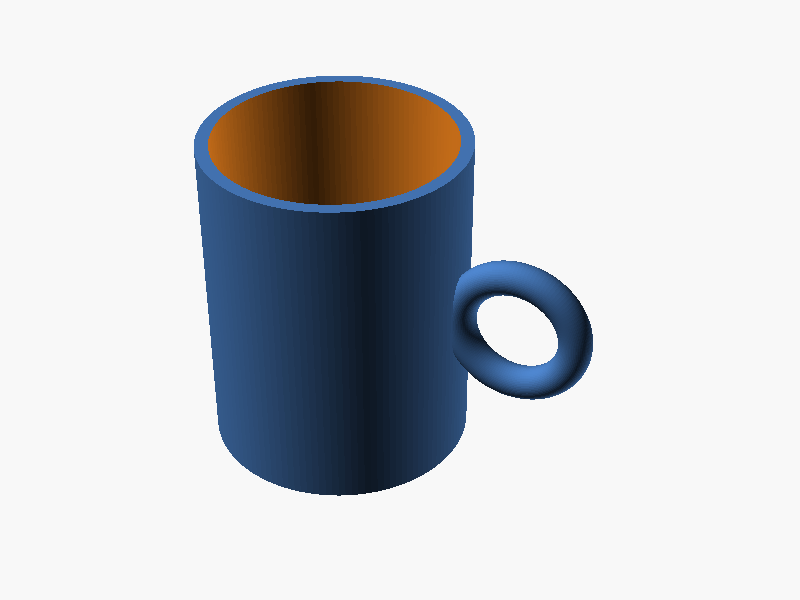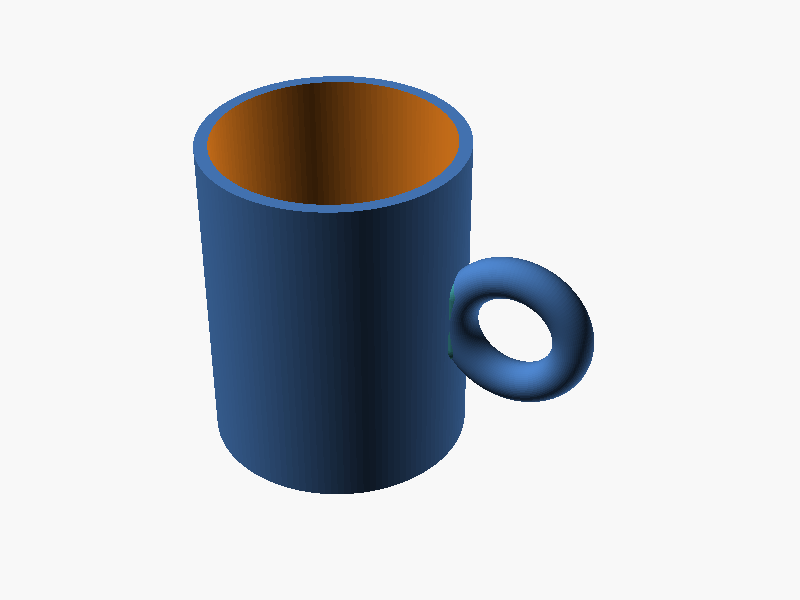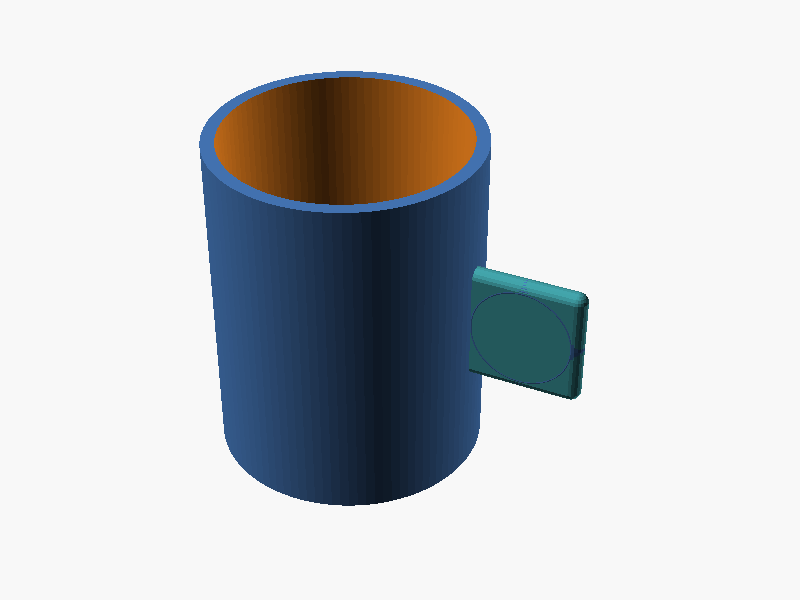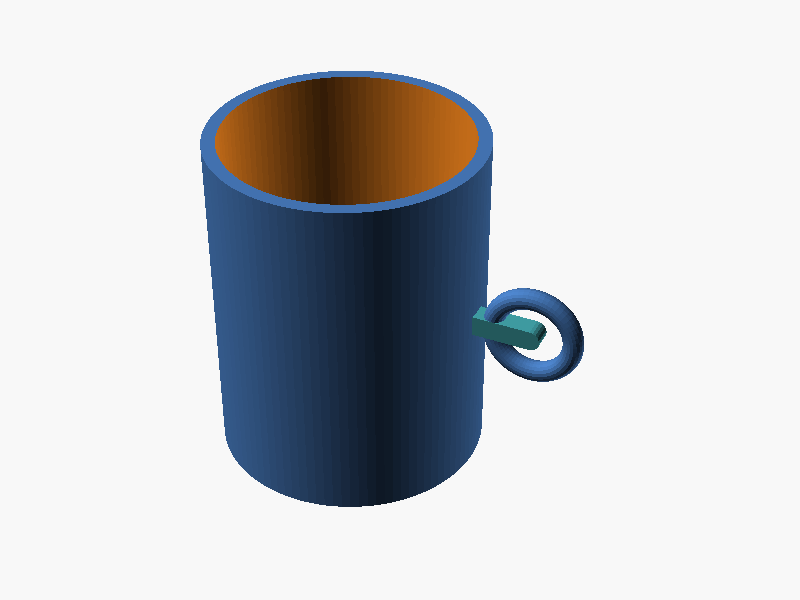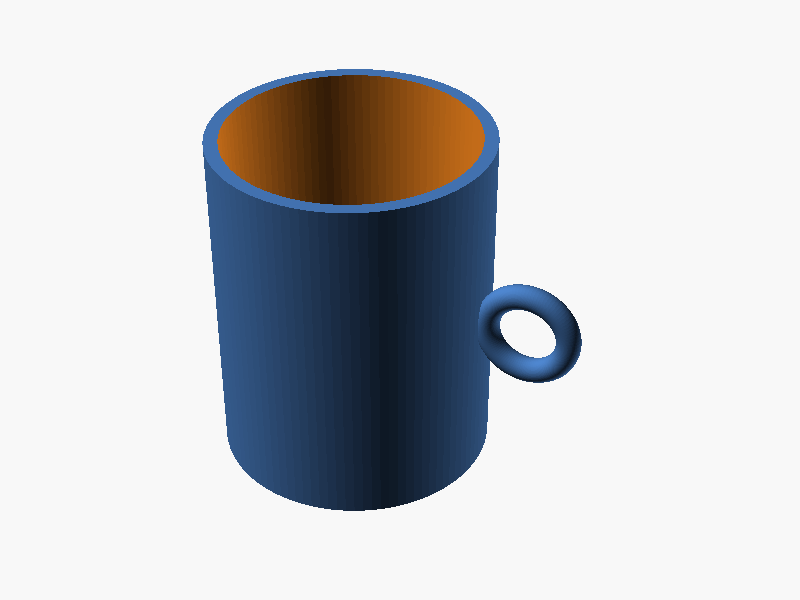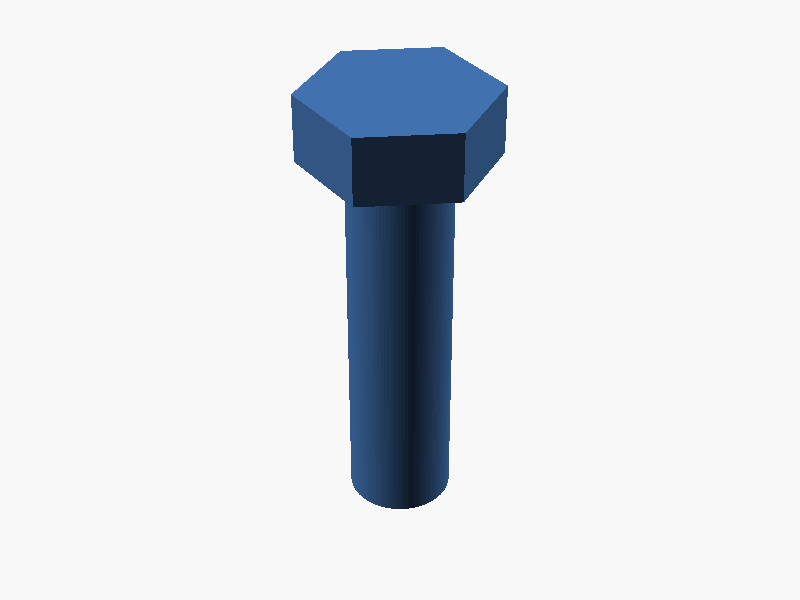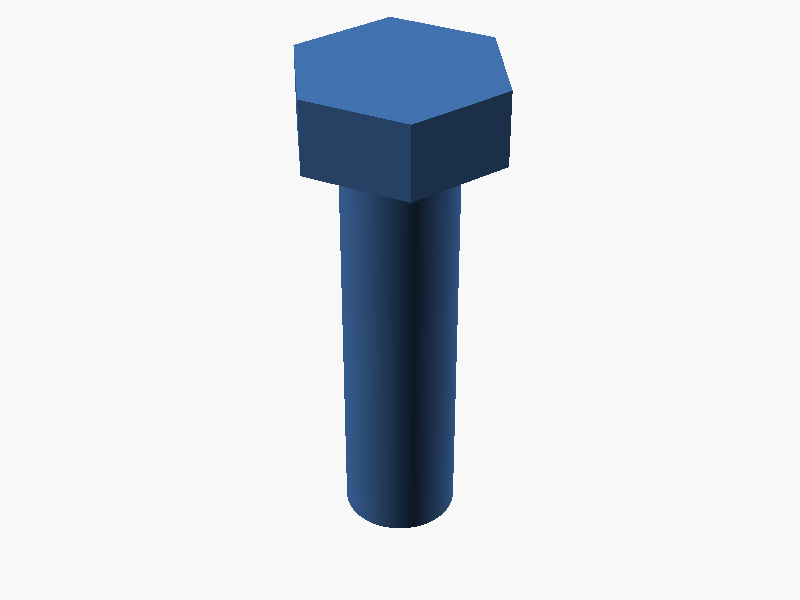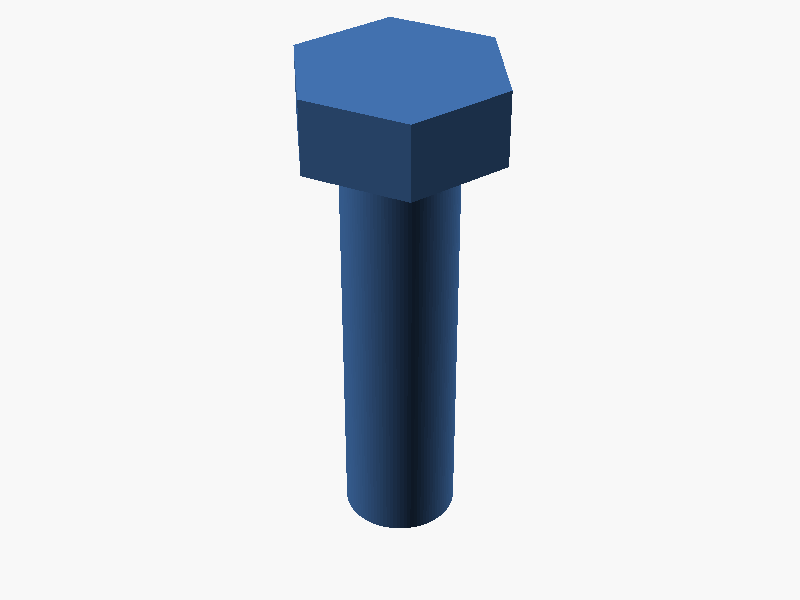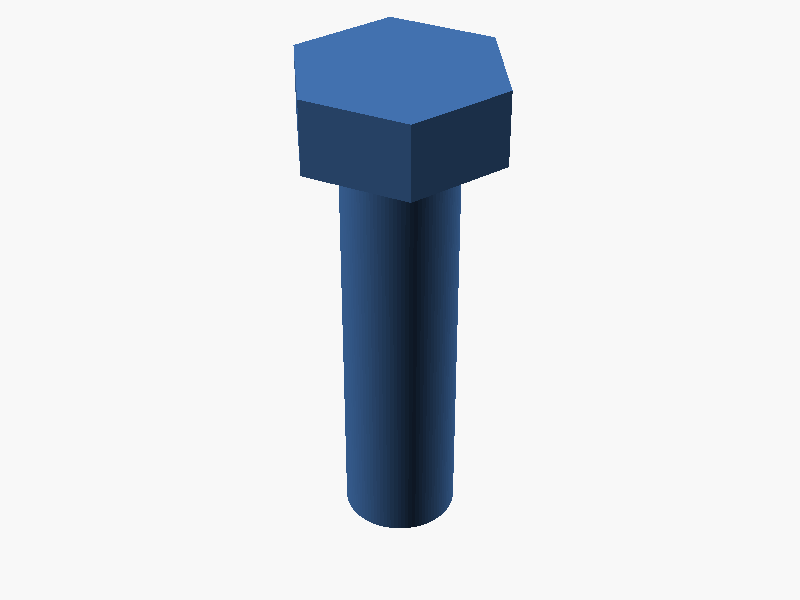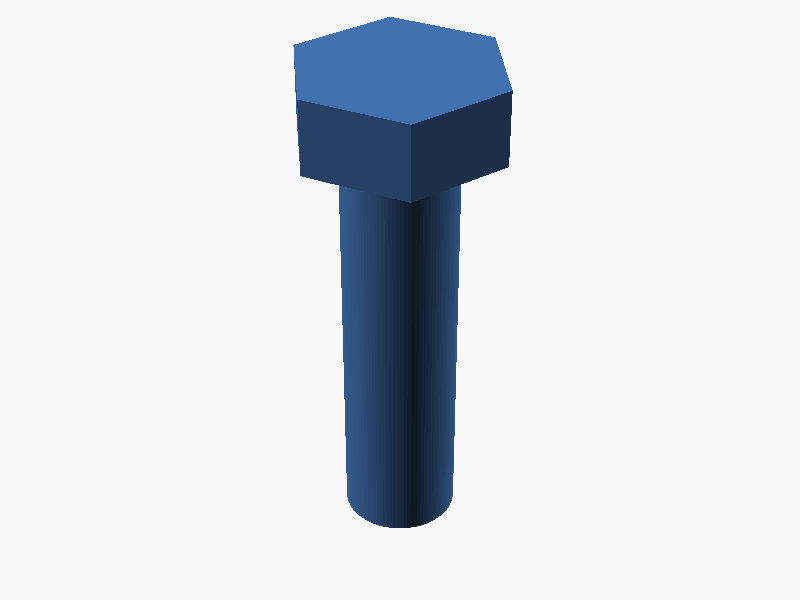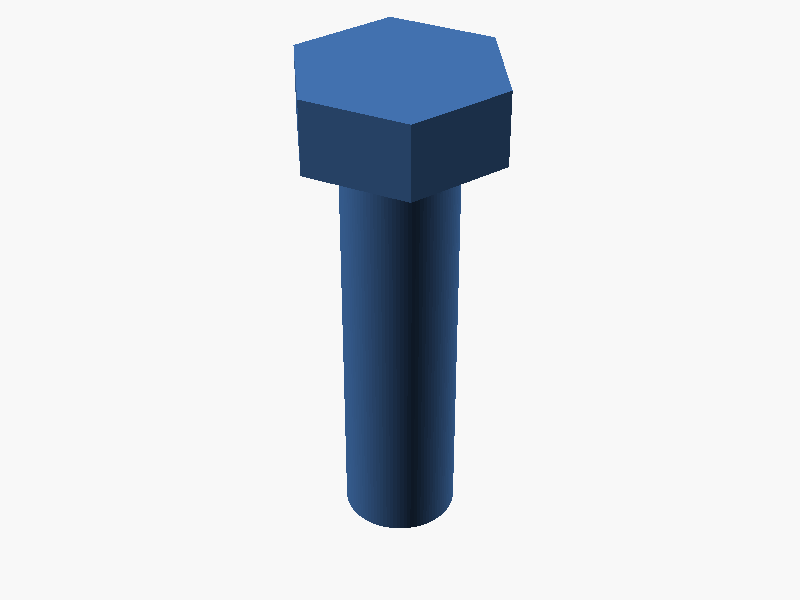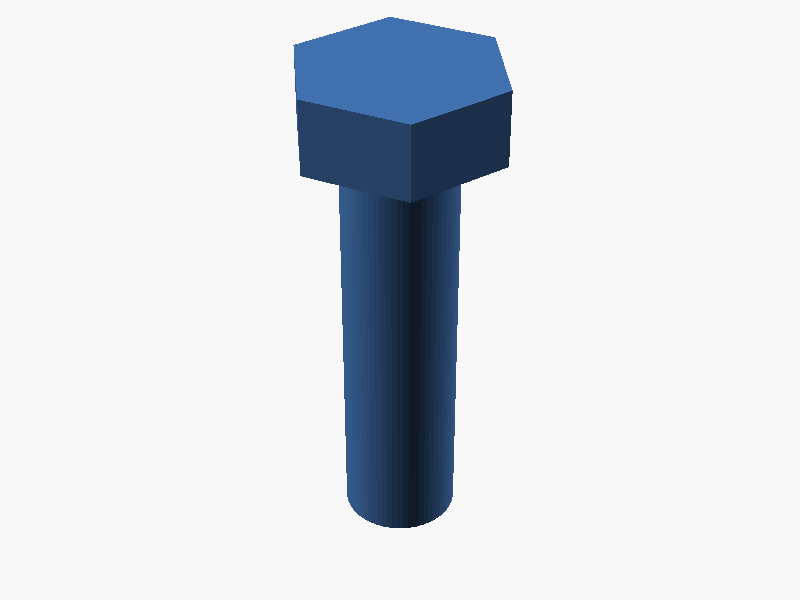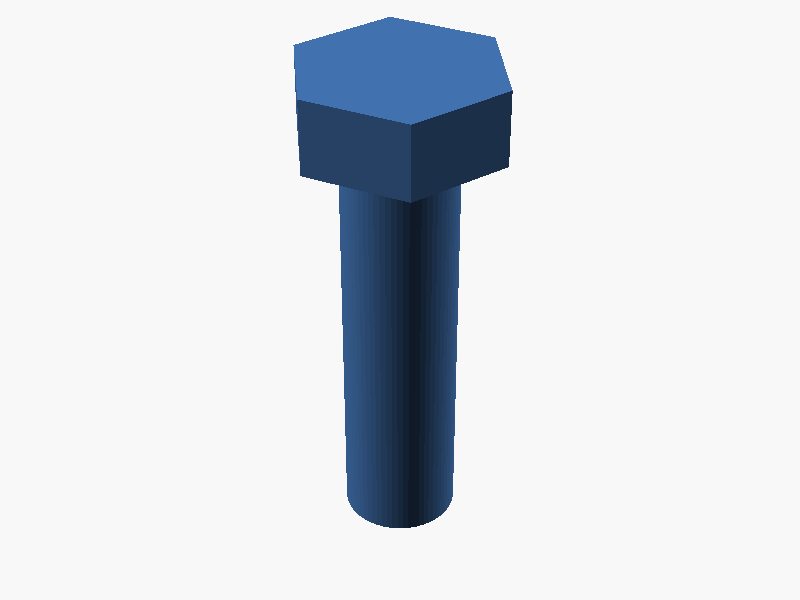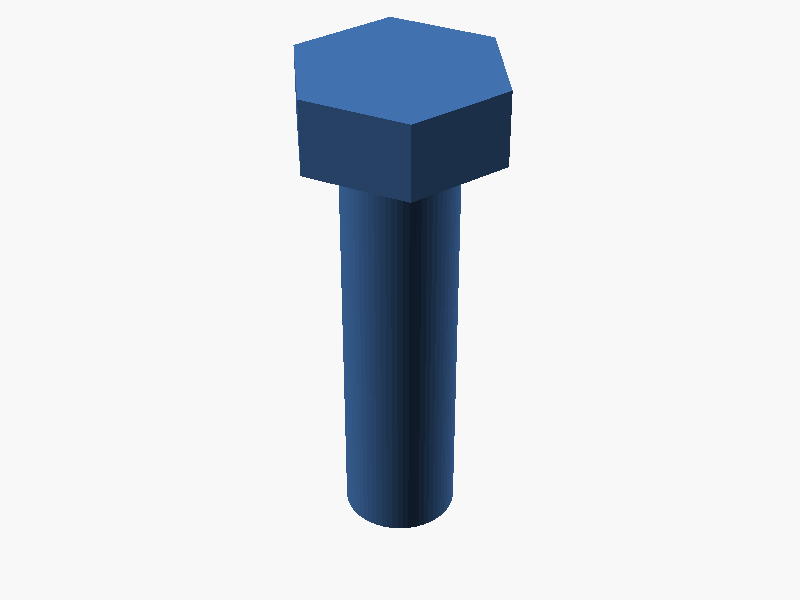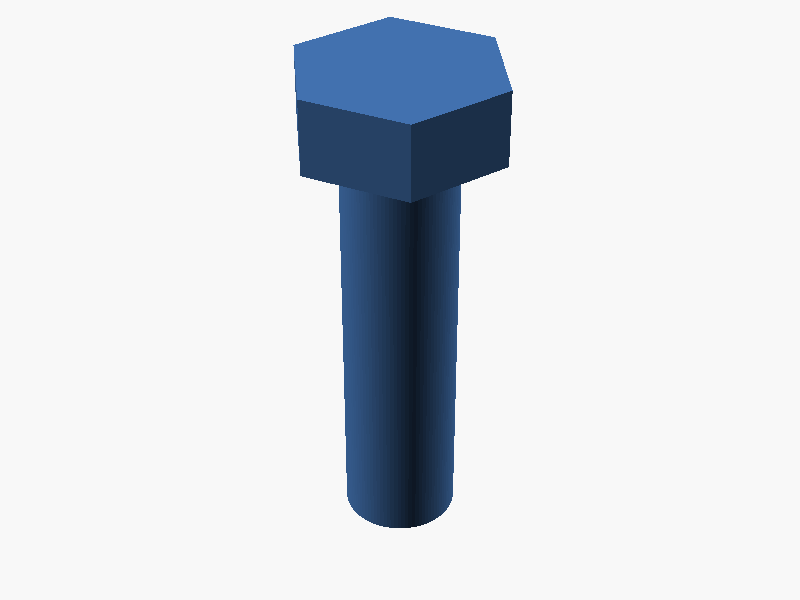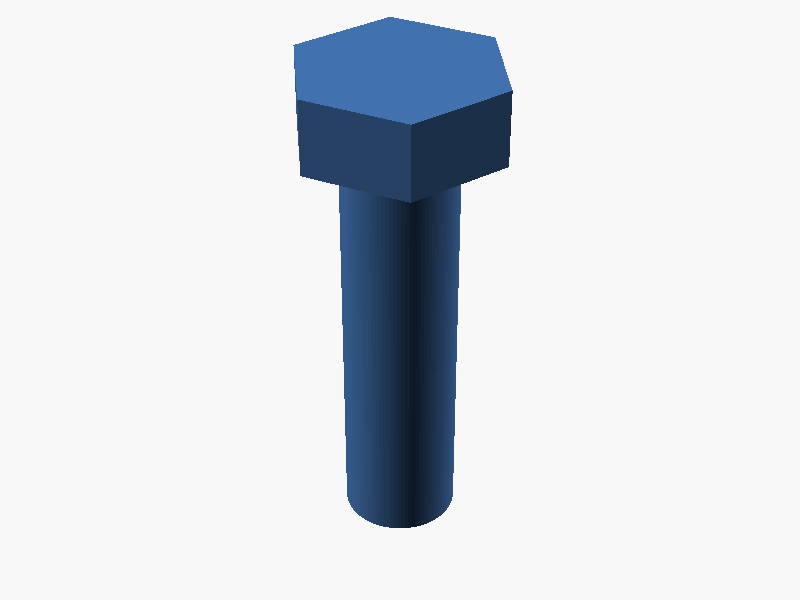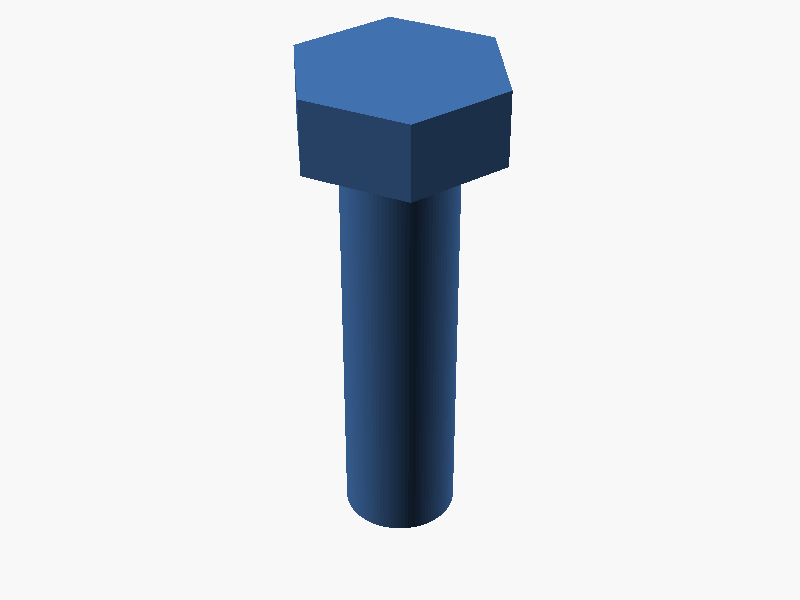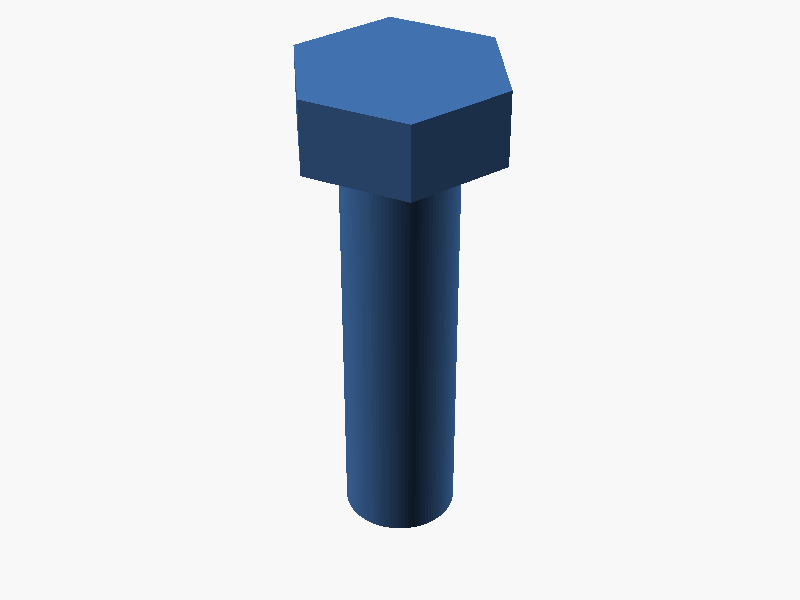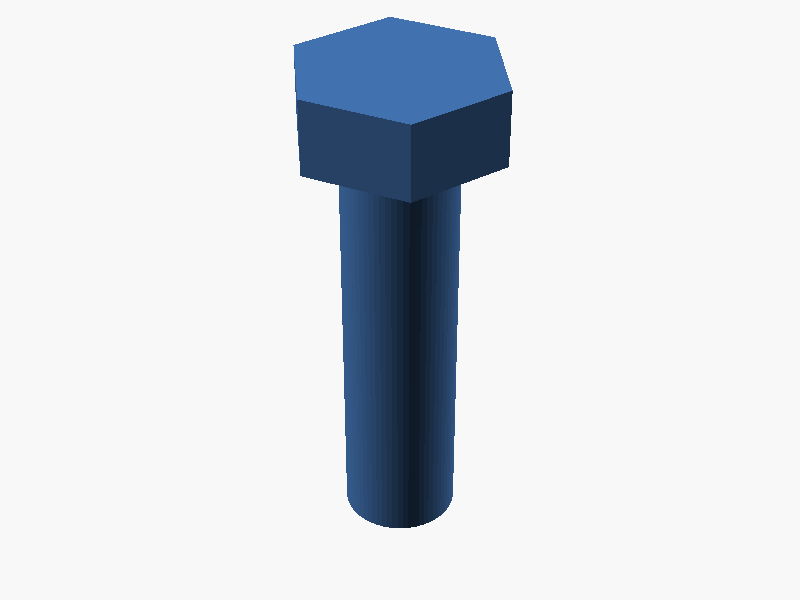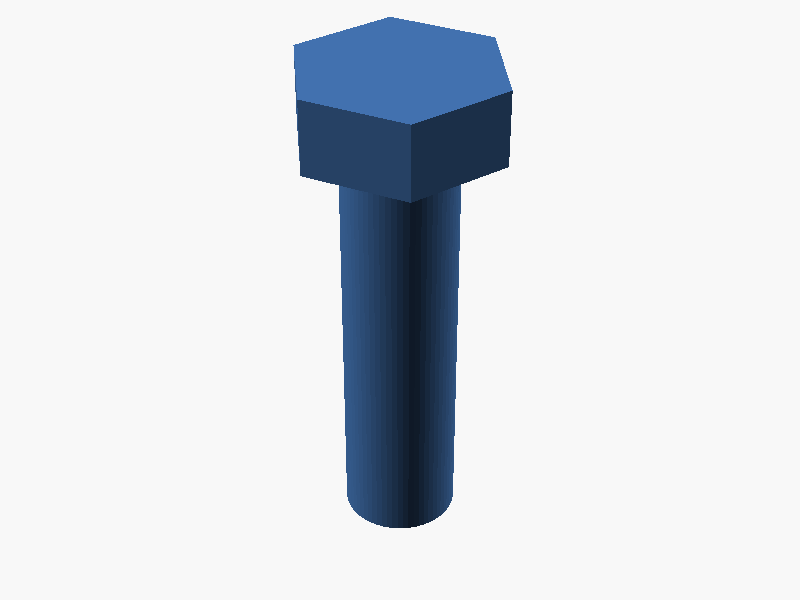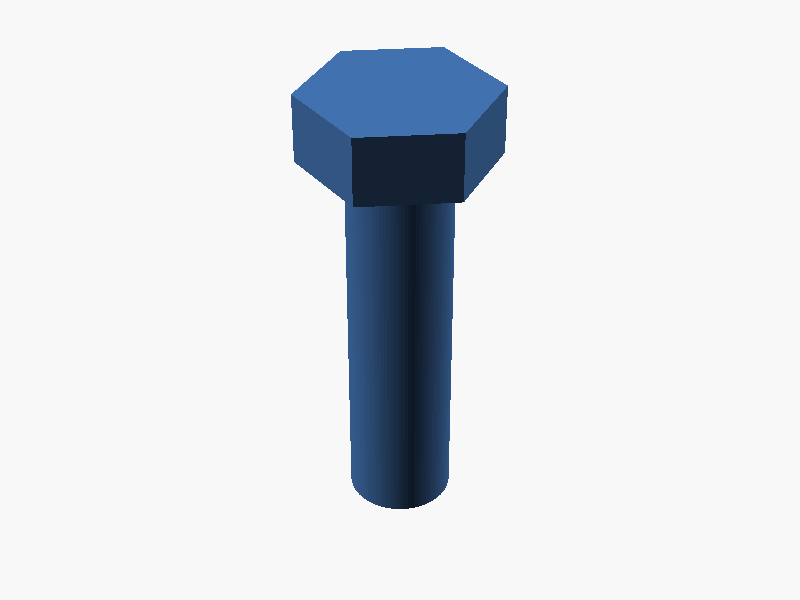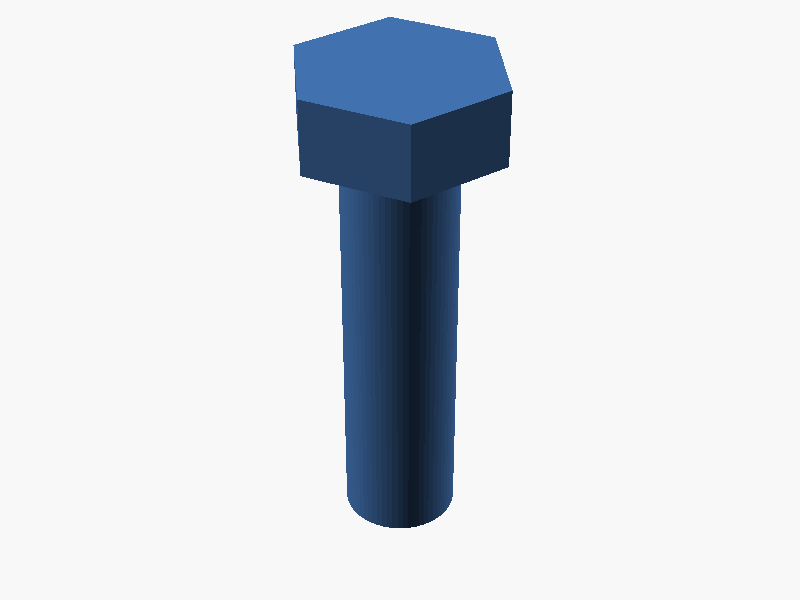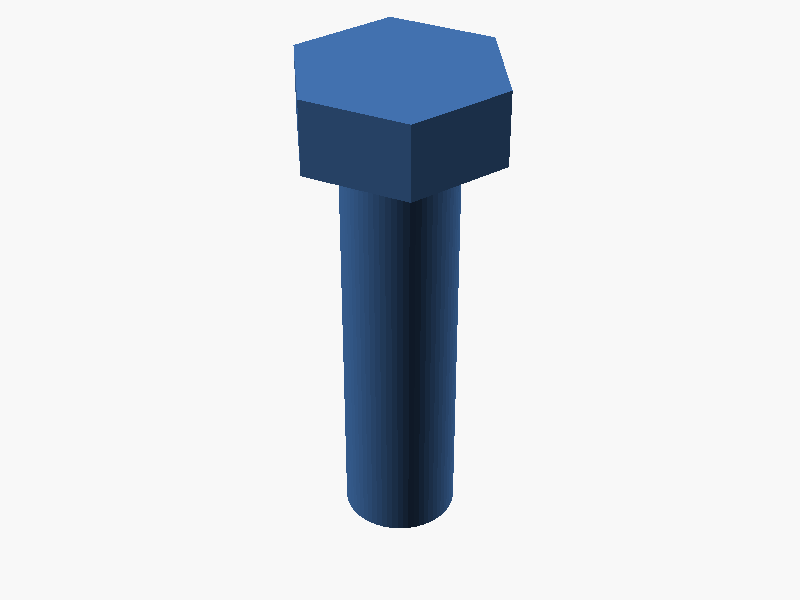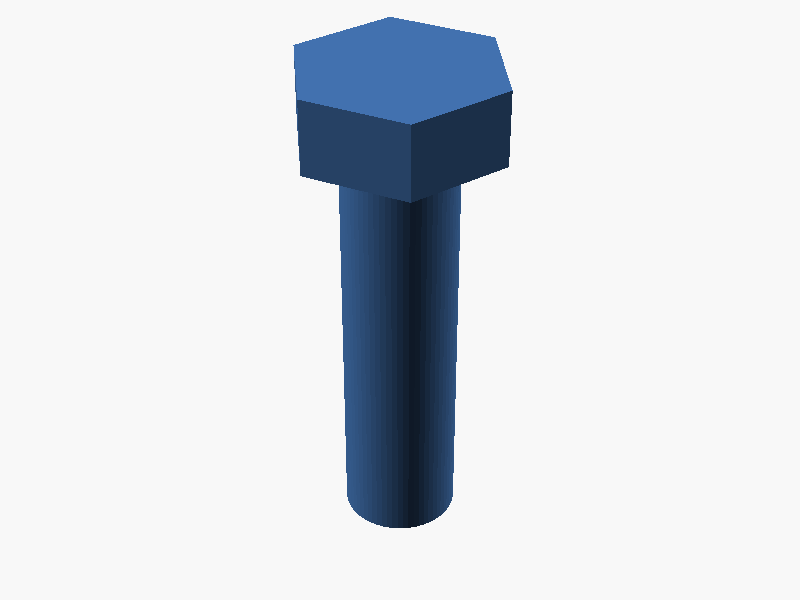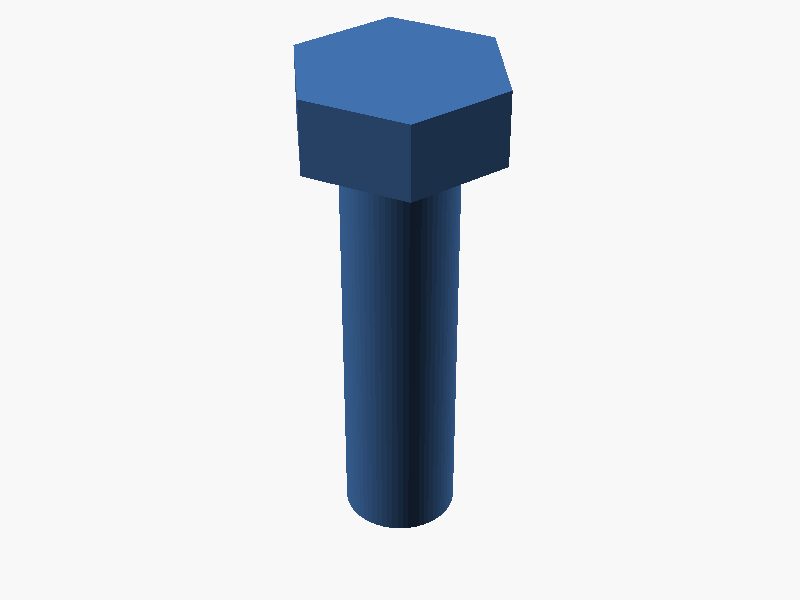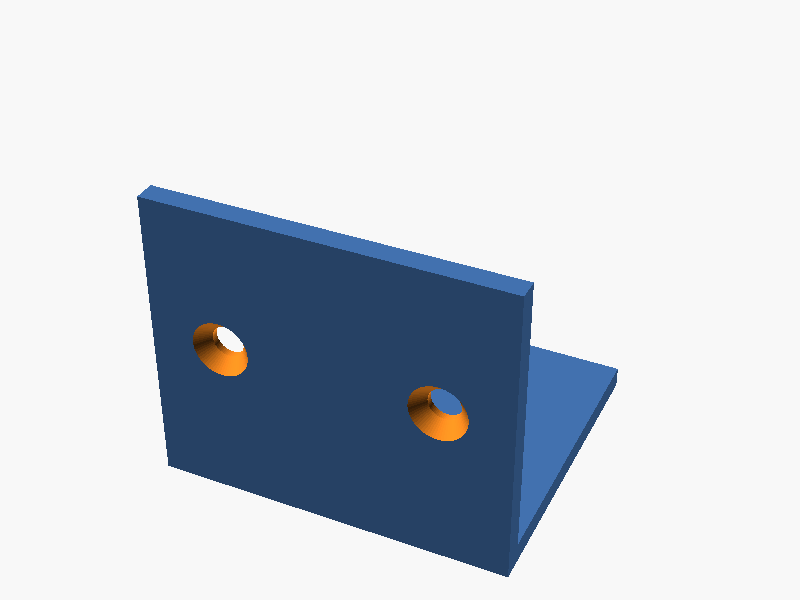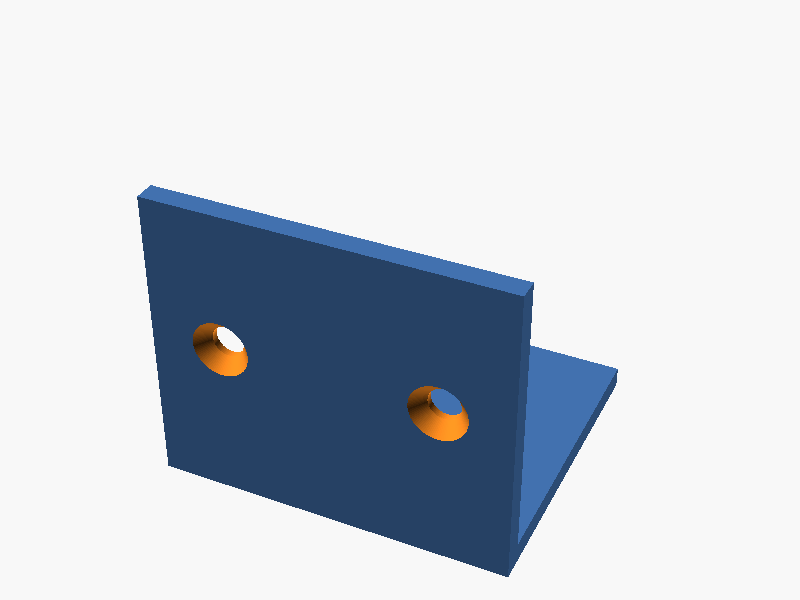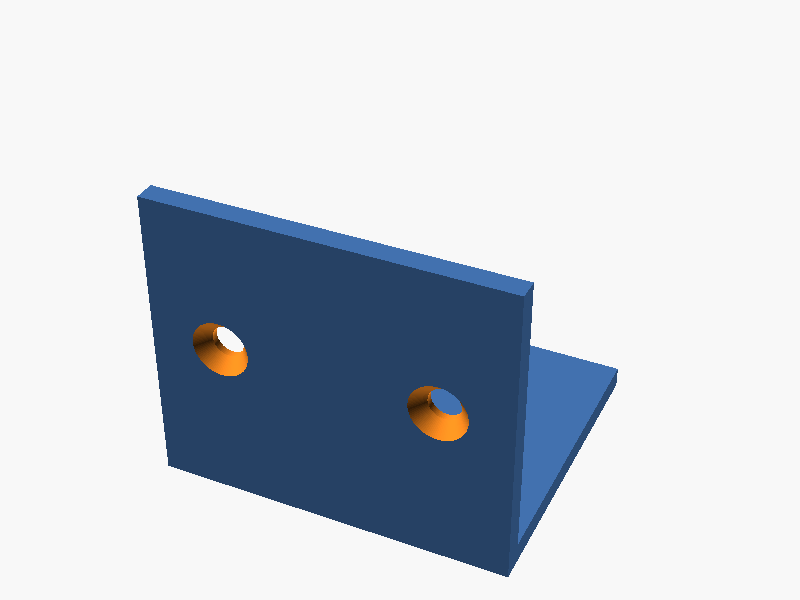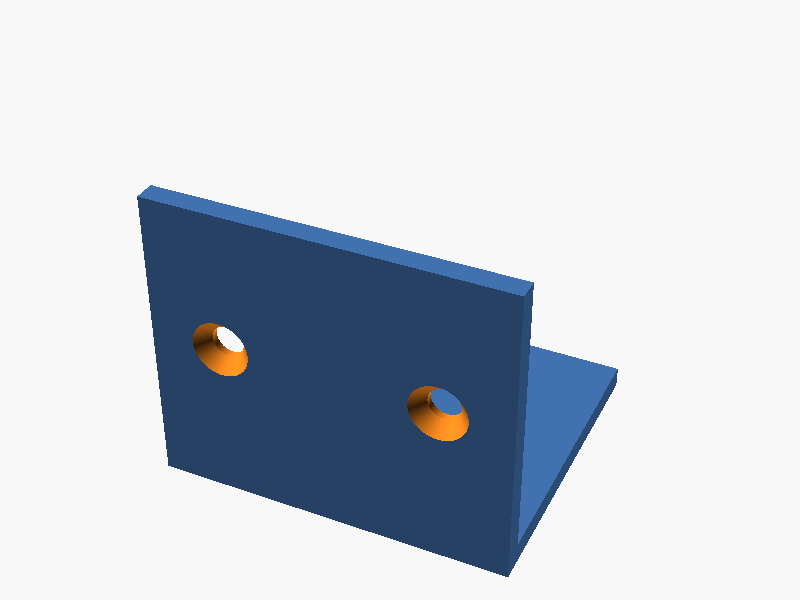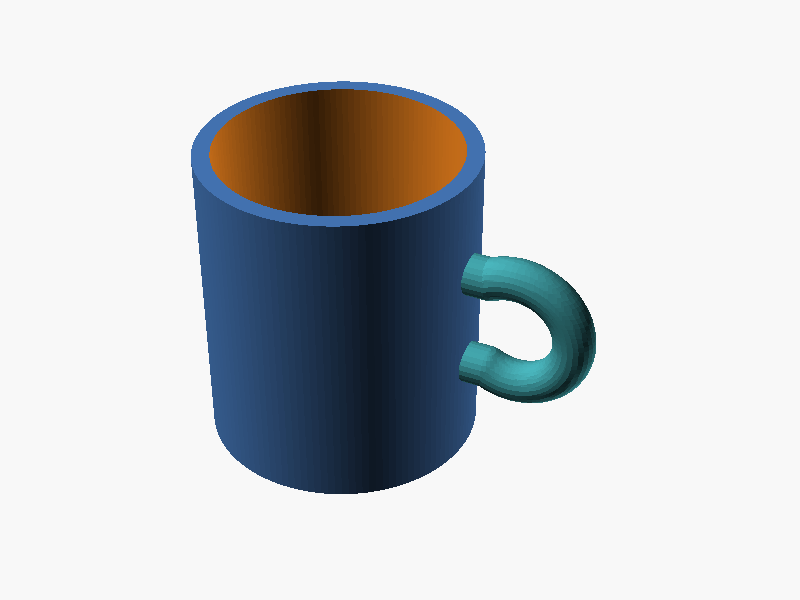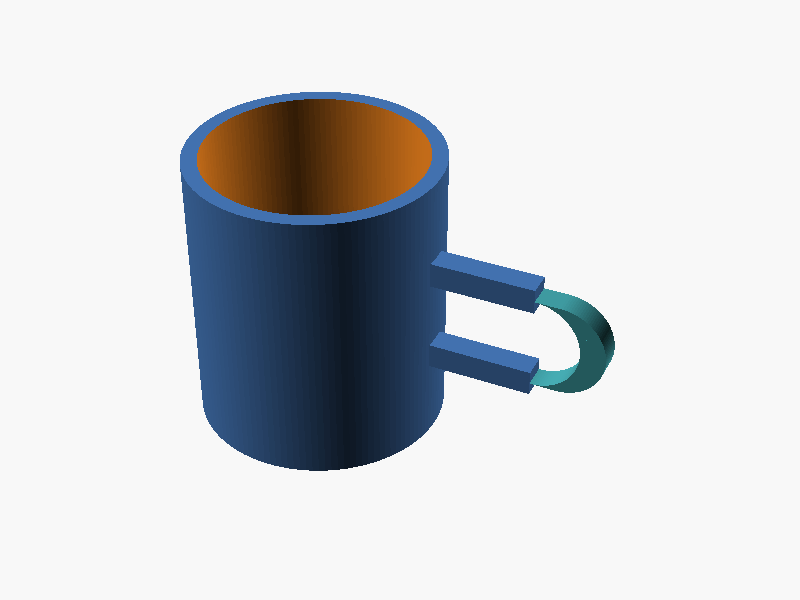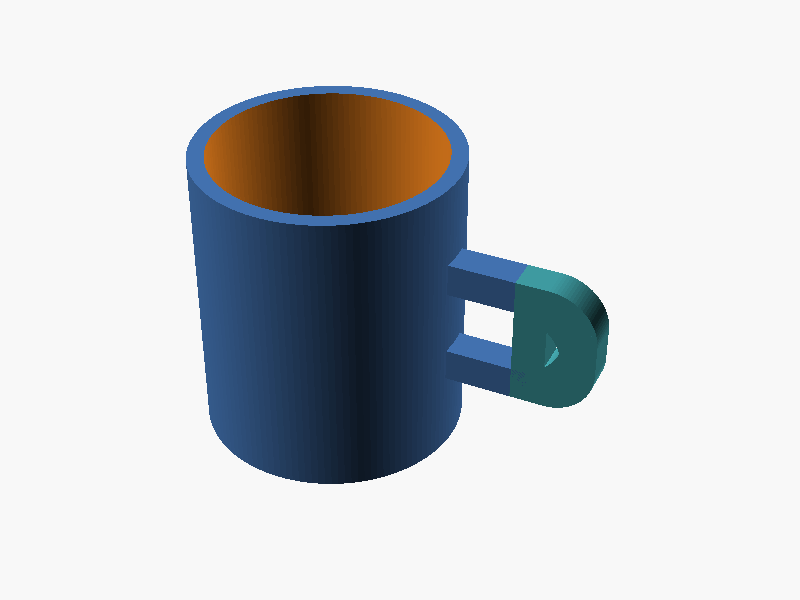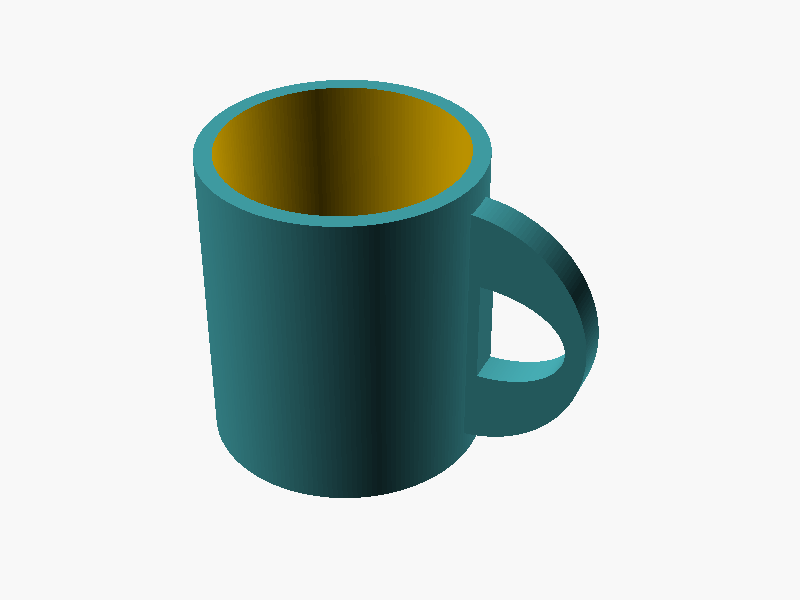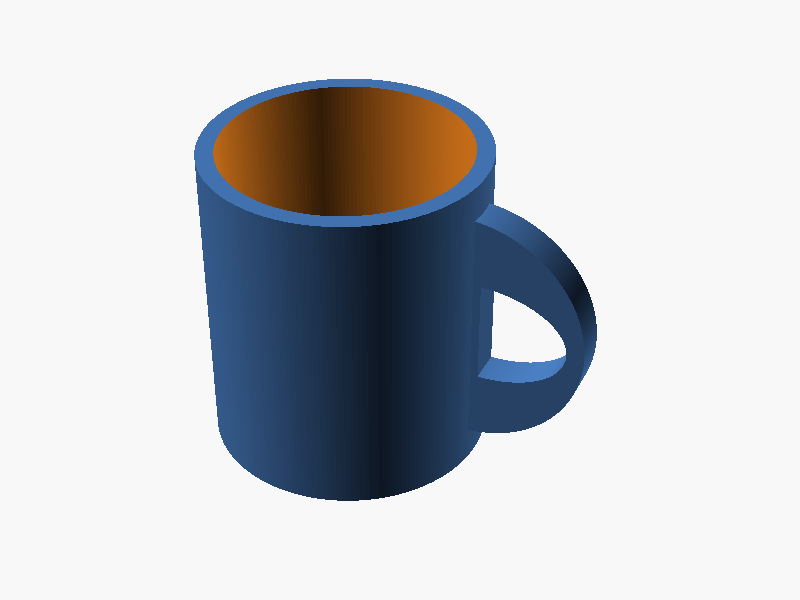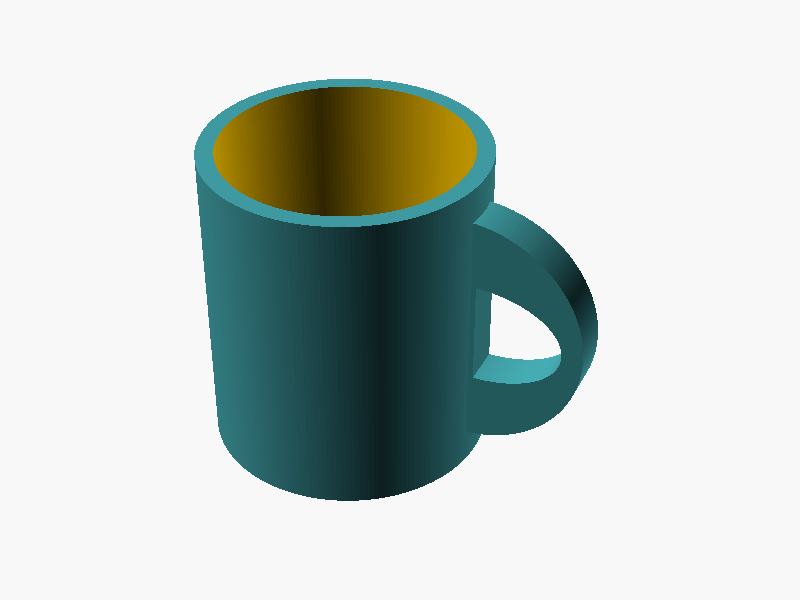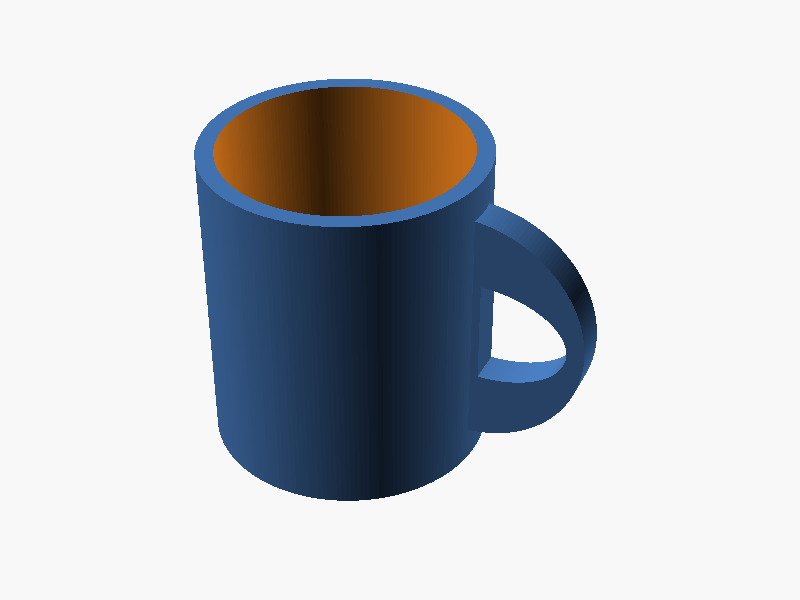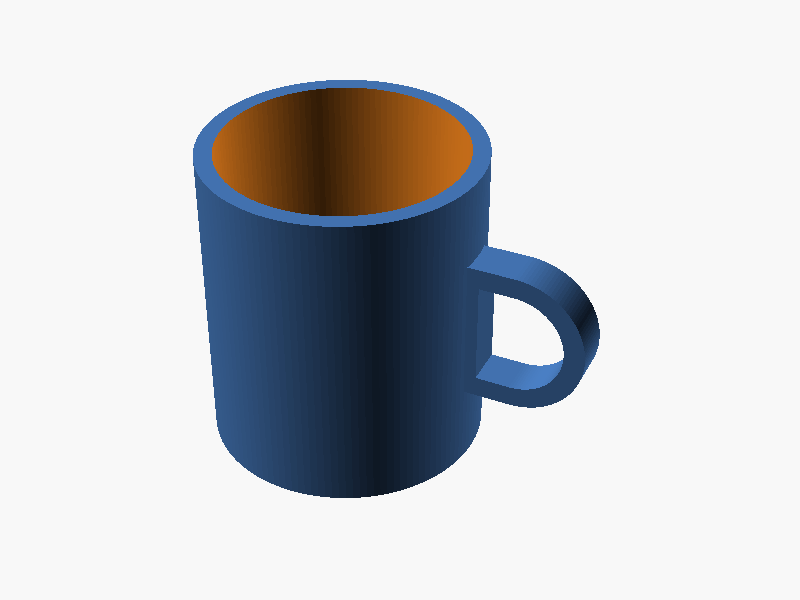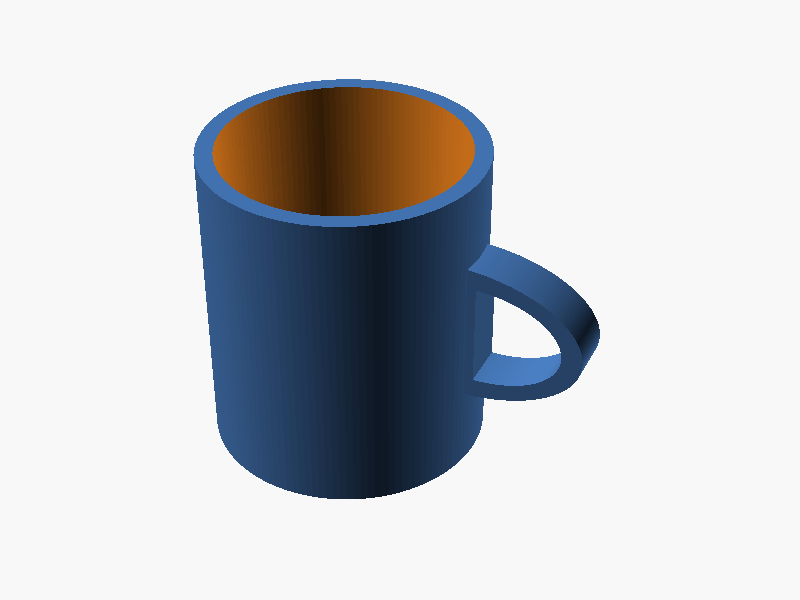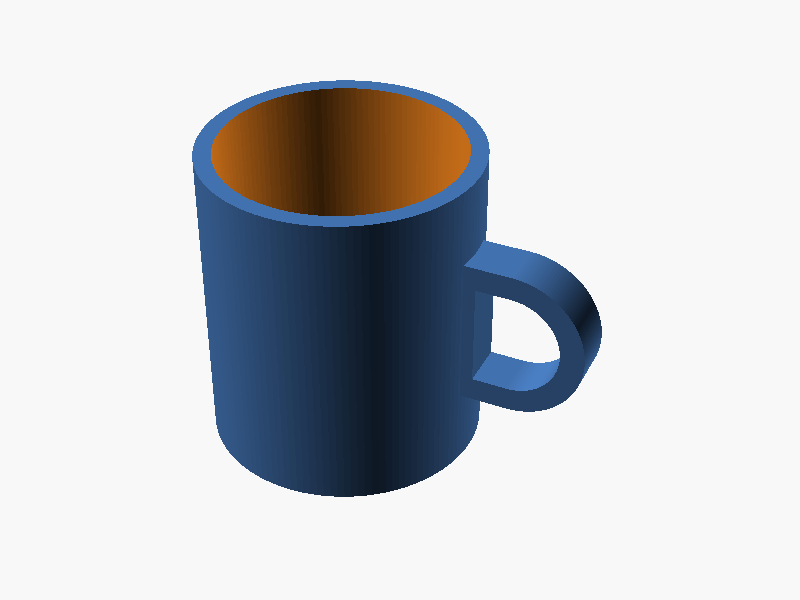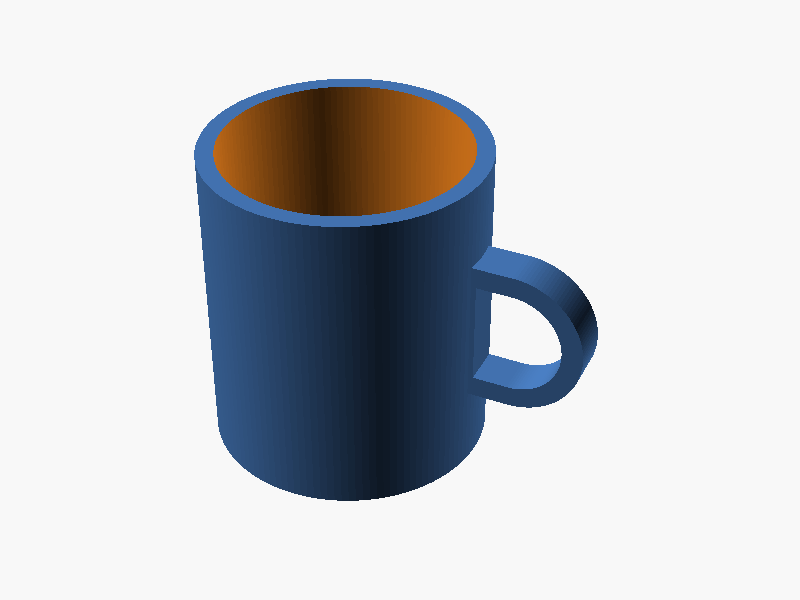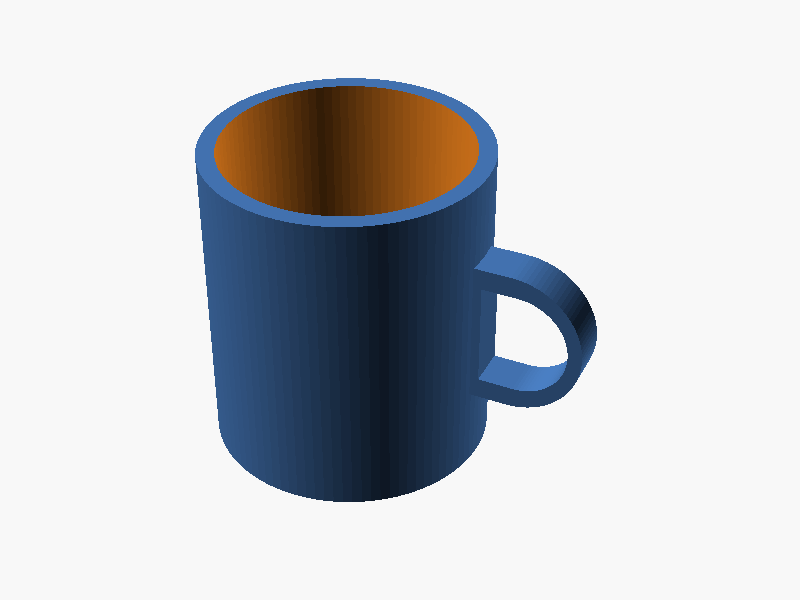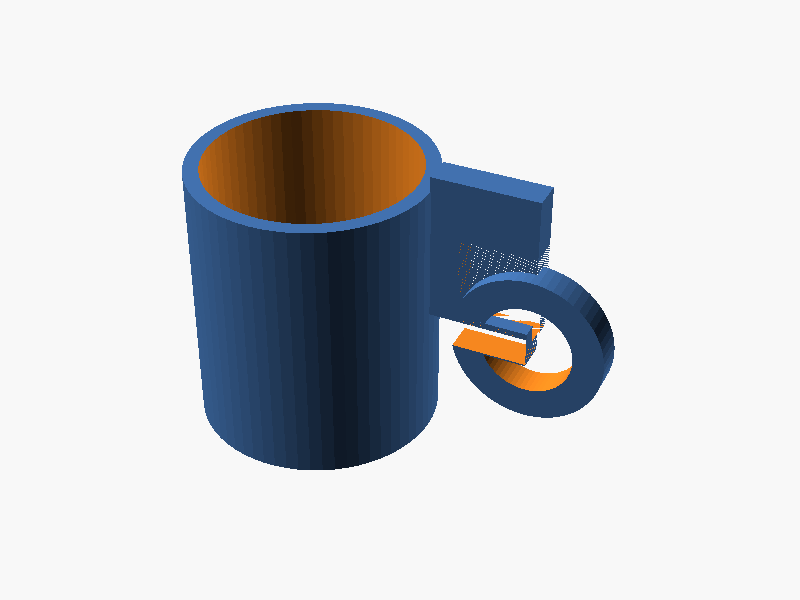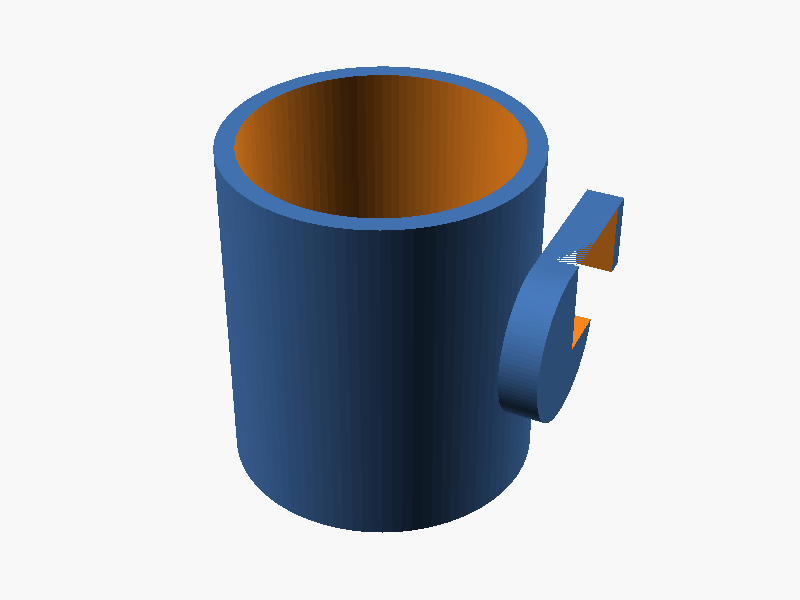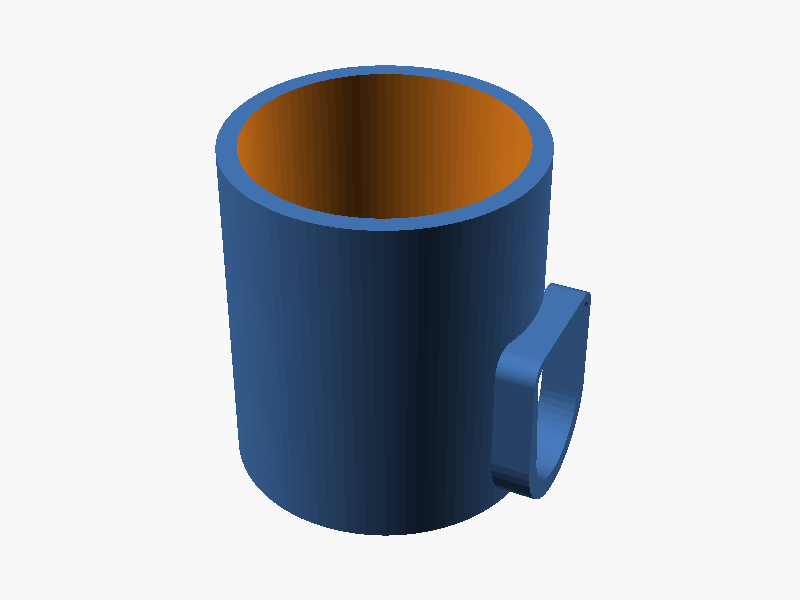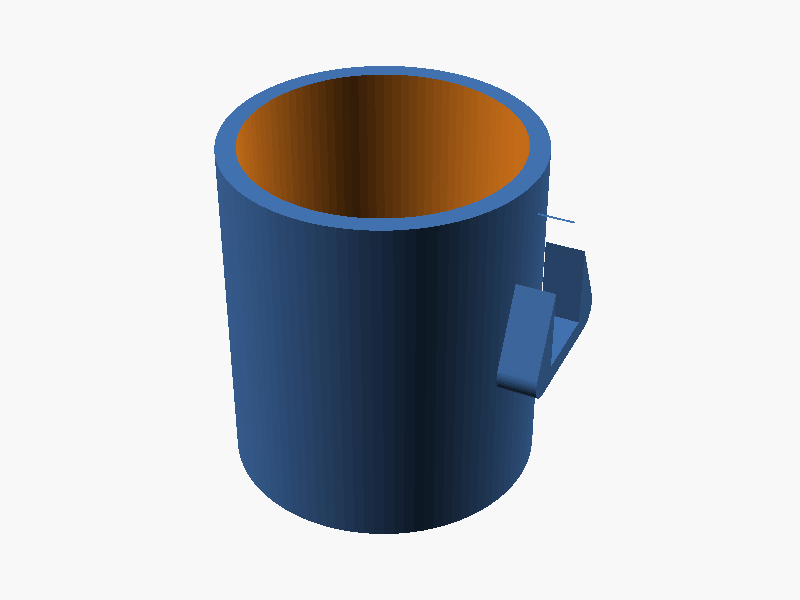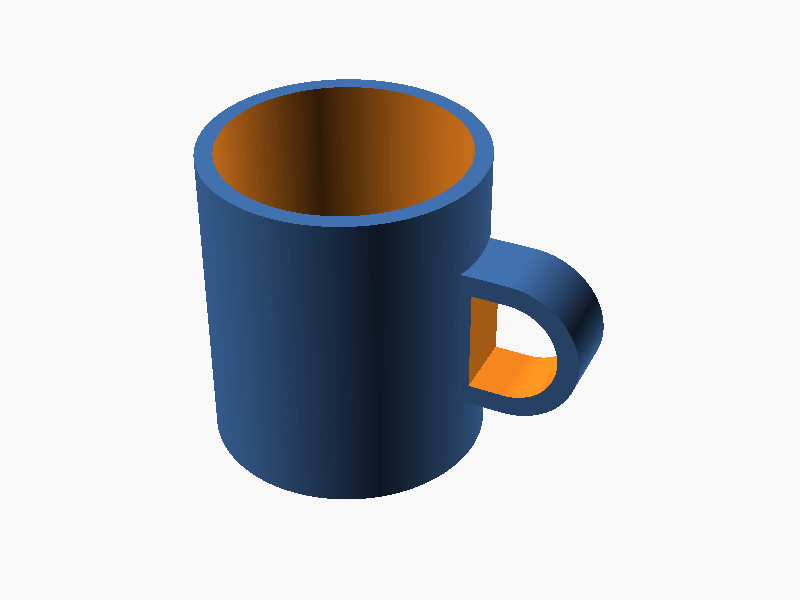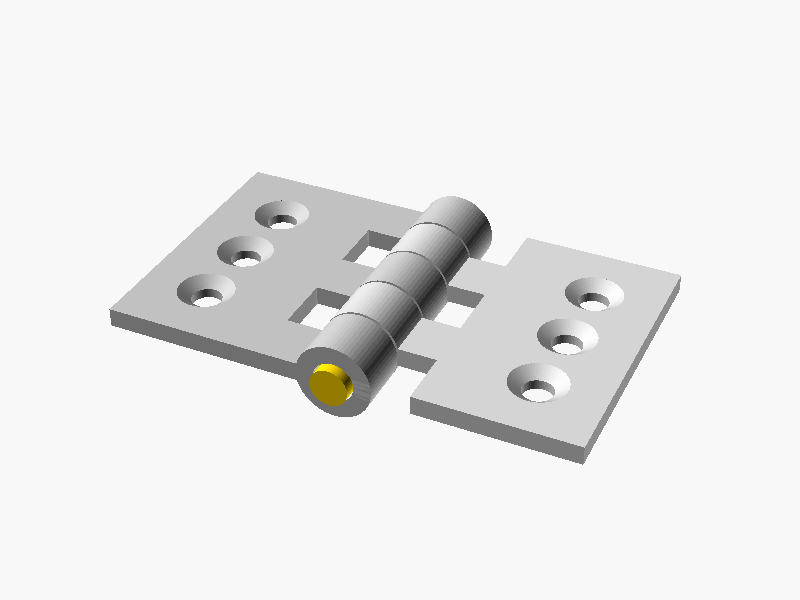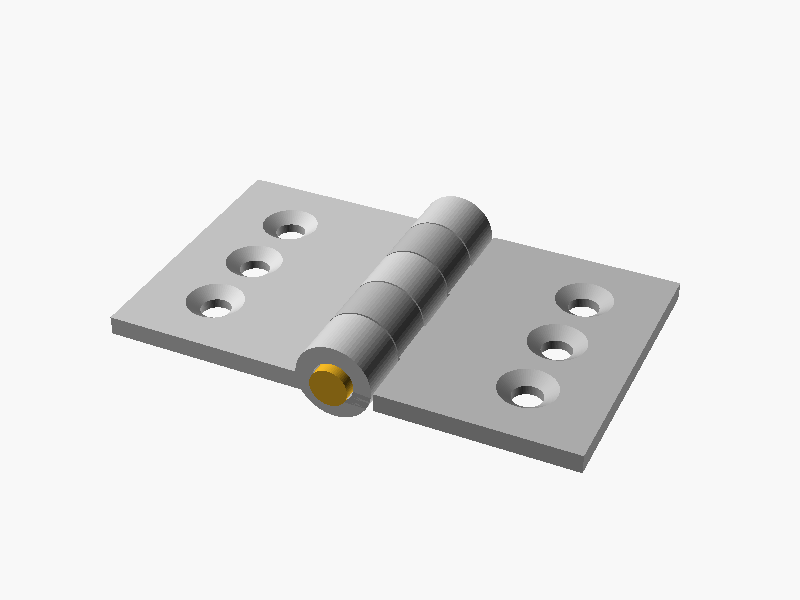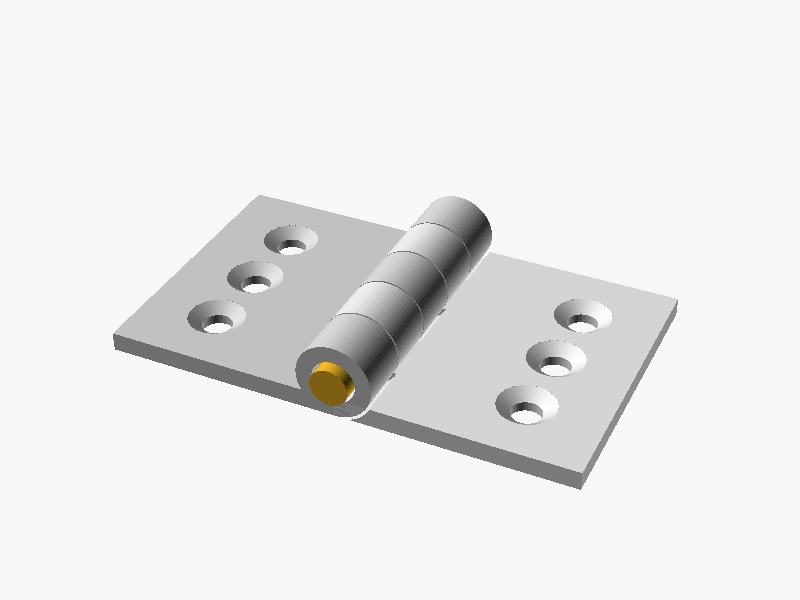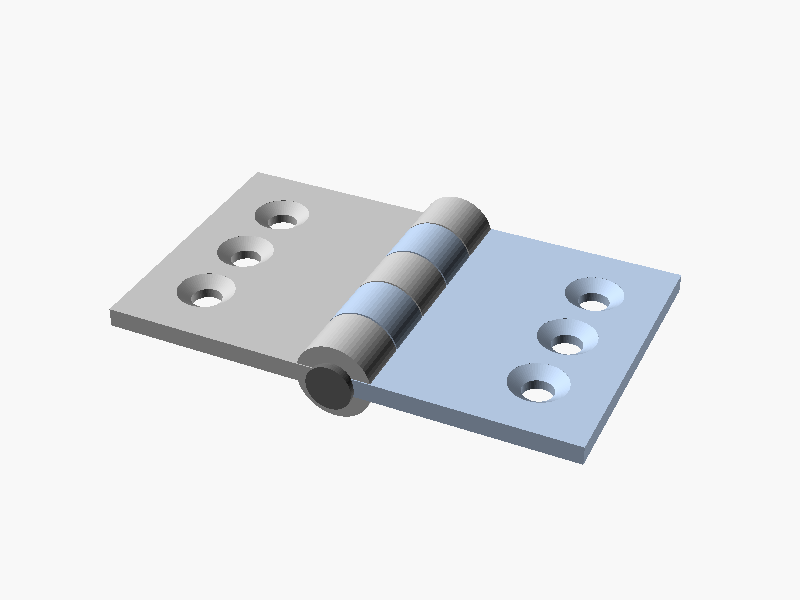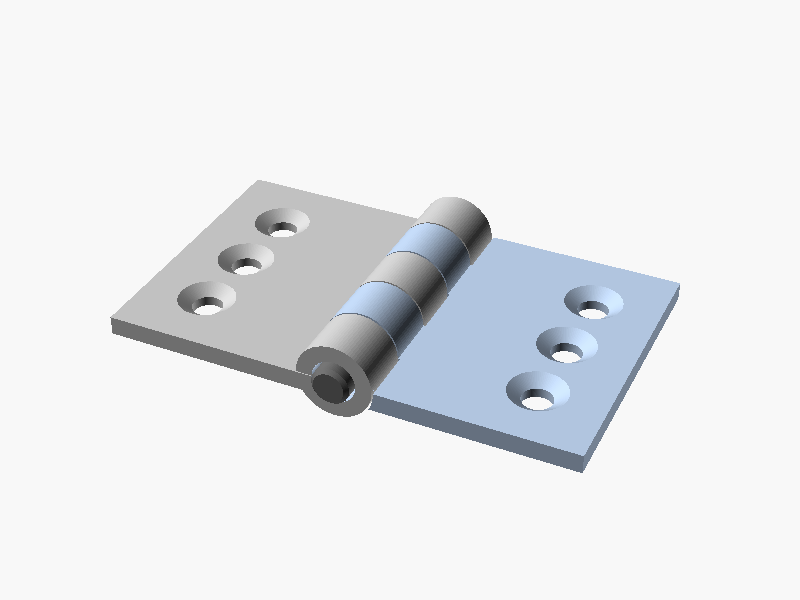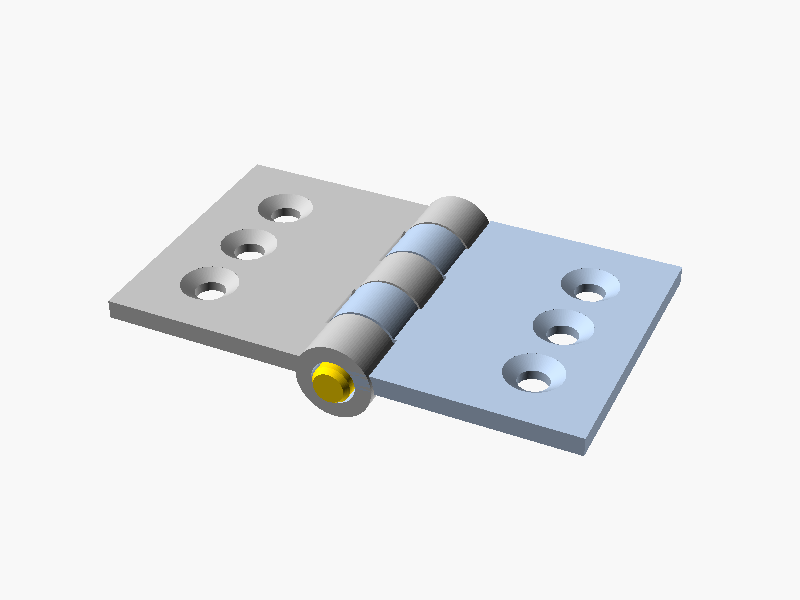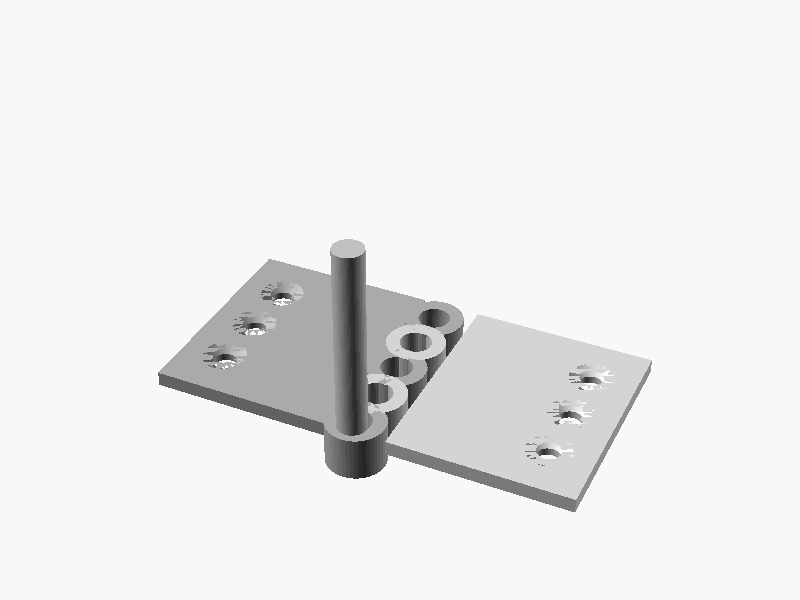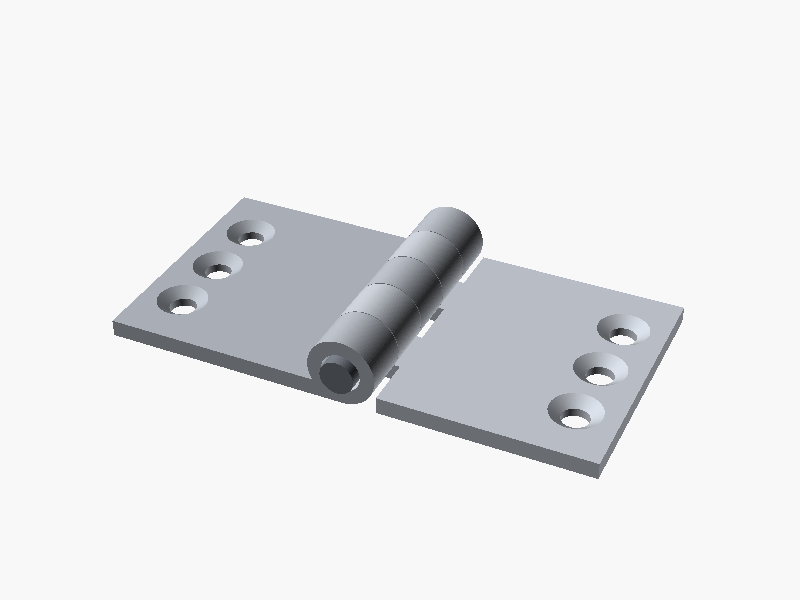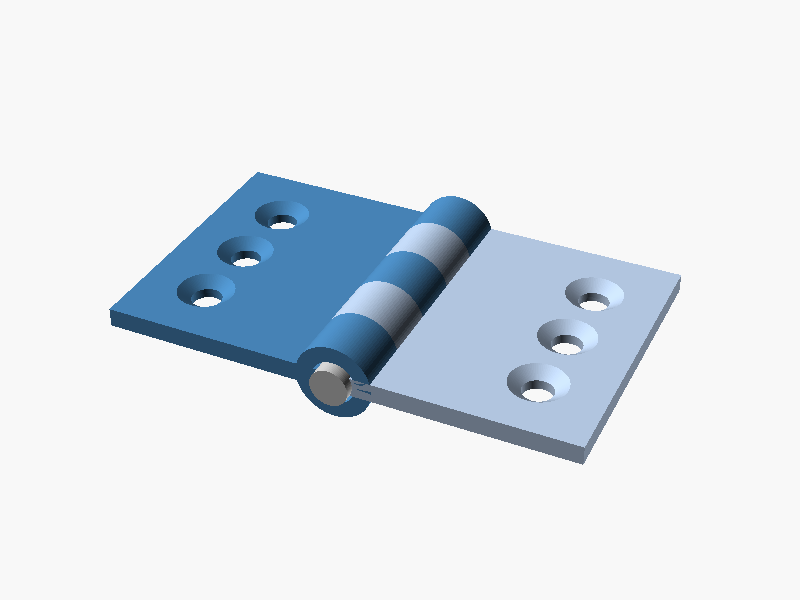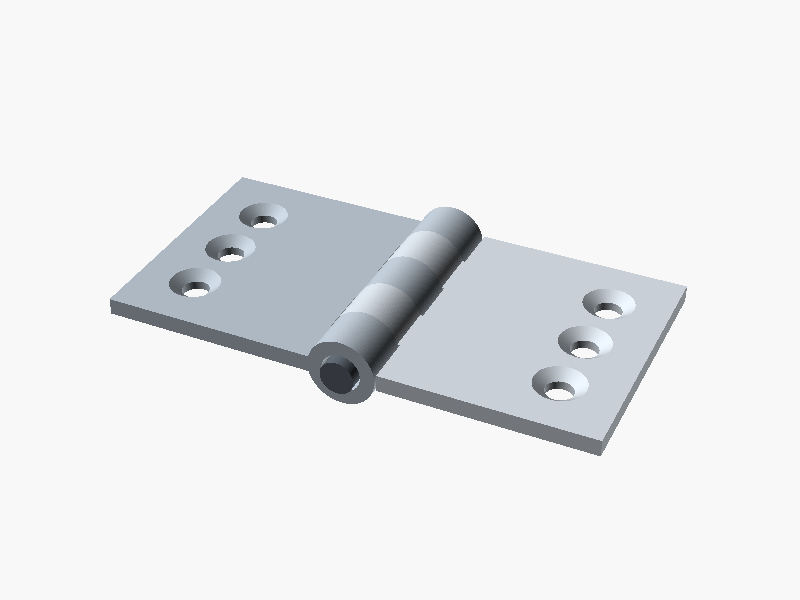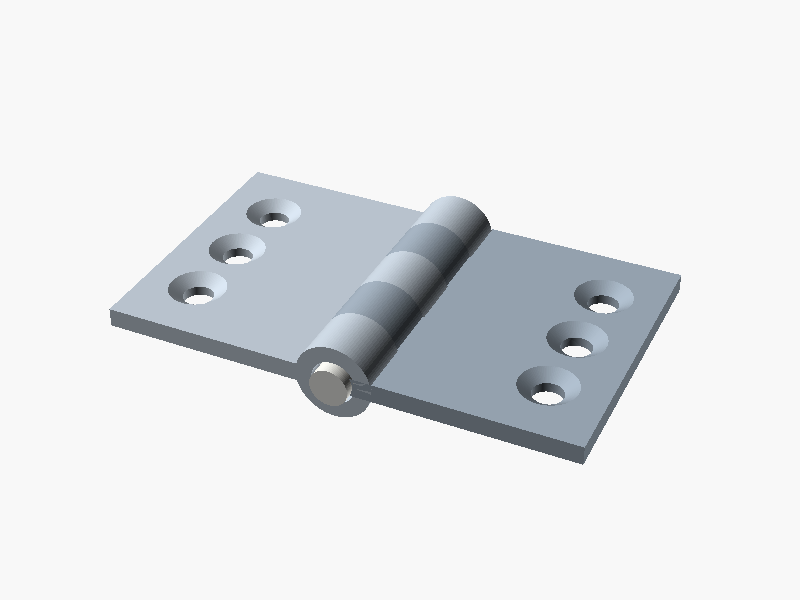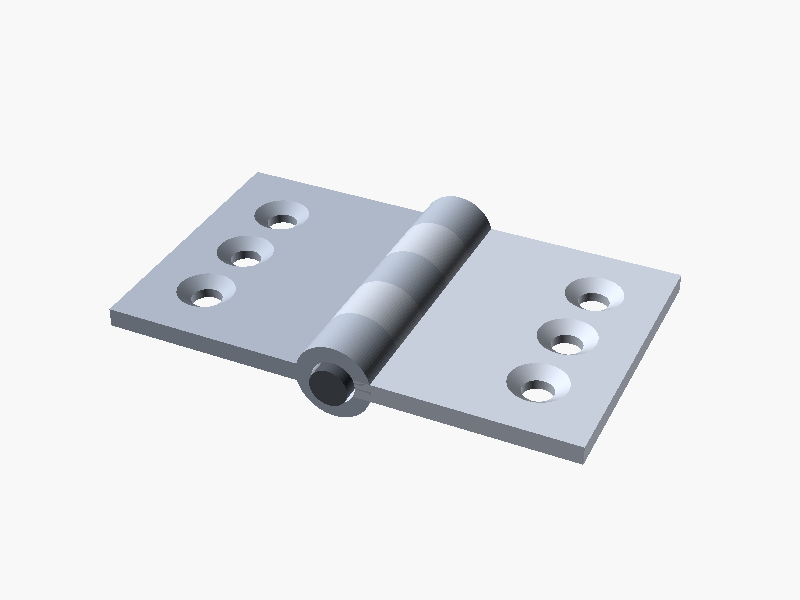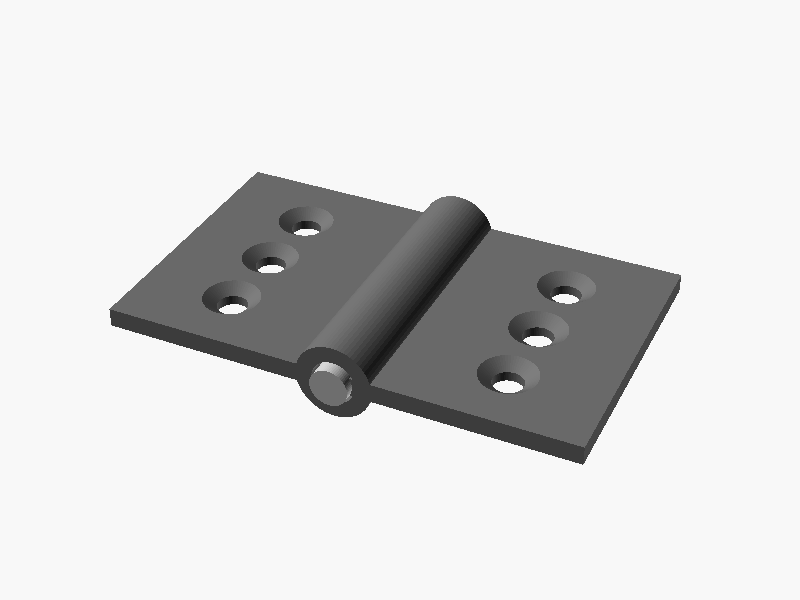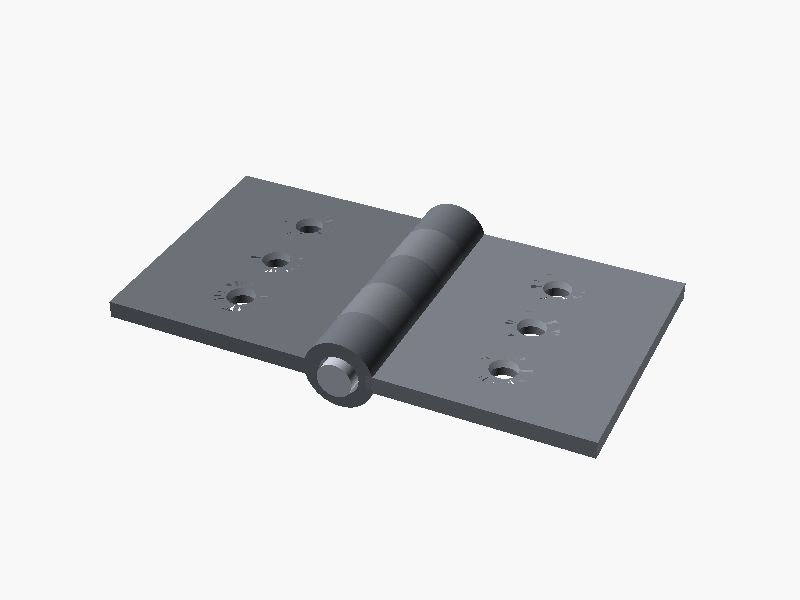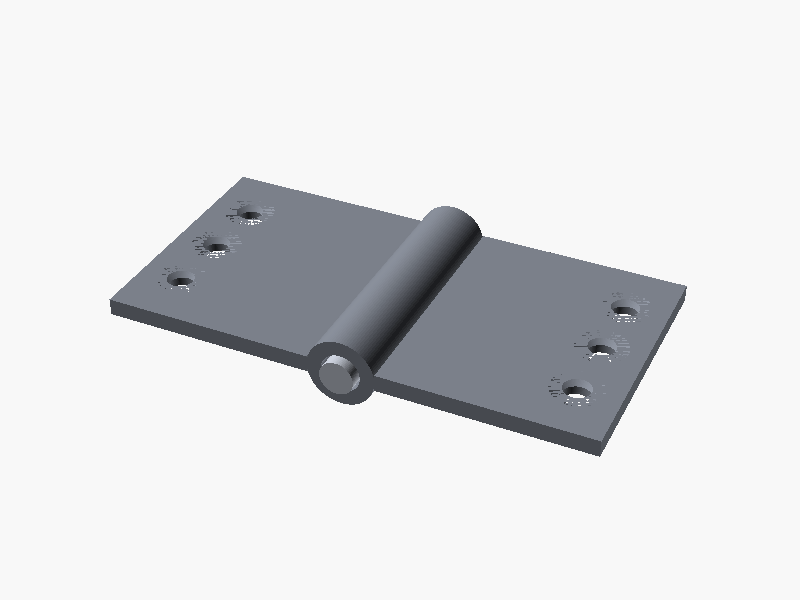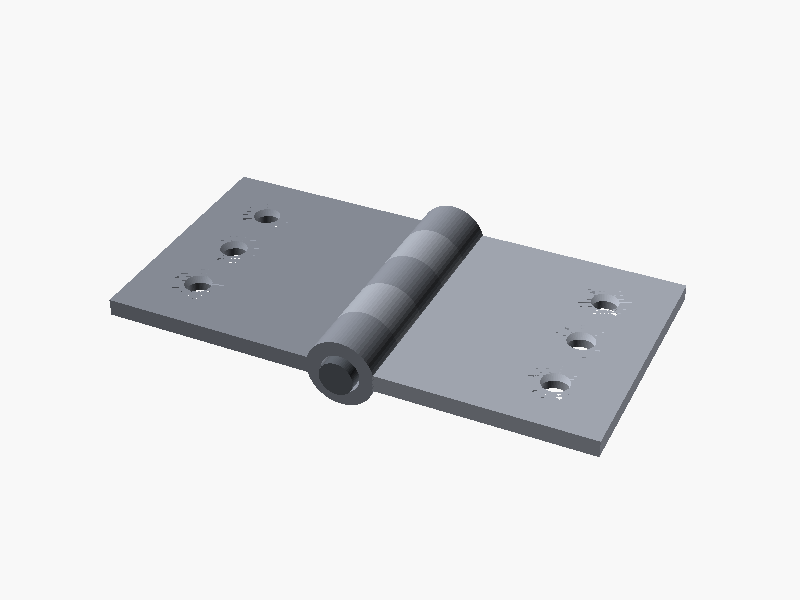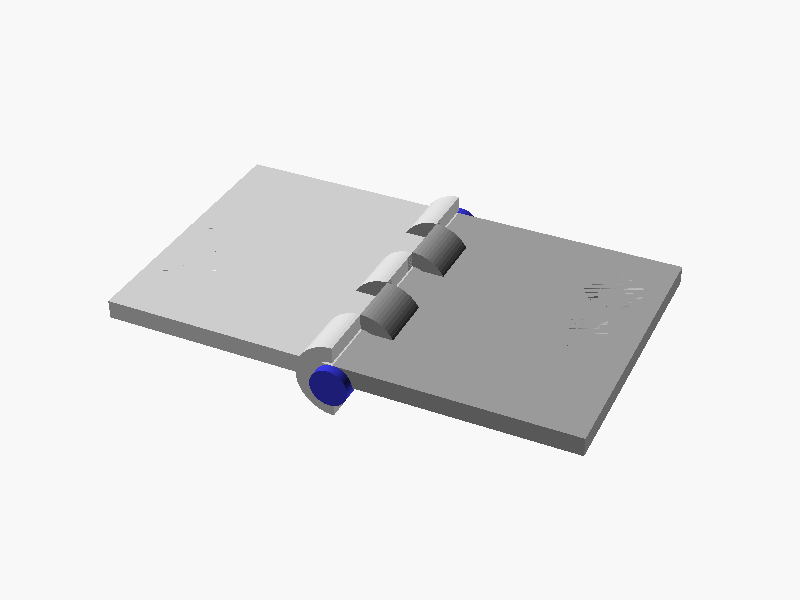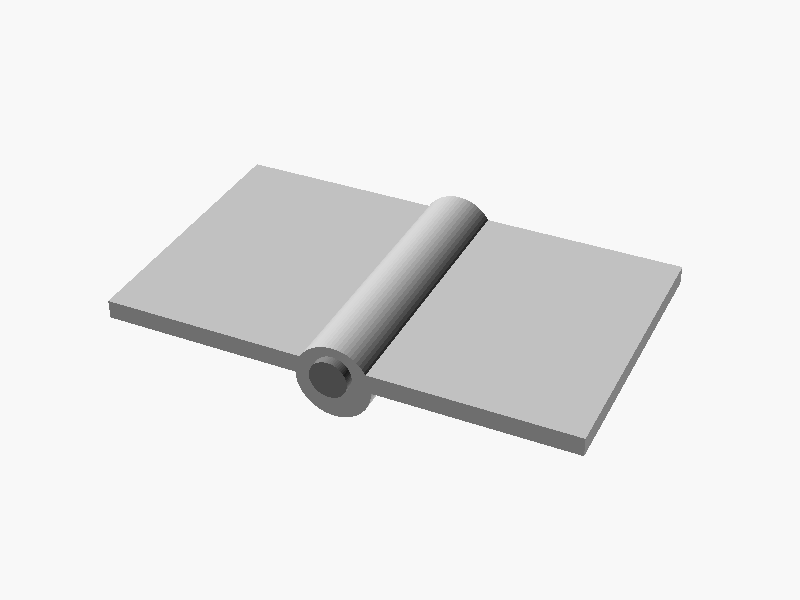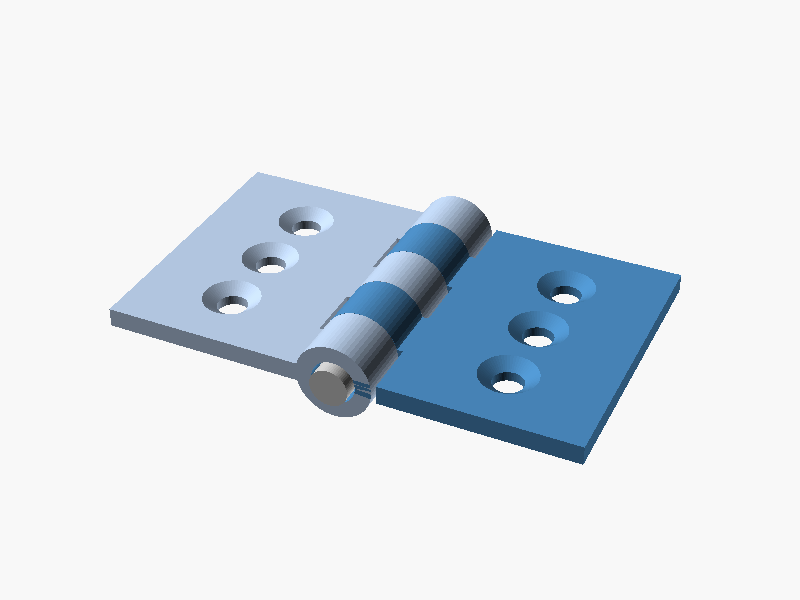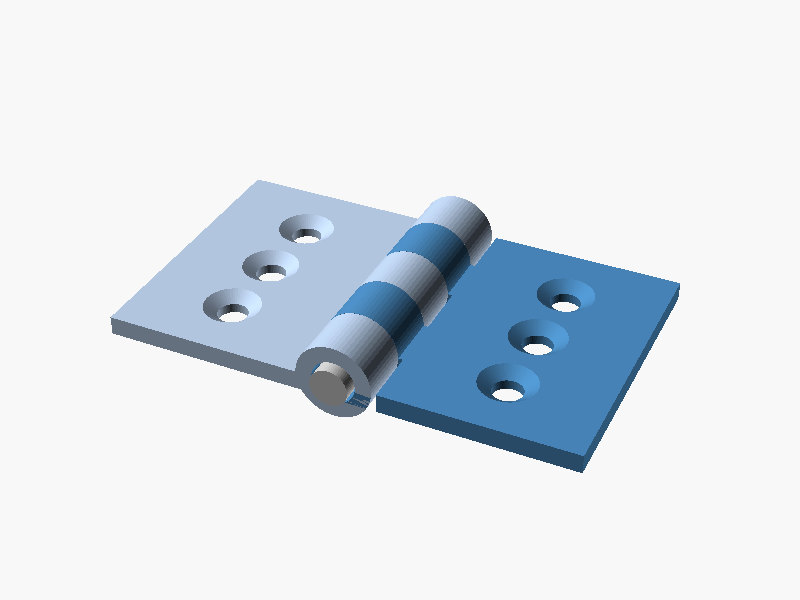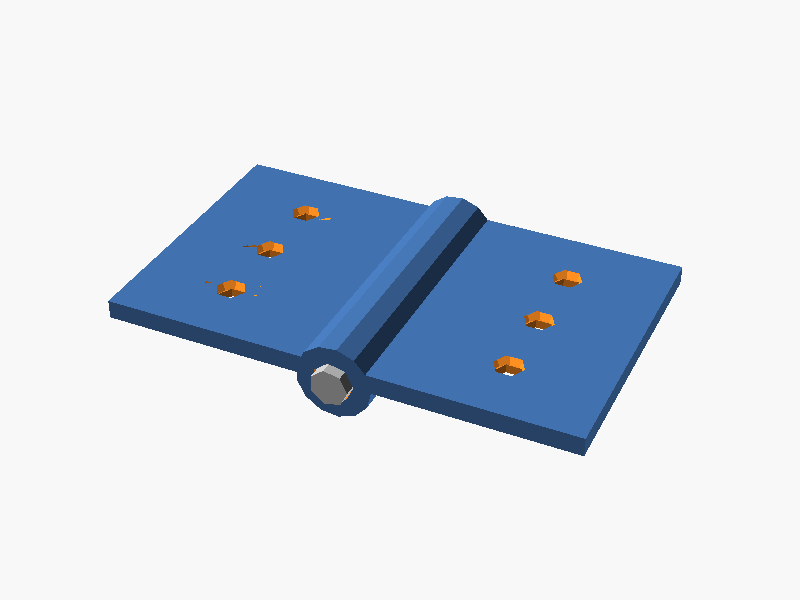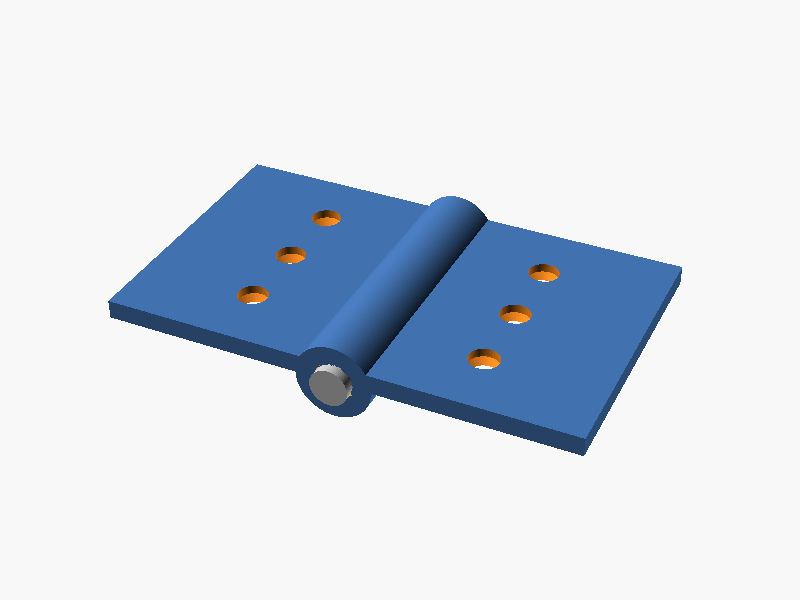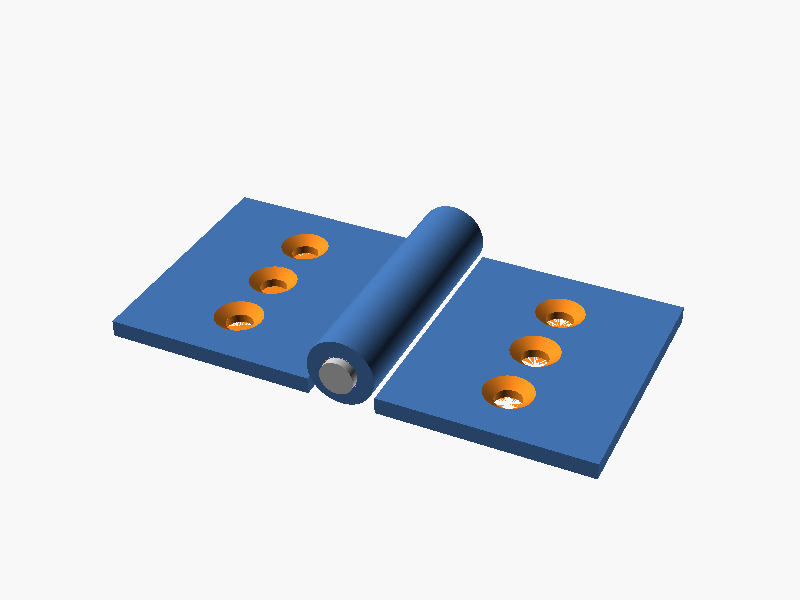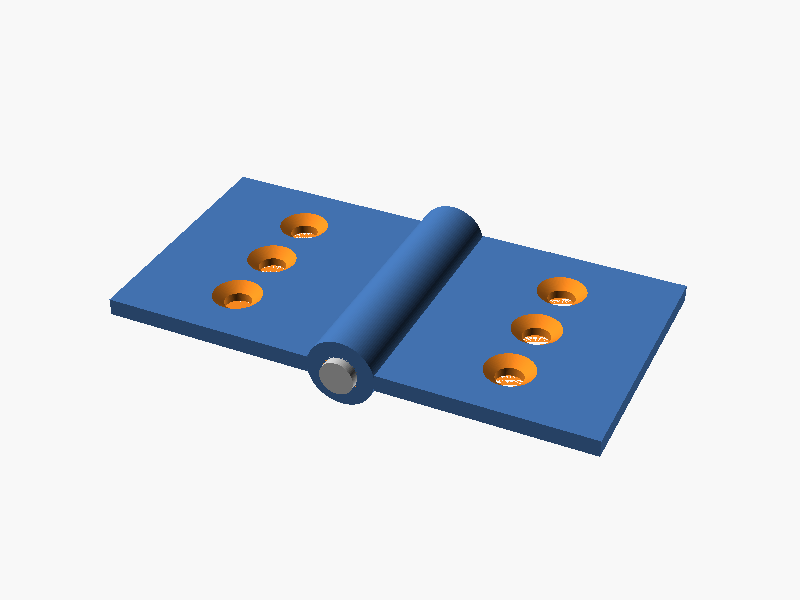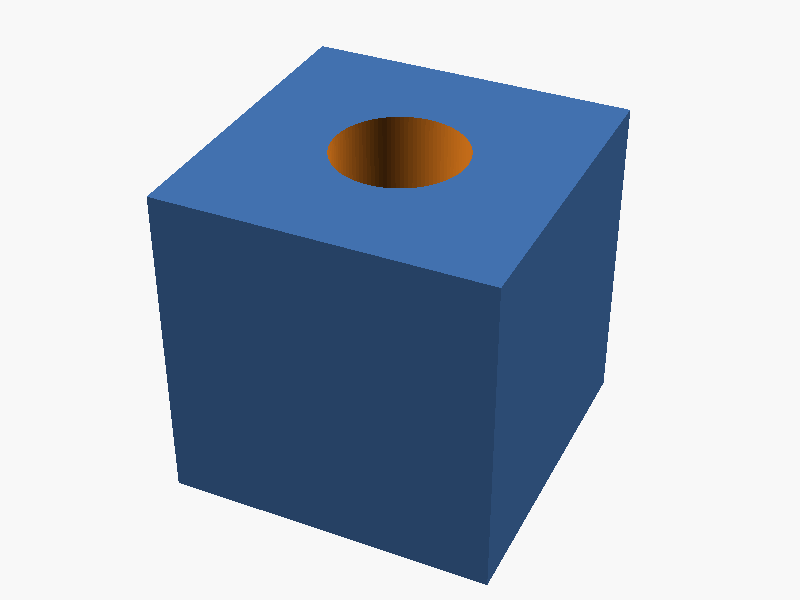
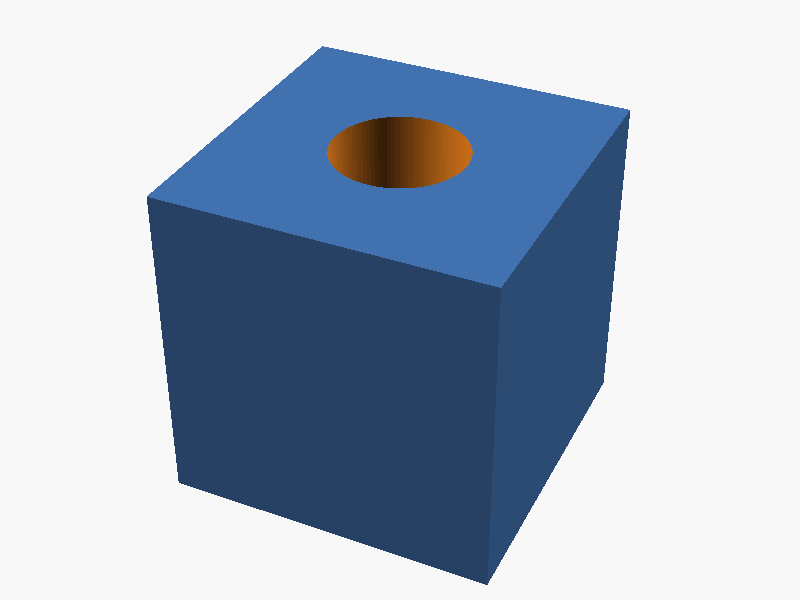
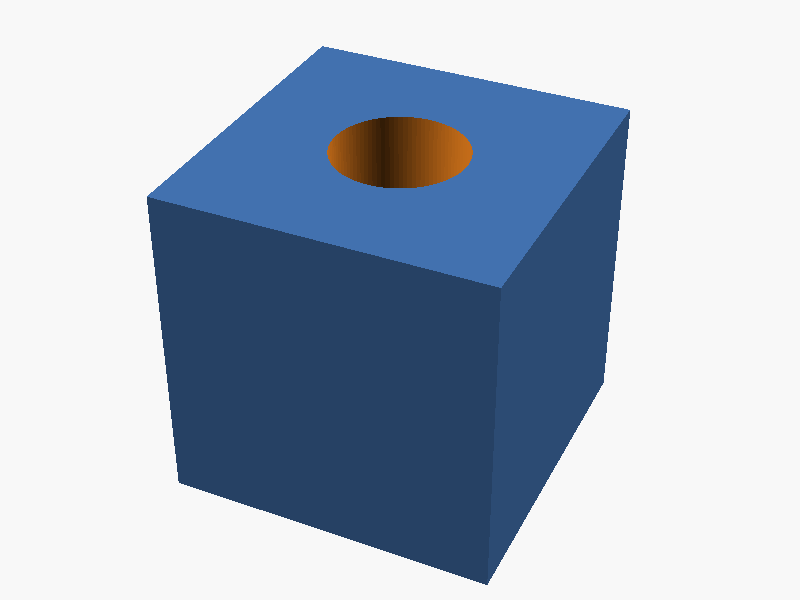
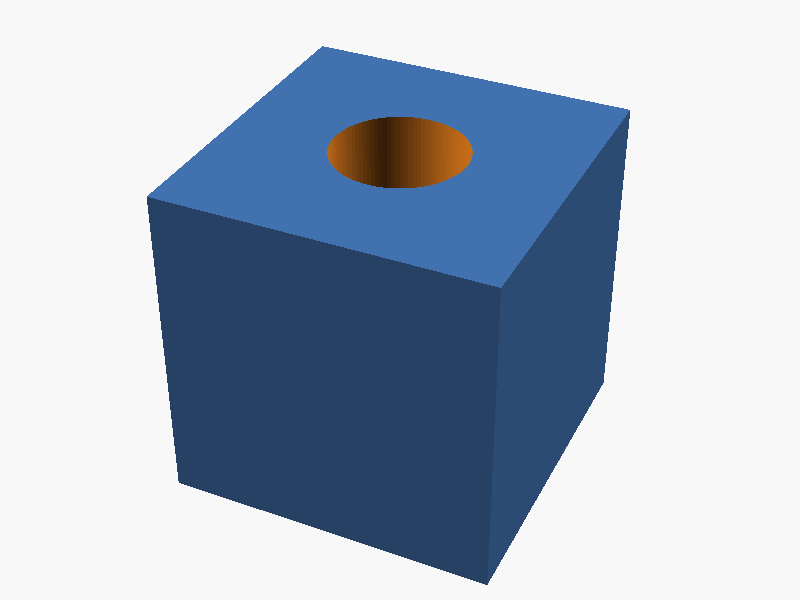
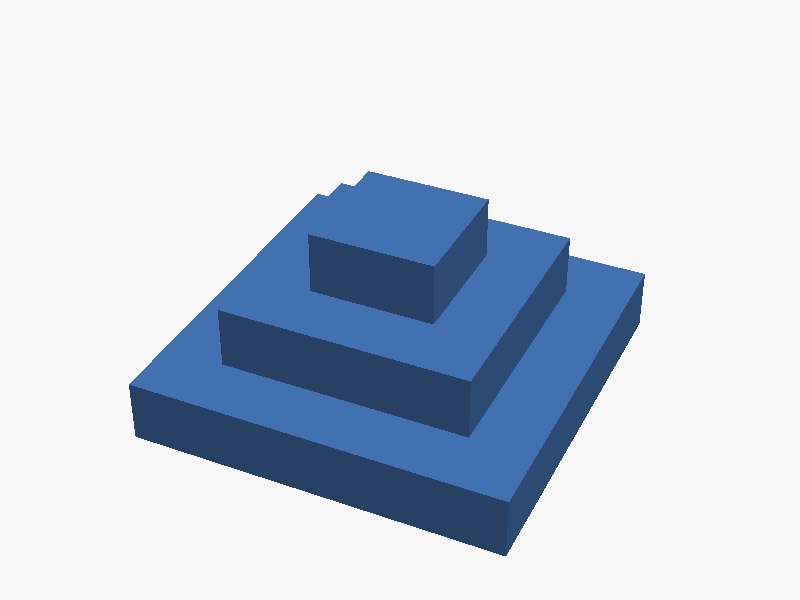
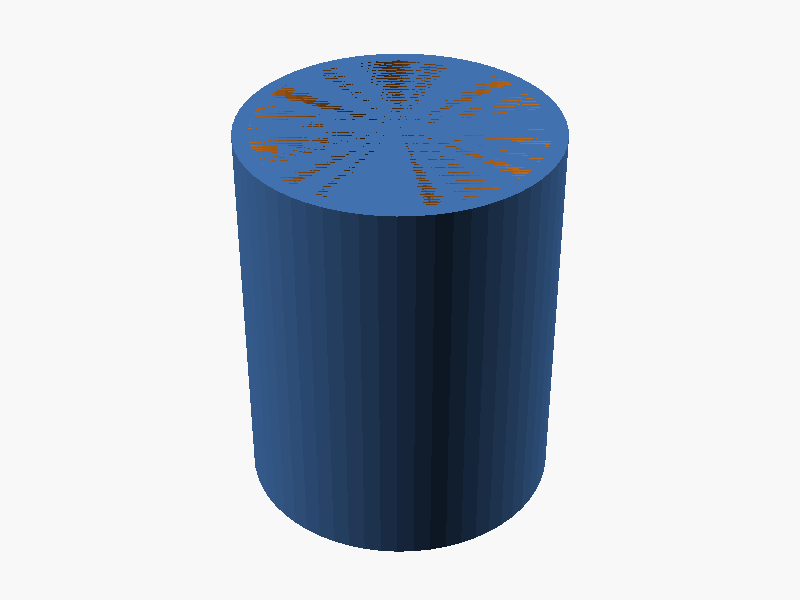
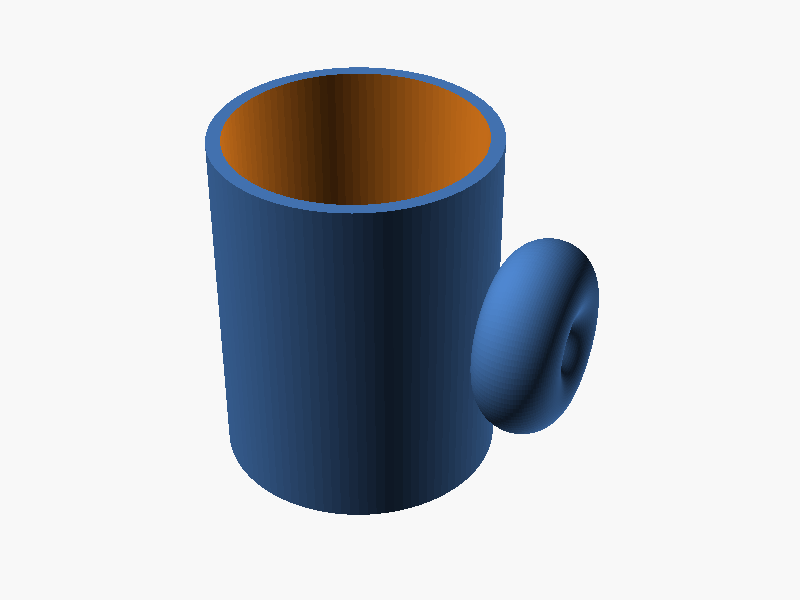
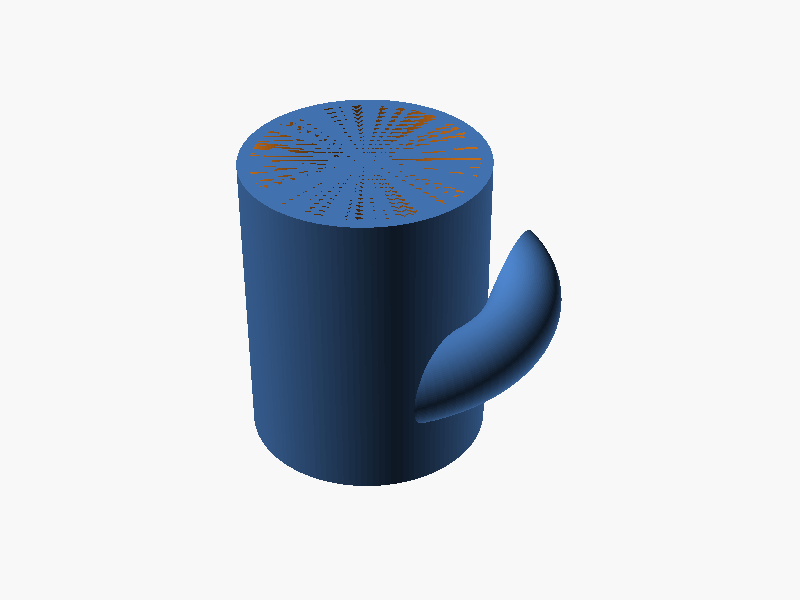
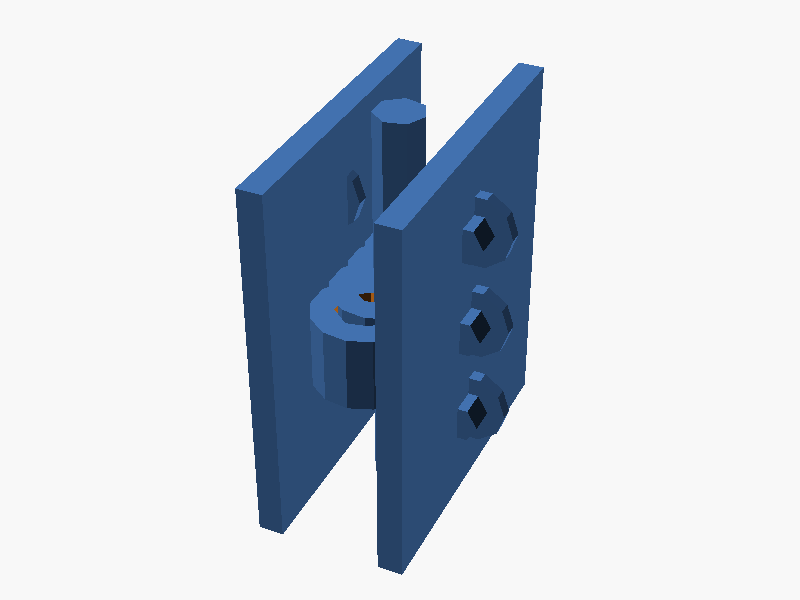
thinking 成功はレンダリングの完了を示します。形状の正しさは画像や 3D 表示で確認してください。
同じ項目内は「いずれかに一致」、異なる項目間は「すべてに一致」で絞り込みます。
条件を減らすか、フィルタを解除してもう一度お試しください。
thinking 
thinking 


thinking 
thinking 
thinking 


thinking 
thinking 
thinking 


effort 
effort 
effort 
effort 
effort 
effort 


thinking 
thinking 
thinking 
thinking 
thinking 
thinking 

thinking 



thinking thinking thinking thinking thinking thinking thinking thinking effort effort effort effort effort effort thinking thinking thinking thinking thinking thinking thinking 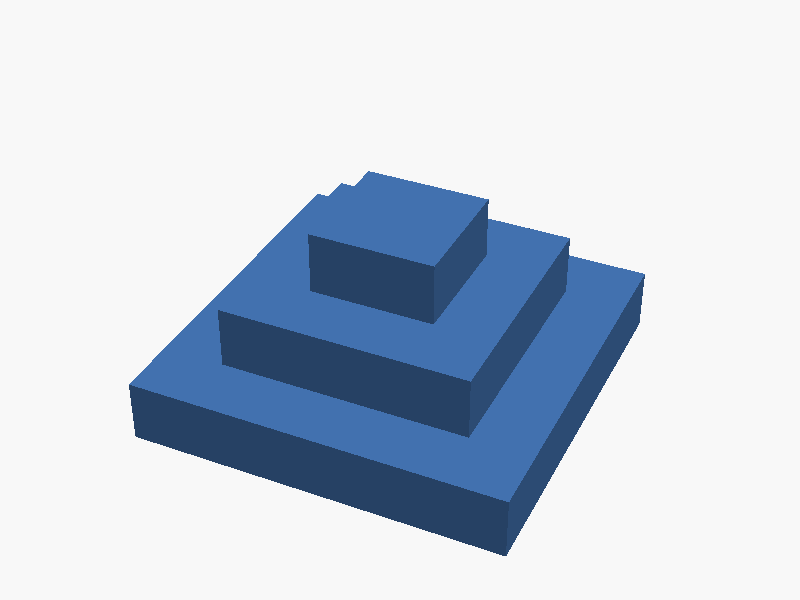
thinking 
thinking 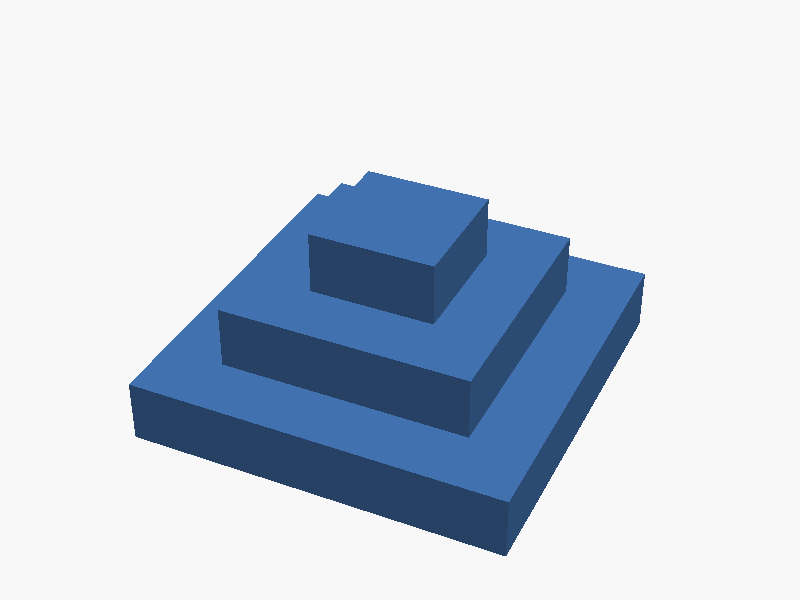


thinking 
thinking 
thinking 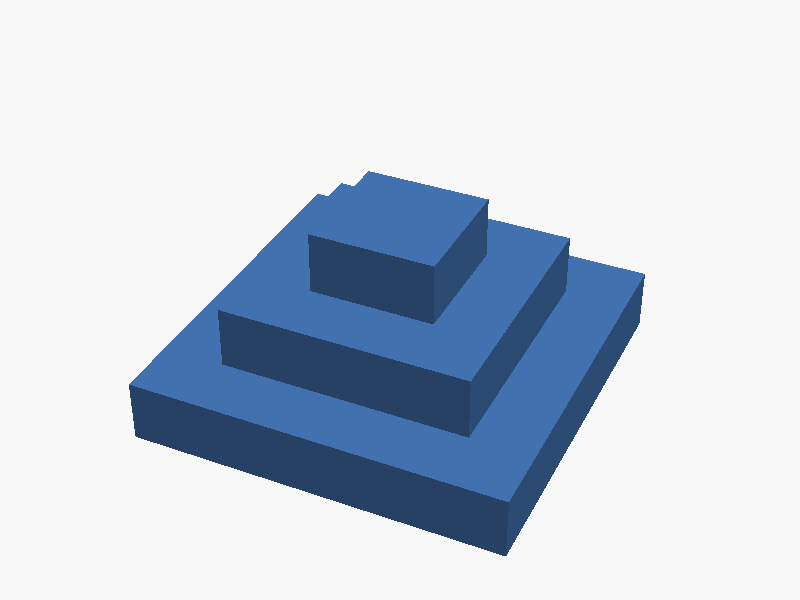


thinking 
thinking 
thinking 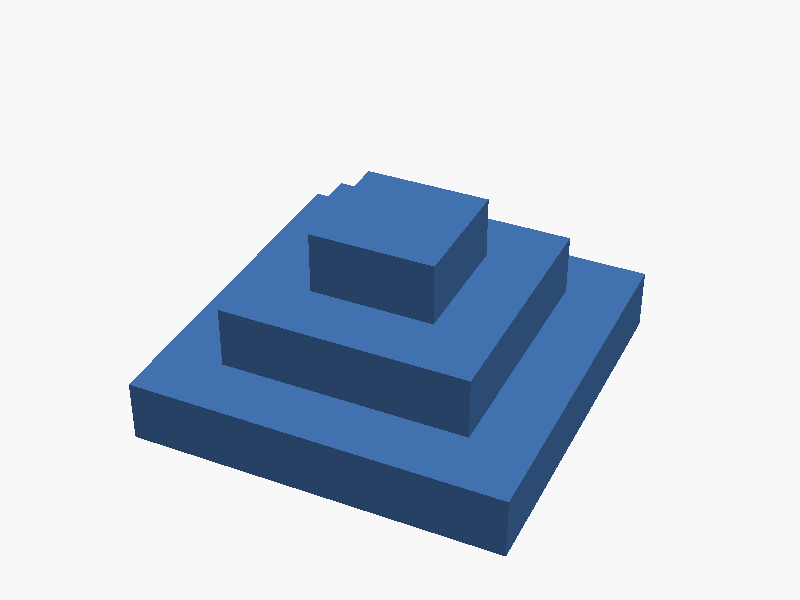
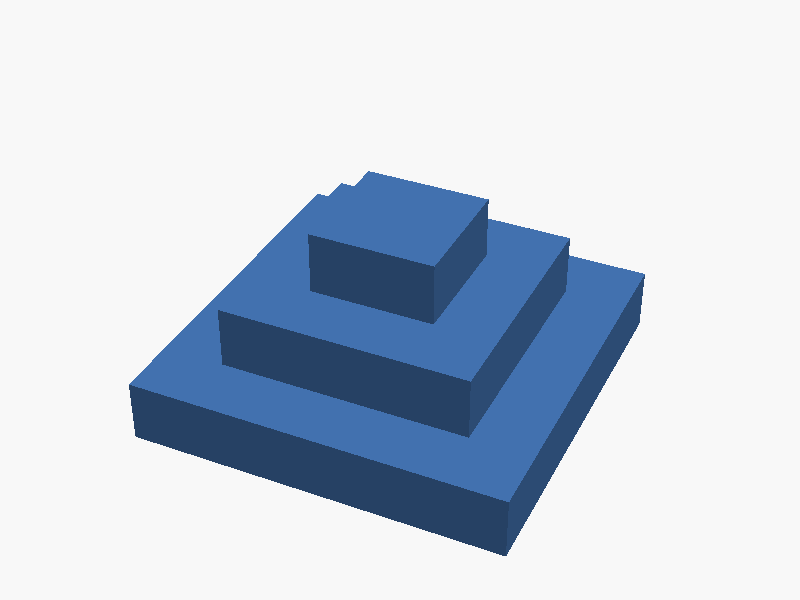
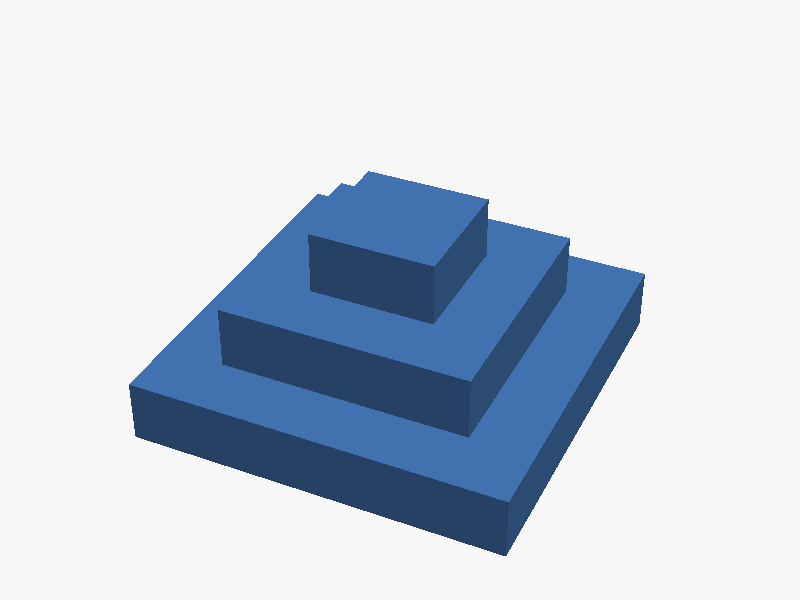
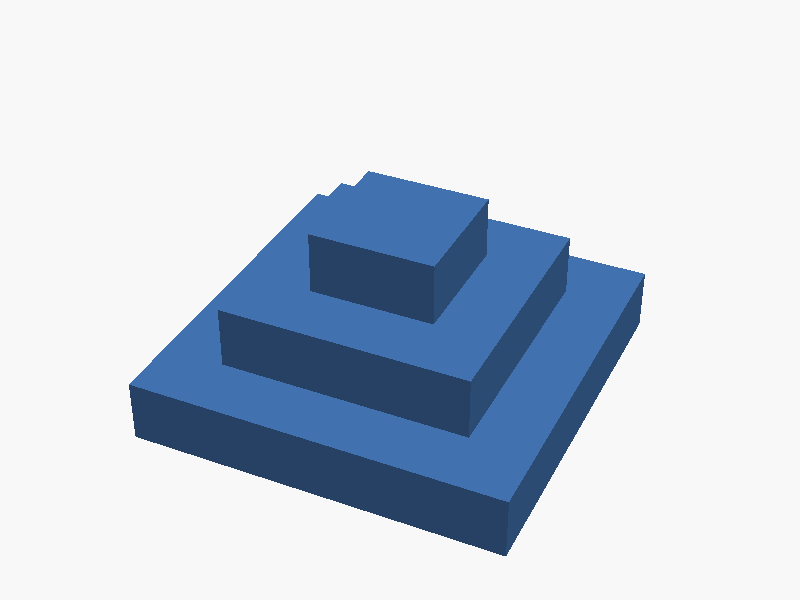


effort 
effort 
effort 
effort 
effort 
effort 



thinking thinking thinking thinking thinking thinking thinking thinking effort effort effort effort effort effort 
thinking 
thinking 


effort thinking 
thinking 
thinking 
thinking 
effort thinking 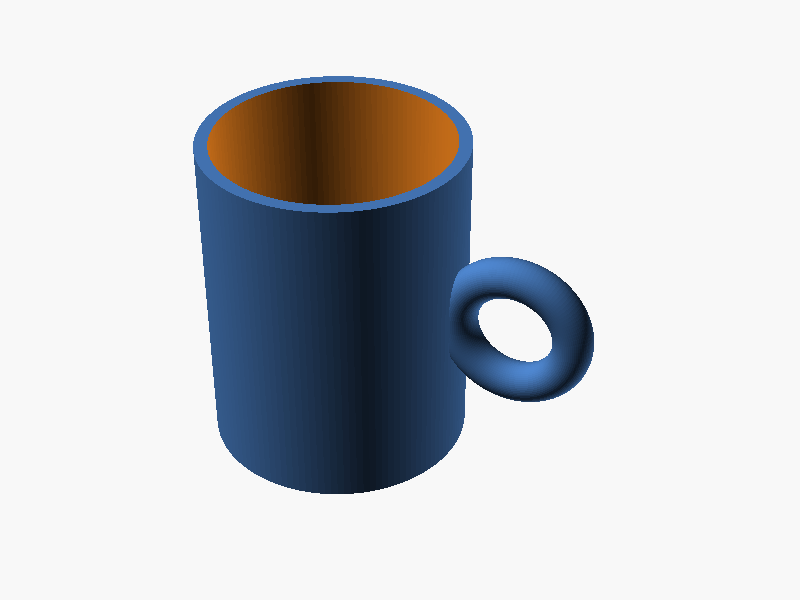
effort thinking 
thinking 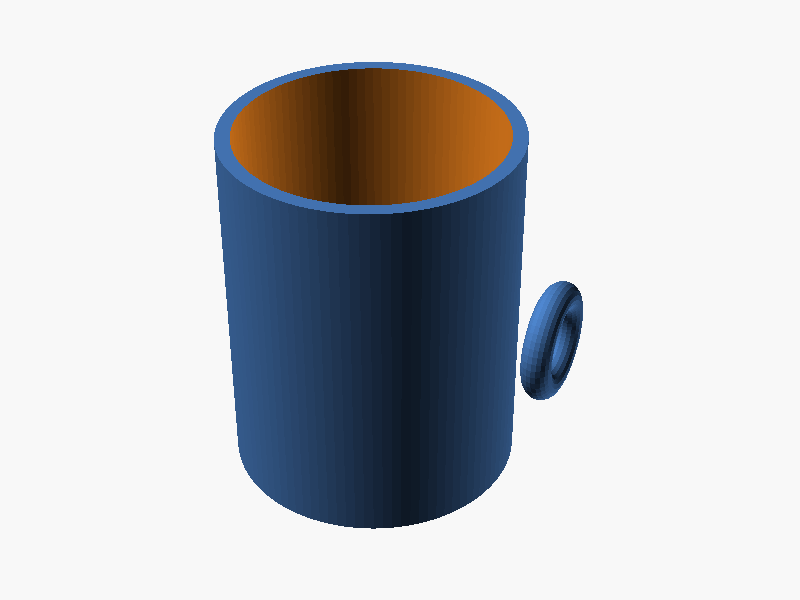
thinking 
thinking 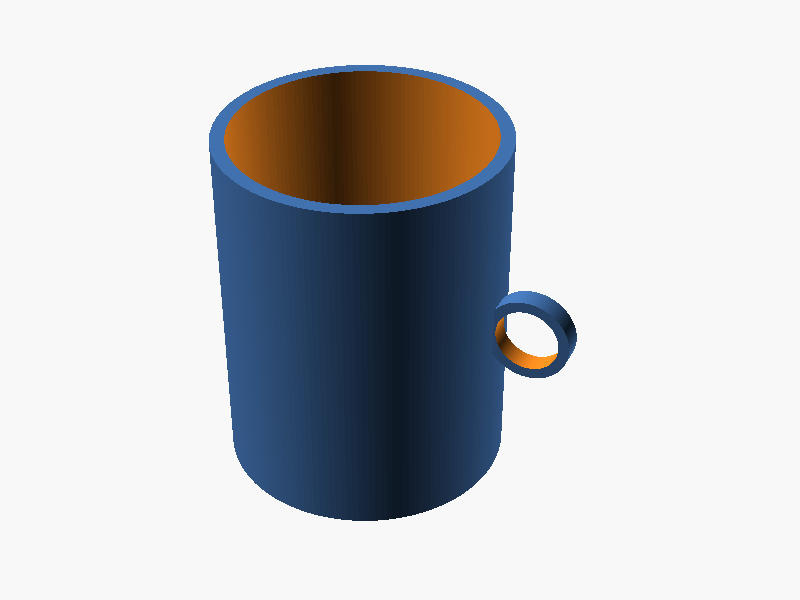
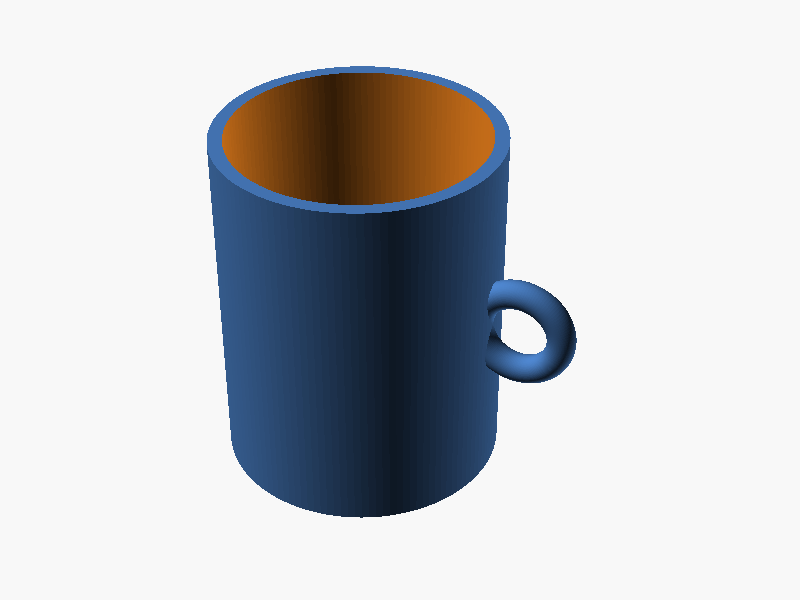
effort 


effort 

effort 
effort 
effort 
effort 
effort 
effort 


thinking 
thinking 
thinking 
thinking 
thinking 
thinking 
thinking 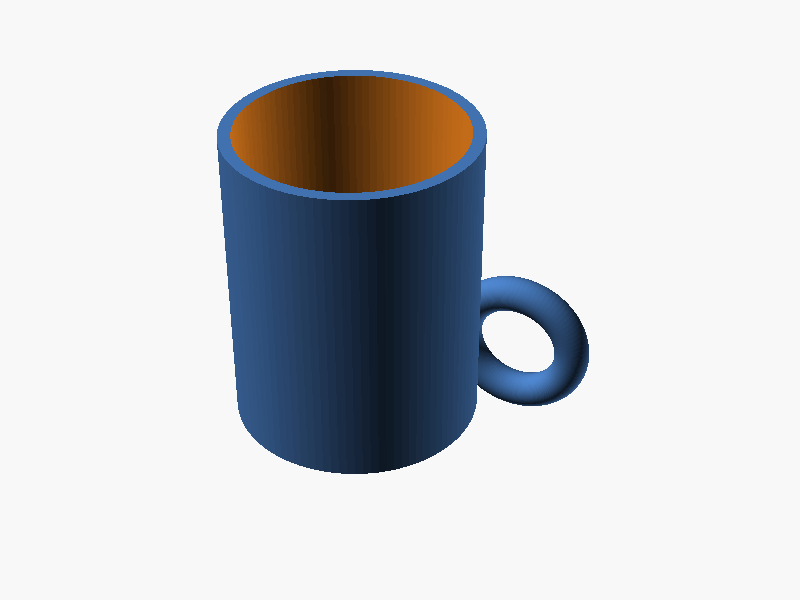


thinking thinking effort thinking thinking thinking thinking effort thinking effort thinking thinking thinking thinking effort effort effort effort effort effort effort effort thinking thinking thinking thinking thinking thinking thinking 
thinking 
thinking 


thinking 
thinking 
thinking 

thinking 
thinking 
thinking 



effort 
effort 
effort 
effort 
effort 
effort 


thinking 
thinking 
thinking 
thinking 
thinking 
thinking 

thinking 

thinking thinking thinking thinking thinking thinking thinking thinking effort effort effort effort effort effort thinking thinking thinking thinking thinking thinking thinking 
thinking 
effort thinking 


thinking 
thinking 
thinking 
effort thinking 

thinking 
thinking 
thinking 
thinking 
thinking 
thinking 
thinking 
thinking 
thinking 
thinking 


thinking effort thinking thinking thinking thinking effort thinking thinking thinking thinking thinking thinking thinking thinking thinking thinking thinking 
thinking 
thinking 


thinking 
thinking 
thinking 
effort thinking 
effort thinking 
thinking 
thinking 
thinking 


effort 
effort effort 
effort 
effort 
effort 
effort 
effort 
effort 


thinking 
thinking 
thinking 
thinking 
thinking 
thinking 
thinking 

thinking thinking thinking thinking thinking thinking effort thinking effort thinking thinking thinking thinking effort effort effort effort effort effort effort effort effort thinking thinking thinking thinking thinking thinking thinking thinking 
thinking 
effort thinking 


thinking 
thinking 
thinking 
effort thinking 

thinking 
thinking 
thinking 
effort 


effort 
effort 
effort 

effort 
effort 
effort 
effort 
effort 
effort effort 
thinking 
thinking 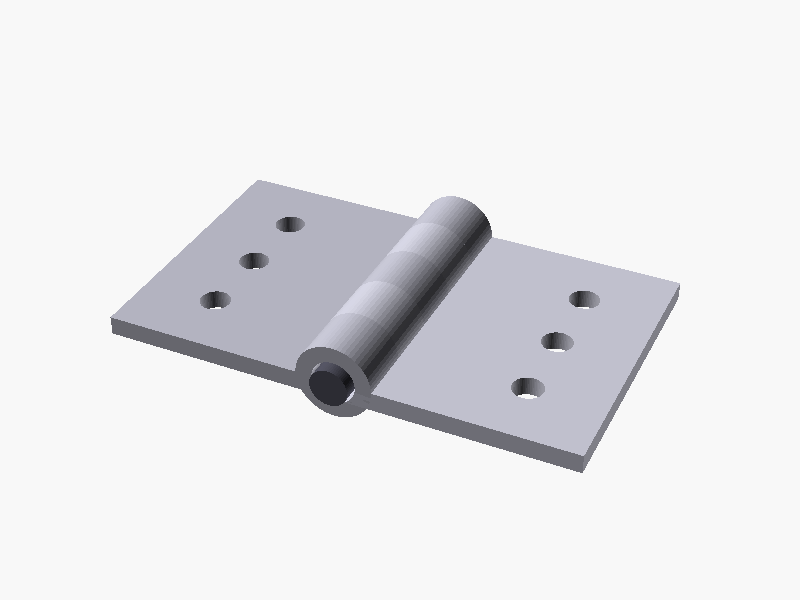
thinking 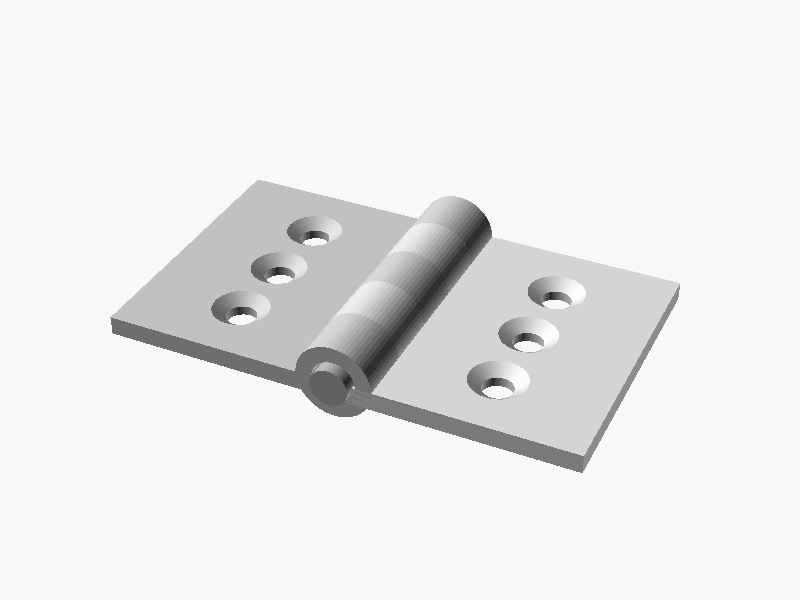
thinking 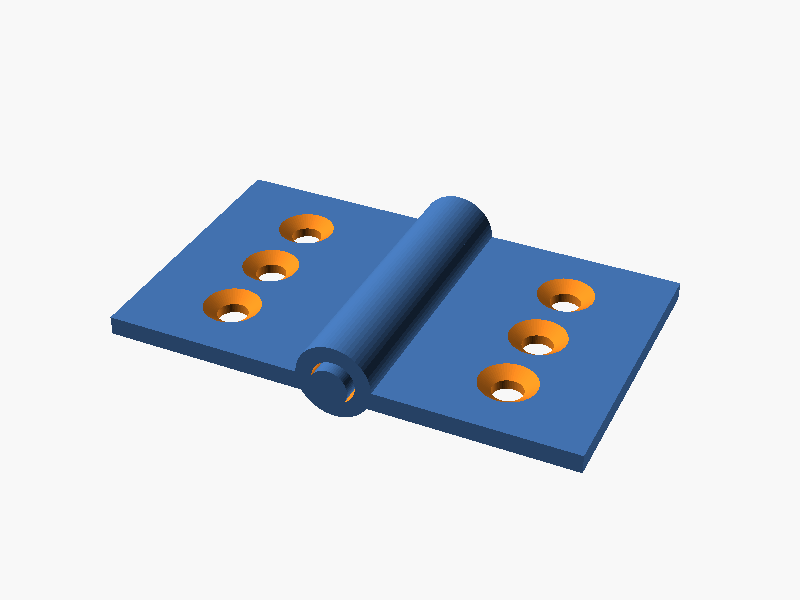
thinking 
thinking 

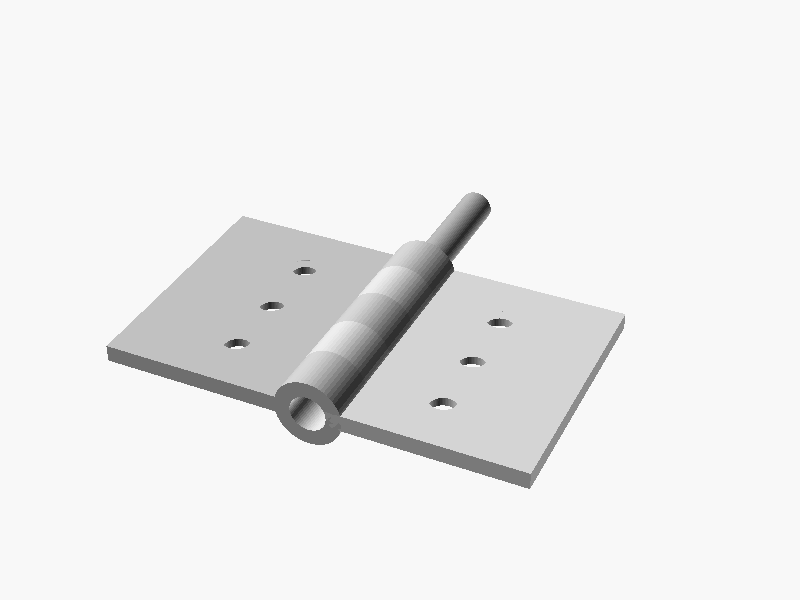
thinking 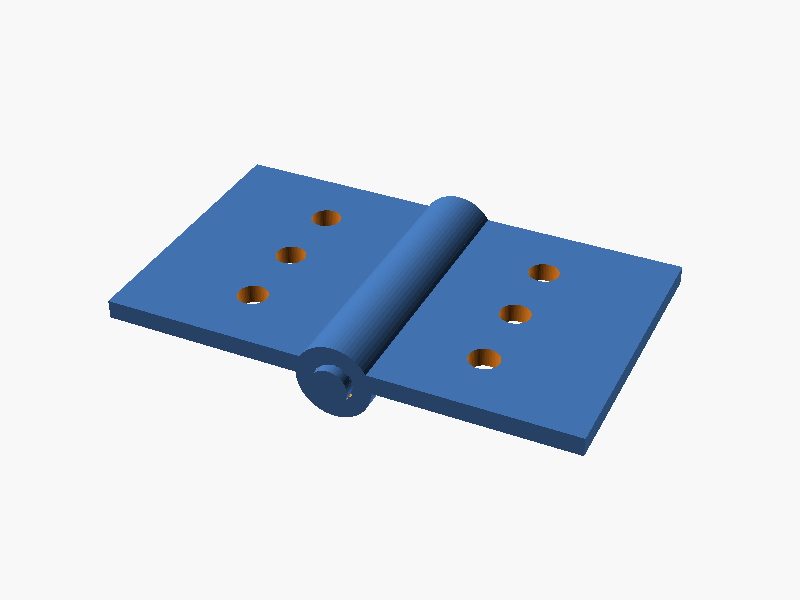
thinking effort thinking thinking thinking thinking effort thinking thinking thinking thinking effort effort effort effort effort effort effort effort effort effort effort thinking thinking thinking thinking thinking thinking thinking