pdf-page/gpt-5.6-sol / tier-4-gp2y0d413k
success tier 4
pdf-page (gpt 5.6 sol)
render
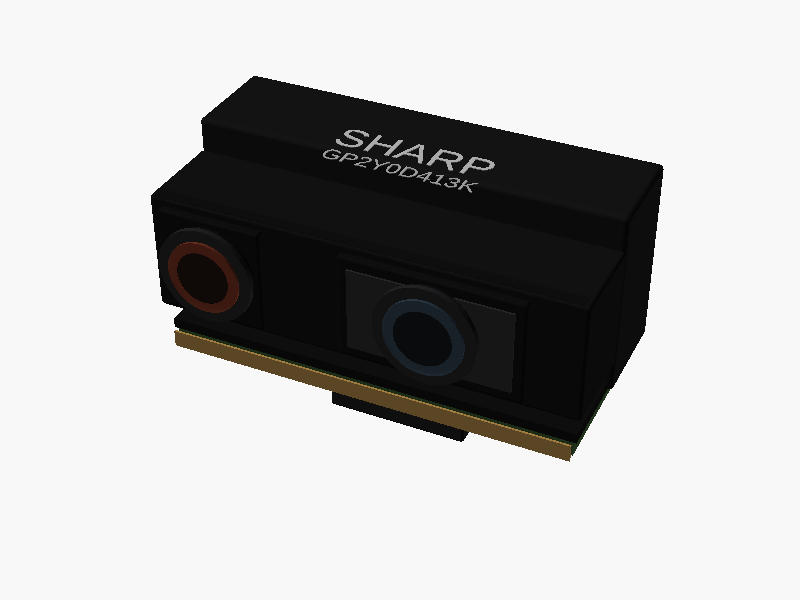
/*
  Sharp GP2Y0D413K0F 距離センサ外形モデル
  単位: mm

  座標系:
    X : 本体長手方向
    Y : 光軸方向(検出面が -Y)
    Z : 高さ方向(PWB/コネクタ側が -Z)

  原点:
    コネクタを除く本体外形の中心
*/

$fn = 48;

// データシート主要寸法
body_width  = 29.45;
body_depth  = 13.50;
body_height = 13.05;

front_depth = 6.30;
rear_depth  = 7.20;
front_height = 8.40;

connector_width  = 10.10;
connector_depth  = 6.20;
connector_height = 5.85;

pwb_thickness = 1.20;

// レンズ中心位置
emitter_x  = -body_width/2 + 4.50;
detector_x = -body_width/2 + 19.70;


// 寸法を維持した丸み付き直方体
module rounded_box(size, radius=0.3, center=true)
{
    sx = size[0];
    sy = size[1];
    sz = size[2];

    translate(center ? [0,0,0] : [sx/2,sy/2,sz/2])
        minkowski() {
            cube([
                max(0.01, sx-2*radius),
                max(0.01, sy-2*radius),
                max(0.01, sz-2*radius)
            ], center=true);

            sphere(r=radius, $fn=20);
        }
}


// Y軸に沿った円筒
module y_cylinder(h, d)
{
    rotate([90,0,0])
        cylinder(h=h, d=d, center=false);
}


// 前面レンズ
module optical_lens(x, z, outer_d, clear_d, glass_color)
{
    // レンズ周囲のケース
    color([0.055,0.055,0.060])
        translate([x, -body_depth/2-0.35, z])
            y_cylinder(0.75, outer_d);

    // 前面リング
    color([0.12,0.12,0.13])
        translate([x, -body_depth/2-1.05, z])
            rotate([90,0,0])
                difference() {
                    cylinder(h=0.38, d=outer_d+0.35);
                    translate([0,0,-0.05])
                        cylinder(h=0.48, d=clear_d);
                }

    // 透明レンズ
    color(glass_color)
        translate([x, -body_depth/2-1.40, z])
            y_cylinder(0.22, clear_d);

    // 内部の暗色部
    color([0.03,0.035,0.04,0.80])
        translate([x, -body_depth/2-1.58, z])
            y_cylinder(0.08, clear_d*0.72);
}


// 3極コネクタ
module connector()
{
    connector_z =
        -body_height/2
        - pwb_thickness
        - connector_height/2
        + 0.15;

    connector_y = 1.55;

    // コネクタ樹脂ハウジング
    color([0.10,0.10,0.105])
        difference() {
            translate([0, connector_y, connector_z])
                rounded_box(
                    [connector_width, connector_depth, connector_height],
                    0.25
                );

            // 後方に開いた差し込み口
            translate([
                0,
                connector_y + connector_depth/2 - 1.65,
                connector_z - 0.15
            ])
                cube([
                    connector_width-1.55,
                    3.40,
                    connector_height-1.55
                ], center=true);
        }

    // コネクタ上面の段差
    color([0.075,0.075,0.08])
        translate([
            0,
            connector_y-connector_depth/2+0.55,
            connector_z+connector_height/2-0.55
        ])
            cube([
                connector_width-1.25,
                1.10,
                1.10
            ], center=true);

    // 端子
    for (x = [-2.0, 0, 2.0])
        color([0.78,0.62,0.24])
            translate([
                x,
                connector_y+1.30,
                connector_z-0.15
            ])
                cube([0.48, 4.25, 0.48], center=true);
}


// 本体下面のPWB
module pwb()
{
    color([0.20,0.30,0.16])
        translate([
            0,
            0.25,
            -body_height/2-pwb_thickness/2
        ])
            cube([
                body_width-1.20,
                body_depth-1.15,
                pwb_thickness
            ], center=true);

    // PWB端面
    color([0.62,0.48,0.25])
        translate([
            0,
            -body_depth/2+0.30,
            -body_height/2-pwb_thickness/2
        ])
            cube([
                body_width-1.20,
                0.16,
                pwb_thickness
            ], center=true);
}


// センサ本体
module sensor_body()
{
    front_y0 = -body_depth/2;
    front_y1 = front_y0 + front_depth;

    // 後部レンズケース
    color([0.075,0.075,0.08])
        translate([
            0,
            (front_y1 + body_depth/2)/2,
            0
        ])
            rounded_box([
                body_width,
                body_depth-front_depth,
                body_height
            ], 0.35);

    // 前部の細い光学ケース
    color([0.065,0.065,0.07])
        translate([
            0,
            (front_y0+front_y1)/2,
            0
        ])
            rounded_box([
                body_width,
                front_depth+0.25,
                front_height
            ], 0.25);

    // 前面上下補強リブ
    color([0.055,0.055,0.06]) {
        translate([
            0,
            front_y0+0.42,
            front_height/2-0.45
        ])
            cube([body_width-0.7, 0.85, 0.90], center=true);

        translate([
            0,
            front_y0+0.42,
            -front_height/2+0.45
        ])
            cube([body_width-0.7, 0.85, 0.90], center=true);
    }

    // 発光側角形ベゼル
    color([0.055,0.055,0.06])
        translate([
            emitter_x,
            front_y0-0.31,
            0
        ])
            rounded_box([7.25, 0.68, 7.25], 0.18);

    // 受光側角形ベゼル
    color([0.055,0.055,0.06])
        translate([
            detector_x,
            front_y0-0.31,
            0
        ])
            rounded_box([12.35, 0.68, 7.25], 0.18);

    // ベゼル内側パネル
    color([0.15,0.15,0.155])
        translate([
            detector_x,
            front_y0-0.70,
            0
        ])
            cube([10.95, 0.18, 5.75], center=true);

    // 発光レンズ
    optical_lens(
        emitter_x,
        0,
        6.35,
        5.10,
        [0.42,0.18,0.12,0.78]
    );

    // 受光レンズ
    optical_lens(
        detector_x,
        0,
        6.55,
        5.35,
        [0.18,0.24,0.29,0.72]
    );

    // 本体下面の段差
    color([0.055,0.055,0.06])
        translate([
            0,
            0.25,
            -body_height/2+0.35
        ])
            cube([
                body_width-0.75,
                body_depth-0.80,
                0.70
            ], center=true);
}


// 上面刻印
module top_marking()
{
    color([0.67,0.67,0.67])
        translate([
            0,
            1.30,
            body_height/2+0.015
        ])
            linear_extrude(height=0.055)
                text(
                    "SHARP",
                    size=2.25,
                    halign="center",
                    valign="center",
                    style="bold"
                );

    color([0.60,0.60,0.60])
        translate([
            0,
            -1.10,
            body_height/2+0.015
        ])
            linear_extrude(height=0.055)
                text(
                    "GP2Y0D413K",
                    size=1.20,
                    halign="center",
                    valign="center"
                );
}


// 完成モデル
module GP2Y0D413K0F()
{
    sensor_body();
    pwb();
    connector();
    top_marking();
}

GP2Y0D413K0F(); パラメータ (10) —
スライダを動かすと openscad-wasm で再レンダリング
prompt
添付画像は Sharp 製距離センサ GP2Y0D413K0F のデータシートのページです。
OpenSCAD でモデリングしてください。

座標系: 単位 mm、本体の中心を原点とし、取付面(PWB / コネクタ側)を -Z に向ける。

完成したコード全体を ```openscad ... ``` のフェンスで囲んで出力してください。