pdf-page/claude-fable-5 / tier-4-gp2y0d413k
success tier 4
pdf-page (claude fable 5)
render
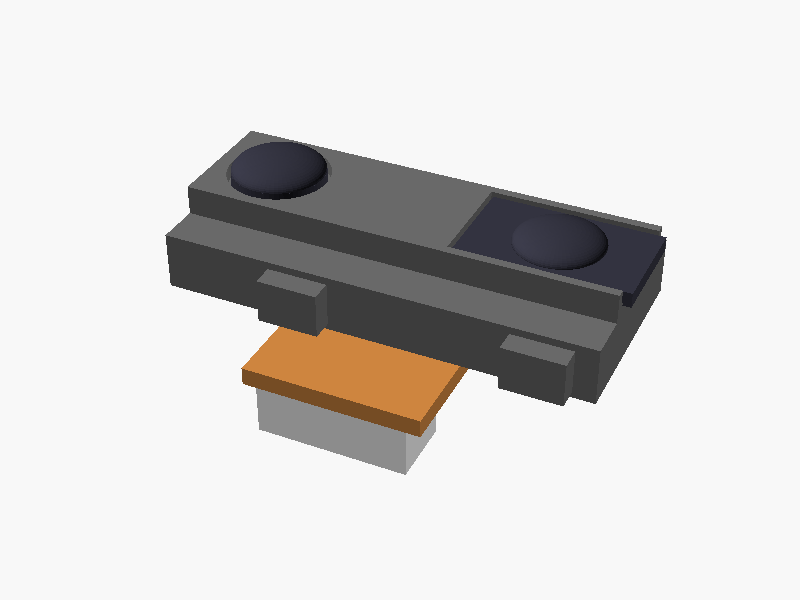
//------------------------------------------------------------
// Sharp GP2Y0D413K0F 距離センサ 外形モデル
// 単位: mm
// 座標系: 本体(ケース)中心を原点
//          +Z = レンズ面(検出方向), -Z = PWB / コネクタ(取付面)
//------------------------------------------------------------
$fn = 64;

//---------------- 主要寸法 (データシートより) ----------------
body_w      = 29.45;   // 本体幅
body_h      = 13.05;   // 本体(ケース)高さ
depth_total = 7.1;     // 全奥行 (レンズ面〜PWB背面)

pwb_t       = 1.2;     // PWB 厚
lens_step   = 2.0;     // レンズケースの張り出し
case_d      = depth_total - pwb_t - lens_step; // ケース本体奥行 = 3.9

// Z 座標 (奥行を原点中心に配置)
z_back       = -depth_total/2;          // -3.55 : PWB 背面
z_pwb_front  =  z_back + pwb_t;         // ケース背面
z_case_front =  z_pwb_front + case_d;   // レンズケース段差位置
z_front      =  depth_total/2;          // +3.55 : レンズ面

// レンズ位置
lens_pitch = 19.7;                 // 発光-受光 レンズ中心間距離
emit_x     = 4.5 - body_w/2;       // 発光レンズ中心 (左端から4.5)
det_x      = emit_x + lens_pitch;  // 受光レンズ中心
lens_y     = 7.2 - body_h/2;       // レンズ中心高さ (底面から7.2)
hood_h     = 8.4;                  // レンズケース部高さ

// PWB / コネクタ
total_h   = 18.9;                  // ケース上端〜コネクタ下端
pwb_below = total_h - body_h;      // ケース下へ突き出す量 = 5.85
pwb_w     = 12.0;
conn_w    = 10.1;
conn_h    = 4.5;
conn_d    = 3.3;                   // PWB 背面からの突出

// 取付脚 (下面ボス)
foot_w = 4.15;
foot_h = 1.5;
foot_d = 3.0;

//---------------- モジュール ----------------
module case_body() {
    difference() {
        union() {
            // ケース本体
            translate([-body_w/2, -body_h/2, z_pwb_front])
                cube([body_w, body_h, case_d]);
            // レンズケース (前方へ 2mm 張り出し)
            translate([-body_w/2, lens_y - hood_h/2, z_pwb_front])
                cube([body_w, hood_h, case_d + lens_step]);
        }
        // 発光側レンズ開口 (丸)
        translate([emit_x, lens_y, z_front - 1])
            cylinder(d = 7.0, h = 2);
        // 受光側レンズ窓 (角穴)
        translate([det_x - 6.0, lens_y - 3.6, z_front - 1])
            cube([12.0, 7.2, 2]);
    }
}

module lenses() {
    // 発光レンズ (凸)
    translate([emit_x, lens_y, z_front - 1.2])
        cylinder(d = 6.4, h = 1.4);
    translate([emit_x, lens_y, z_front + 0.2])
        scale([1, 1, 0.35]) sphere(d = 6.4);
    // 受光レンズ (角窓内の凸レンズ)
    translate([det_x - 5.8, lens_y - 3.4, z_front - 1.2])
        cube([11.6, 6.8, 1.0]);
    translate([det_x, lens_y, z_front - 0.2])
        scale([1, 1, 0.35]) sphere(d = 6.0);
}

module pwb() {
    // ケース背面に取り付き、下方へ突き出す
    translate([-pwb_w/2, -body_h/2 - pwb_below, z_back])
        cube([pwb_w, body_h/2 + pwb_below + 4, pwb_t]);
}

module connector() {
    // PWB 下部背面 (-Z 側) に実装、嵌合方向 -Z
    translate([-conn_w/2, -body_h/2 - pwb_below, z_back - conn_d])
        cube([conn_w, conn_h, conn_d]);
    // 3ピン
    for (i = [-1, 0, 1])
        translate([i * 2.5 - 0.25,
                   -body_h/2 - pwb_below + conn_h/2 - 0.25,
                   z_back - conn_d - 0.8])
            cube([0.5, 0.5, 0.8 + conn_d]);
}

module feet() {
    // 底面の取付ボス x2 (下面図の位置関係を近似)
    foot_x = [7.5 - body_w/2 + foot_w/2,          // 左脚
              7.5 + foot_w - body_w/2 + 16.3 - foot_w/2]; // 右脚
    for (x = foot_x)
        translate([x - foot_w/2, -body_h/2 - foot_h, z_pwb_front + 0.4])
            cube([foot_w, foot_h, foot_d]);
}

//---------------- 組み立て ----------------
module gp2y0d413k0f() {
    color("dimgray")   case_body();
    color("dimgray")   feet();
    color([0.2, 0.2, 0.25, 1]) lenses();
    color("peru")      pwb();
    color("whitesmoke") connector();
}

gp2y0d413k0f(); パラメータ (15) —
スライダを動かすと openscad-wasm で再レンダリング
prompt
添付画像は Sharp 製距離センサ GP2Y0D413K0F のデータシートのページです。
OpenSCAD でモデリングしてください。

座標系: 単位 mm、本体の中心を原点とし、取付面(PWB / コネクタ側)を -Z に向ける。

完成したコード全体を ```openscad ... ``` のフェンスで囲んで出力してください。