pdf-page/gemini-3.1-pro / tier-4-gp2y0d413k
success tier 4
pdf-page (gemini 3.1 pro)
render
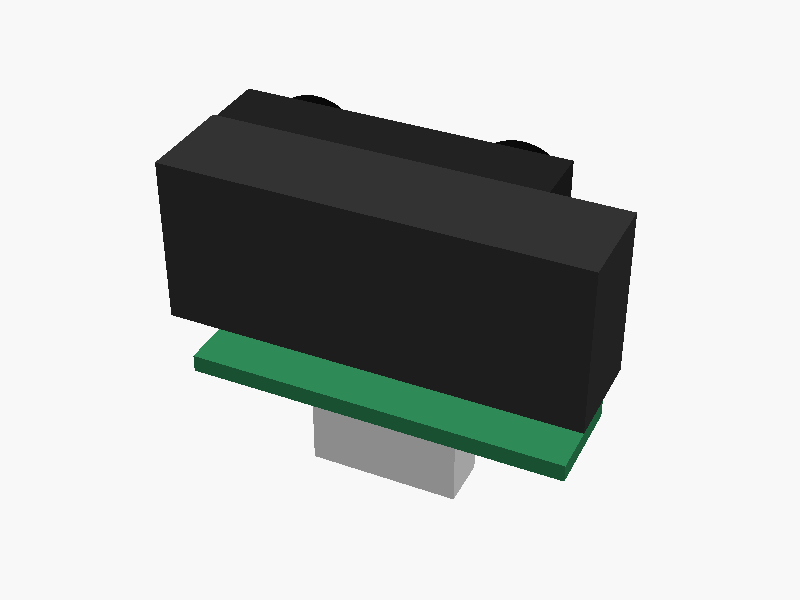
loading STL…
// Sharp GP2Y0D413K0F Distance Sensor
// Unit: mm
// Coordinate System:
// - Origin: Center of main body
// - Z-axis: Mounting surface (PWB / Connector side) faces -Z
// - Y-axis: Lenses face +Y (Front)
// - X-axis: Width direction

$fn = 64;

module gp2y0d413k0f() {
    // --- Dimensions ---

    // 1. Main Body
    mb_w = 29.45; // Width
    mb_d = 7.1;   // Depth
    mb_h = 13.05 - 1.2; // Height to PWB top surface (11.85)

    // 3. Lenses
    lens_dia = 7.2;
    lens_d = 2.0;
    // X positions relative to the left edge of the main body
    lens_left_x = -mb_w/2 + 4.5;
    lens_right_x = -mb_w/2 + 19.7;

    // 2. Lens Case
    lc_w = 23.6; // Width to enclose both lenses
    lc_d = 6.3 - lens_d; // Front extension (4.3)
    lc_h = 8.4;
    lc_x_offset = (lens_left_x + lens_right_x) / 2;

    // 4. PWB (Printed Wiring Board)
    pwb_th = 1.2;
    pwb_indent_left = 3.75; // Indent from left edge
    pwb_w = mb_w - pwb_indent_left;
    pwb_x_offset = -mb_w/2 + pwb_indent_left + pwb_w/2;
    pwb_back_extension = 3.3; // Extension beyond main body back
    pwb_d = (mb_d/2) + pwb_back_extension; // Depth (6.85)
    pwb_y_offset = -pwb_d/2; // Front edge aligns with main body center (Y=0)

    // 5. Connector
    conn_w = 10.1;
    conn_h = 18.9 - 13.05; // Extension below PWB (5.85)
    conn_d = 3.5; // Assumed depth
    conn_x_offset = pwb_x_offset; // Centered on PWB
    conn_y_offset = pwb_y_offset; // Centered on PWB depth


    // --- Assembly ---

    // Main Body
    color("#333333")
    cube([mb_w, mb_d, mb_h], center=true);

    // Lens Case
    color("#222222")
    translate([lc_x_offset, mb_d/2 + lc_d/2, mb_h/2 - lc_h/2])
    cube([lc_w, lc_d, lc_h], center=true);

    // Lenses
    color("#0a0a0a") {
        // Emitter (Left)
        translate([lens_left_x, mb_d/2 + lc_d, mb_h/2 - lc_h/2])
        rotate([-90, 0, 0])
        cylinder(h=lens_d, d=lens_dia);

        // Detector (Right)
        translate([lens_right_x, mb_d/2 + lc_d, mb_h/2 - lc_h/2])
        rotate([-90, 0, 0])
        cylinder(h=lens_d, d=lens_dia);
    }

    // PWB
    color("#2E8B57") // SeaGreen
    translate([pwb_x_offset, pwb_y_offset, -mb_h/2 - pwb_th/2])
    cube([pwb_w, pwb_d, pwb_th], center=true);

    // Connector
    color("#F5F5F5") // WhiteSmoke
    translate([conn_x_offset, conn_y_offset, -mb_h/2 - pwb_th - conn_h/2])
    cube([conn_w, conn_d, conn_h], center=true);
}

// Render the sensor
gp2y0d413k0f();prompt
添付画像は Sharp 製距離センサ GP2Y0D413K0F のデータシートのページです。
OpenSCAD でモデリングしてください。

座標系: 単位 mm、本体の中心を原点とし、取付面(PWB / コネクタ側)を -Z に向ける。

完成したコード全体を ```openscad ... ``` のフェンスで囲んで出力してください。