pdf-page/qwen3.8-27b / tier-4-gp2y0d413k
success tier 4
pdf-page (qwen/qwen3.8-27b)
render
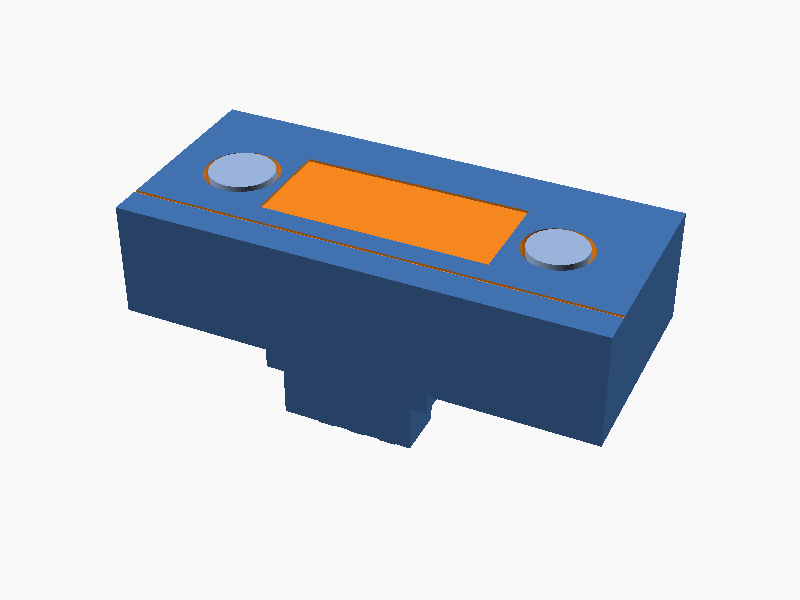
// Sharp GP2Y0D413K0F - infrared distance sensor
// Coordinate system: unit mm, body center at origin,
// mounting face (PWB / connector side) -> -Z, lens face -> +Z
//
// Dimension mapping (from "Outline Dimensions", unit mm):
//   W  = 29.45   overall width  (X)
//   H  = 13.05   case height    (Y)
//   D  =  7.1   case depth      (Z)
//   lens centers: 4.5 and 19.7 from left edge (lens-center dims)
//   PWB / connector tab: 10.1 x 3.75, protruding at -Z / bottom

W  = 29.45;                 // overall width  (X)
H  = 13.05;                 // case height    (Y)
D  =  7.1;                  // case depth     (Z)

em  = -W/2 + 4.5;           // light-emitter center X
det =  em  + 19.7;          // light-detector center X
xc  = (em + det) / 2;      // approximate center of optics / PWB

tabW = 10.1;               // PWB / connector width
tabH =  3.75;              // PWB / connector height
ytab = -H/2 + tabH/2;     // tab sits at the bottom edge
pwbD =  1.2;              // PWB protrusion depth (-Z)

r_em  = 2.3;              // emitter lens radius (approx)
r_det = 2.1;              // detector lens radius (approx)

// ---------------- main solid (case + PWB + connector) ----------------
difference() {
    union() {
        // main lens-case body
        cube([W, H, D], center = true);

        // PWB / connector tab at the back (-Z), bottom edge
        translate([xc, ytab, -D/2 - pwbD/2])
            cube([tabW, tabH, pwbD], center = true);

        // connector housing
        translate([xc, ytab - 0.3, -D/2 - pwbD - 1.5])
            cube([8, 3, 3.0], center = true);

        // 3 connector pins (Vo, GND, Vcc)
        for (i = [-1, 0, 1])
            translate([xc + i*2.0, ytab - 0.3, -D/2 - pwbD - 3.0 - 0.6])
                cube([1.0, 0.6, 1.2], center = true);
    }

    // ----- cuts -----
    // lens bores (through the front face)
    translate([em,  0, 0]) cylinder(h = D + 2, d = 2*r_em,  $fn = 64);
    translate([det, 0, 0]) cylinder(h = D + 2, d = 2*r_det, $fn = 64);

    // front window recess (between the two lenses)
    translate([xc, 0, D/2]) cube([14, 6, 0.3], center = true);

    // horizontal seam line on the front face
    translate([0, -H/2 + 2.0, D/2]) cube([W, 0.2, 0.25], center = true);
}

// ---------------- lenses (acrylic) seated in the bores ----------------
color([0.6, 0.7, 0.85, 1]) {
    translate([em,  0, 0]) translate([0, 0, D/2 - 0.35])
        cylinder(h = 0.5, d = 2*(r_em  - 0.3), $fn = 64);
    translate([det, 0, 0]) translate([0, 0, D/2 - 0.35])
        cylinder(h = 0.5, d = 2*(r_det - 0.3), $fn = 64);
} パラメータ (8) —
スライダを動かすと openscad-wasm で再レンダリング
prompt
添付画像は Sharp 製距離センサ GP2Y0D413K0F のデータシートのページです。
OpenSCAD でモデリングしてください。

座標系: 単位 mm、本体の中心を原点とし、取付面(PWB / コネクタ側)を -Z に向ける。

完成したコード全体を ```openscad ... ``` のフェンスで囲んで出力してください。