tier-4-gp2y0d413k / gpt-6.1-sol
1 run / 累計 84.0s / 累計 $0.0445
openai gpt 6.1 sol pdf-page
bare (provider default effort)
run detail → render
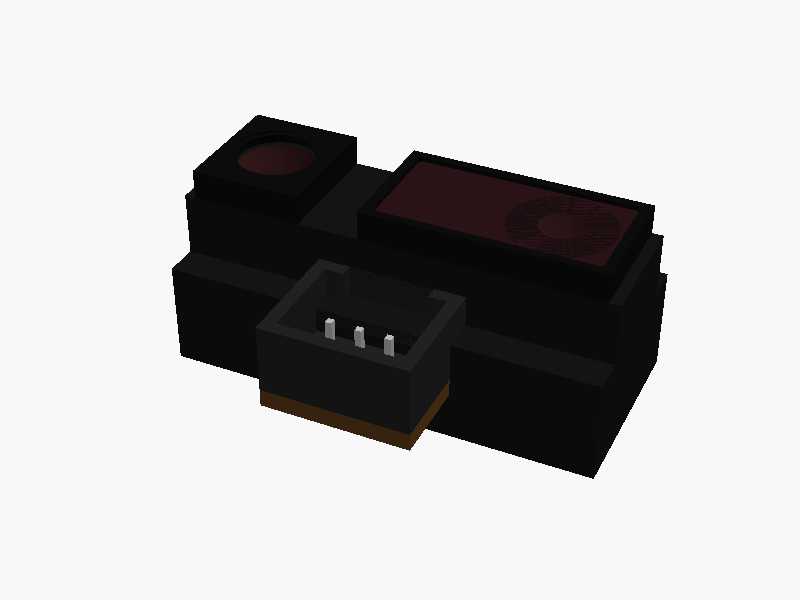
/*
  SHARP GP2Y0D413K0F
  単位:mm

  座標系:
    原点 = 主筐体の外接直方体の中心(コネクタを含まない)
    +X   = 正面図の右
    +Y   = 正面図の上
    +Z   = 光学面側
    -Z   = PWB/コネクタ側

  図面から読み取れる主要寸法を使用。
  寸法指定のないレンズ曲率、枠厚、コネクタ内部、
  端子形状などは外観再現用の近似。
*/

$fn = 80;

// ---------- 主寸法 ----------
body_w = 29.45;
body_h = 13.05;

front_to_step = 6.3;
rear_depth    = 7.1;
body_d        = front_to_step + rear_depth;

front_z =  body_d / 2;
rear_z  = -body_d / 2;

// 光学枠先端から、前部筐体までの段差
optical_projection = 2.0;
shoulder_z = front_z - optical_projection;
step_z     = front_z - front_to_step;

optical_h = 8.4;
window_h  = 7.2;

// 正面図のレンズ中心寸法
emitter_x  = -body_w / 2 + 4.5;
detector_x = emitter_x + 19.7;

// 光学枠の横方向寸法
edge_margin = 0.75;
emitter_frame_w  = 7.5;
frame_gap        = 4.15;
detector_frame_w = 16.3;

emitter_frame_x =
    -body_w / 2 + edge_margin + emitter_frame_w / 2;

detector_frame_x =
    -body_w / 2 + edge_margin
    + emitter_frame_w + frame_gap + detector_frame_w / 2;

// コネクタ/PWB
overall_h   = 18.9;
connector_w = 10.1;

body_bottom_y = -body_h / 2;
connector_bottom_y = body_h / 2 - overall_h;
connector_top_y    = -optical_h / 2;

pwb_t = 1.2;

// 背面からPWB背面までの参考寸法
pwb_back_z  = rear_z + 3.3;
pwb_front_z = pwb_back_z + pwb_t;

// 側面図から近似したコネクタ前端位置
connector_front_z = front_z - 4.2;
connector_back_z  = pwb_front_z;

// ---------- 表示 ----------
show_pwb       = true;
show_terminals = true;

case_color      = [0.075, 0.078, 0.082];
frame_color     = [0.045, 0.048, 0.052];
connector_color = [0.13, 0.13, 0.14];
lens_color      = [0.16, 0.075, 0.085];
pwb_color       = [0.37, 0.24, 0.10];
metal_color     = [0.72, 0.73, 0.75];

eps = 0.02;

// 指定範囲の直方体
module block(x0, x1, y0, y1, z0, z1) {
    translate([(x0+x1)/2, (y0+y1)/2, (z0+z1)/2])
        cube([x1-x0, y1-y0, z1-z0], center=true);
}

// 丸角の平面形状
module rounded_rectangle(w, h, r) {
    hull()
        for (x = [-w/2+r, w/2-r])
            for (y = [-h/2+r, h/2-r])
                translate([x,y])
                    circle(r=r);
}

// +Z方向に膨らむ球面キャップ
module lens_cap(x, y, diameter, sag, apex_z) {
    a = diameter / 2;
    radius = (a*a + sag*sag) / (2*sag);

    intersection() {
        translate([x, y, apex_z-radius])
            sphere(r=radius);

        block(
            x-a-eps, x+a+eps,
            y-a-eps, y+a+eps,
            apex_z-sag, apex_z+eps
        );
    }
}

// ---------- 主筐体 ----------
module housing() {
    color(case_color)
        union() {
            // 後部:全高13.05、奥行7.1
            block(
                -body_w/2, body_w/2,
                -body_h/2, body_h/2,
                rear_z, step_z
            );

            // 前部:光学中心を挟む高さ8.4の突出部
            block(
                -body_w/2, body_w/2,
                -optical_h/2, optical_h/2,
                step_z-eps, shoulder_z
            );
        }
}

// ---------- 発光側 ----------
module emitter() {
    // 前面の角形レンズ枠
    color(frame_color)
        difference() {
            block(
                emitter_frame_x-emitter_frame_w/2,
                emitter_frame_x+emitter_frame_w/2,
                -optical_h/2, optical_h/2,
                shoulder_z-eps, front_z
            );

            translate([emitter_x, 0, shoulder_z-eps*2])
                cylinder(
                    d=6.25,
                    h=optical_projection+eps*4
                );
        }

    // 円形のレンズ座
    color(case_color)
        translate([emitter_x, 0, shoulder_z-eps])
            cylinder(d=6.2, h=1.15);

    // レンズ周囲の環状リム
    color(frame_color)
        translate([emitter_x, 0, front_z-0.55])
            difference() {
                cylinder(d=6.15, h=0.50);
                translate([0,0,-eps])
                    cylinder(d=5.25, h=0.50+2*eps);
            }

    // 可視光カット樹脂のレンズ
    color(lens_color)
        lens_cap(
            emitter_x, 0,
            5.25, 0.75,
            front_z-0.06
        );
}

// ---------- 受光側 ----------
module detector() {
    inner_w = detector_frame_w - 1.4;

    color(frame_color)
        difference() {
            block(
                detector_frame_x-detector_frame_w/2,
                detector_frame_x+detector_frame_w/2,
                -optical_h/2, optical_h/2,
                shoulder_z-eps, front_z
            );

            translate([
                detector_frame_x,
                0,
                shoulder_z-eps*2
            ])
                linear_extrude(
                    height=optical_projection+eps*4
                )
                    rounded_rectangle(inner_w, window_h, 0.25);
        }

    // 横長の受光窓
    color(lens_color)
        translate([detector_frame_x, 0, shoulder_z-eps])
            linear_extrude(height=1.72)
                rounded_rectangle(inner_w, window_h, 0.30);

    // 図示された受光レンズ周辺の円形座
    color([0.105, 0.06, 0.065])
        translate([detector_x, 0, front_z-0.45])
            cylinder(d=7.0, h=0.15);

    color(lens_color)
        lens_cap(
            detector_x, 0,
            4.65, 0.60,
            front_z-0.06
        );
}

// ---------- PWB ----------
module pwb() {
    color(pwb_color)
        block(
            -connector_w/2, connector_w/2,
            connector_bottom_y, body_bottom_y+eps,
            pwb_back_z, pwb_front_z
        );
}

// ---------- コネクタ ----------
module connector() {
    wall = 0.9;

    color(connector_color)
        difference() {
            union() {
                block(
                    -connector_w/2, connector_w/2,
                    connector_bottom_y, connector_top_y,
                    connector_back_z, connector_front_z
                );

                // 側面図の上端に見える小さな係合部
                block(
                    -connector_w/2, connector_w/2,
                    body_bottom_y,
                    body_bottom_y+0.75,
                    step_z-0.9, step_z+0.15
                );
            }

            // 正面側の差込口
            block(
                -connector_w/2+wall,
                 connector_w/2-wall,
                connector_bottom_y+wall,
                connector_top_y-wall,
                connector_back_z+0.9,
                connector_front_z+eps
            );

            // 上側のキー/開口
            block(
                -2.9, 2.9,
                connector_top_y-1.6,
                connector_top_y+eps,
                connector_back_z+0.9,
                connector_front_z+eps
            );
        }

    // コネクタ内の端子保持部
    color(connector_color)
        block(
            -3.9, 3.9,
            connector_bottom_y+3.15,
            connector_bottom_y+4.15,
            connector_back_z-eps,
            connector_back_z+1.25
        );
}

// ---------- 3端子 ----------
module terminals() {
    // 端子ピッチ・断面は図面外観からの近似
    pitch = 2.0;
    pin_w = 0.45;
    pin_y = connector_bottom_y + 3.65;

    color(metal_color)
        for (i = [-1:1]) {
            x = i*pitch;

            // コネクタ内部からPWB側へ
            block(
                x-pin_w/2, x+pin_w/2,
                pin_y-pin_w/2, pin_y+pin_w/2,
                pwb_back_z-0.15,
                connector_front_z-0.95
            );

            // PWB裏面側の短い曲げ足
            block(
                x-pin_w/2, x+pin_w/2,
                pin_y-2.0, pin_y+pin_w/2,
                pwb_back_z-0.35,
                pwb_back_z+0.05
            );
        }
}

// ---------- 組立 ----------
module GP2Y0D413K0F() {
    housing();
    emitter();
    detector();
    connector();

    if (show_pwb)
        pwb();

    if (show_terminals)
        terminals();
}

GP2Y0D413K0F(); パラメータ (17) —
スライダを動かすと openscad-wasm で再レンダリング
prompt
添付画像は Sharp 製距離センサ GP2Y0D413K0F のデータシートのページです。
OpenSCAD でモデリングしてください。

座標系: 単位 mm、本体の中心を原点とし、取付面(PWB / コネクタ側)を -Z に向ける。

完成したコード全体を ```openscad ... ``` のフェンスで囲んで出力してください。