tier-4-gp2y0d413k / gpt-6-luna
1 run / 累計 42.1s / 累計 $0.0024
openai gpt 6 luna pdf-page
bare (provider default effort)
run detail → render
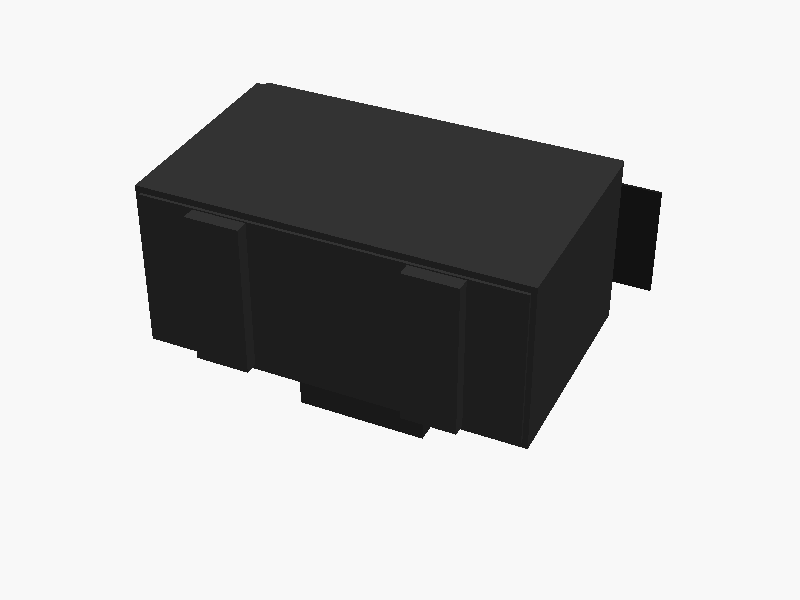
// Sharp GP2Y0D413K0F distance sensor
// Units: mm
// Origin: center of the main housing
// Optical face: +Y; PWB / connector side: -Z

$fn = 64;

// Main housing dimensions
body_width = 29.45;
body_height = 13.05;
body_depth = 17.0;

// Lens centers measured from the left edge of the housing
emitter_x  = -body_width/2 + 4.5;
detector_x = emitter_x + 19.7;

// Main housing and front optical face
color([0.20, 0.20, 0.20])
union() {
    // Main case
    cube([body_width, body_depth, body_height], center=true);

    // Front lens-case lip
    translate([0, body_depth/2 + 0.55, 0])
        cube([body_width - 0.6, 1.1, body_height - 0.8], center=true);

    // Rear case seam
    translate([0, -body_depth/2 - 0.12, 0])
        cube([body_width - 0.8, 0.24, body_height - 1.0], center=true);

    // Small rear mounting ribs
    for (x = [-8.0, 8.0]) {
        translate([x, -body_depth/2 - 0.65, 0])
            cube([4.15, 1.3, body_height - 1.2], center=true);
    }
}

// Raised rectangular optical surrounds on the front face
color([0.12, 0.12, 0.12]) {
    translate([emitter_x, body_depth/2 + 1.13, 0])
        cube([8.0, 0.22, 8.4], center=true);

    translate([detector_x, body_depth/2 + 1.13, 0])
        cube([15.8, 0.22, 8.4], center=true);
}

// Lens recess backgrounds
color([0.035, 0.035, 0.035]) {
    translate([emitter_x, body_depth/2 + 1.255, 0])
        rotate([90, 0, 0])
            cylinder(d=6.3, h=0.08, center=true);

    translate([detector_x, body_depth/2 + 1.255, 0])
        rotate([90, 0, 0])
            cylinder(d=6.3, h=0.08, center=true);
}

// Optical lenses
color([0.30, 0.42, 0.48, 0.8]) {
    translate([emitter_x, body_depth/2 + 1.31, 0])
        rotate([90, 0, 0])
            cylinder(d=5.2, h=0.14, center=true);

    translate([detector_x, body_depth/2 + 1.31, 0])
        rotate([90, 0, 0])
            cylinder(d=5.2, h=0.14, center=true);
}

// Concentric lens rims
module lens_rim(xpos, diameter) {
    color([0.48, 0.48, 0.46])
    translate([xpos, body_depth/2 + 1.39, 0])
        rotate([90, 0, 0])
            difference() {
                cylinder(d=diameter, h=0.16, center=true);
                cylinder(d=diameter - 0.55, h=0.20, center=true);
            }
}

lens_rim(emitter_x, 6.1);
lens_rim(detector_x, 6.1);

// PWB on the mounting / connector side
color([0.42, 0.28, 0.14])
translate([0, -0.25, -body_height/2 - 0.18])
    cube([11.5, 9.0, 0.36], center=true);

// Connector housing, extending from the -Z mounting side
color([0.17, 0.17, 0.17])
translate([0, -0.25, -body_height/2 - 3.05])
    cube([10.1, 7.5, 5.9], center=true);

// Connector front inset
color([0.09, 0.09, 0.09])
translate([0, 3.56, -body_height/2 - 3.1])
    cube([8.7, 0.18, 4.2], center=true);

// Three connector terminals
color([0.72, 0.70, 0.62])
for (x = [-2.54, 0, 2.54]) {
    translate([x, -0.15, -body_height/2 - 6.05])
        cube([0.55, 0.55, 3.0], center=true);
}

// Small molded details on the connector face
color([0.70, 0.70, 0.66])
for (x = [-2.54, 0, 2.54]) {
    translate([x, 3.67, -body_height/2 - 2.55])
        cube([0.48, 0.08, 0.48], center=true);
}

// Subtle lower ledge along the housing
color([0.16, 0.16, 0.16])
translate([0, 0, -body_height/2 + 0.25])
cube([body_width - 1.0, body_depth - 0.8, 0.5], center=true); パラメータ (3) —
スライダを動かすと openscad-wasm で再レンダリング
prompt
添付画像は Sharp 製距離センサ GP2Y0D413K0F のデータシートのページです。
OpenSCAD でモデリングしてください。

座標系: 単位 mm、本体の中心を原点とし、取付面(PWB / コネクタ側)を -Z に向ける。

完成したコード全体を ```openscad ... ``` のフェンスで囲んで出力してください。